A Grey Wolf Optimizer Algorithm for Multi-Objective Cumulative Capacitated Vehicle Routing Problem Considering Operation Time
Related Experiment Video
Updated: Jun 23, 2025
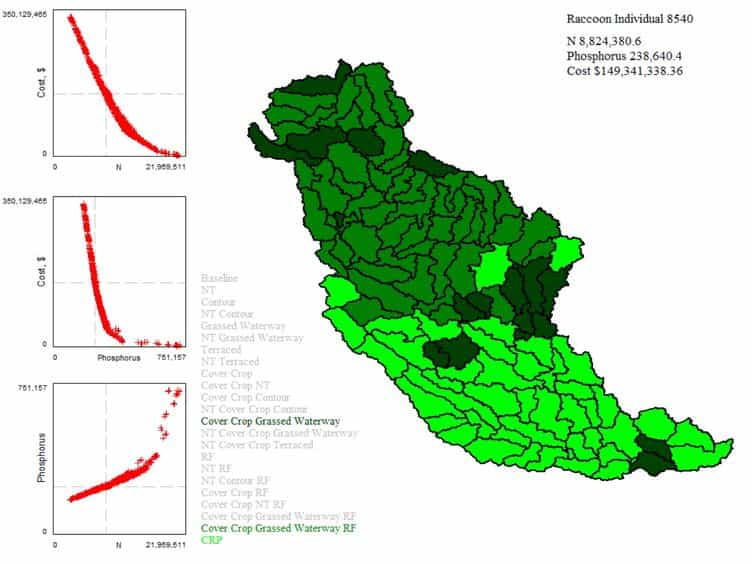
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Gewen Huang1,2, Yuanhang Qi3, Yanguang Cai2
1Information and Network Center, Jiaying University, Meizhou 514015, China.

Abstract:
In humanitarian aid scenarios, the model of cumulative capacitated vehicle routing problem can be used in vehicle scheduling, aiming at delivering materials to recipients as quickly as possible, thus minimizing their wait time. Traditional approaches focus on this metric, but practical implementations must also consider factors such as driver labor intensity and the capacity for on-site decision-making. To evaluate driver workload, the operation times of relief vehicles are typically used, and multi-objective modeling is employed to facilitate on-site decision-making. This paper introduces a multi-objective cumulative capacitated vehicle routing problem considering operation time (MO-CCVRP-OT). Our model is bi-objective, aiming to minimize both the cumulative wait time of disaster-affected areas and the extra expenditures incurred by the excess operation time of rescue vehicles. Based on the traditional grey wolf optimizer algorithm, this paper proposes a dynamic grey wolf optimizer algorithm with floating 2-opt (DGWO-F2OPT), which combines real number encoding with an equal-division random key and ROV rules for decoding; in addition, a dynamic non-dominated solution set update strategy is introduced. To solve MO-CCVRP-OT efficiently and increase the algorithm's convergence speed, a multi-objective improved floating 2-opt (F2OPT) local search strategy is proposed. The utopia optimum solution of DGWO-F2OPT has an average value of two fitness values that is 6.22% lower than that of DGWO-2OPT. DGWO-F2OPT's average fitness value in the algorithm comparison trials is 16.49% less than that of NS-2OPT. In the model comparison studies, MO-CCVRP-OT is 18.72% closer to the utopian point in Euclidean distance than CVRP-OT.
Related Concept Videos
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:21
Distributed Loads: Problem Solving
 01:23
Maximum Power Flow and Line Loadability
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...
 01:20
Maxwell-Boltzmann Distribution: Problem Solving
This distribution function f(v) is defined by saying that the expected number N (v1,v2) of particles with speeds between v1 and v2 is given by
 01:05
Noncompartmental Analysis: Mean Residence Time
After the administration of a drug through intravenous bolus injection, the drug molecules are distributed throughout the body and remain there for varying periods. The MRT represents the average time these drug molecules stay in the...