Related Experiment Video
Updated: Sep 20, 2026
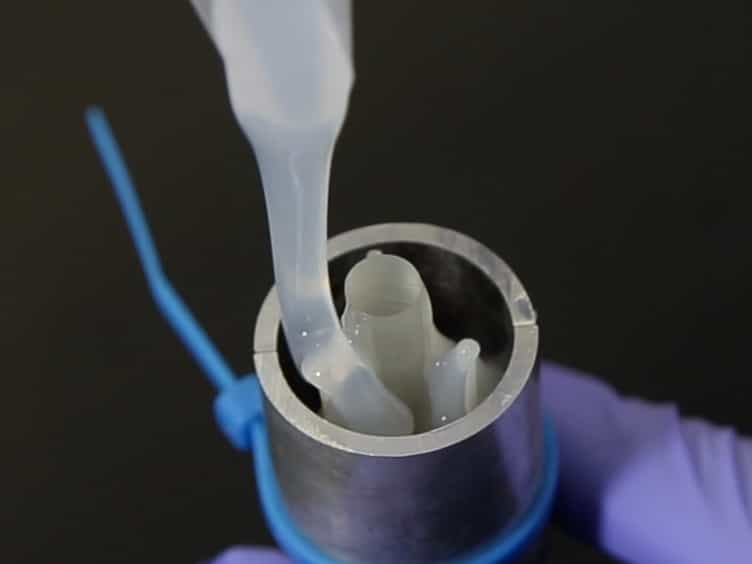
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Octopus-Inspired Soft Robot for Slow Drug Release
Dingwen Tong1,2, Yiqun Zhao1,2, Zhengnan Wu1,2
1School of Mechanical and Electrical Engineering, Soochow University, Suzhou 215131, China.

Abstract:
Octopus tentacles are equipped with numerous suckers, wherein the muscles contract and expel air, creating a pressure difference. Subsequently, when the muscular tension is released, objects can be securely adhered to. This mechanism has been widely employed in the development of adhesive systems. However, most existing octopus-inspired structures are passive and static, lacking dynamic and controllable adhesive switching capabilities and excellent locomotion performance. Here, we present an octopus-inspired soft robot (OISR). Attracted by the magnetic gradient field, the suction cup structure inside the OISR can generate a strong adsorption force, producing dynamically controllable adsorption and separation in the gastrointestinal (GI) tract. The experimental results show that the OISR has a variety of controllable locomotion behaviors, including quick scrolling and rolling motions, generating fast locomotion responses, rolling over gastric folds, and tumbling and swimming inside liquids. By carrying drugs that are absorbable by GI epithelial cells to target areas, the OISR enables continuous drug delivery at lesions or inflamed regions of the GI tract. This research may be a potential approach for achieving localized slow drug release within the GI tract.

Related Concept Videos
 01:19
Modified-Release Drug Delivery Systems: Rate-Programmed II
 01:23
Modified-Release Drug Delivery Systems: Classification
 01:22
Modified-Release Drug Delivery Systems: Rate-Programmed I
 01:30
Modified-Release Drug Delivery Systems: Stimuli-Activated
 01:11
Oral Drug Delivery Systems: Delayed-Release Systems
 01:23
Ophthalmic Drug Delivery Systems