Related Experiment Video
Updated: Jun 22, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Iterative Chebyshev approximation method for optimal control problems
Di Wu1, Changjun Yu1, Hailing Wang1
1Department of Mathematics, Shanghai University, Shanghai 200444, China.

Abstract:
We present a novel numerical approach for solving nonlinear constrained optimal control problems (NCOCPs). Instead of directly solving the NCOCPs, we start by linearizing the constraints and dynamic system, which results in a sequence of sub-problems. For each sub-problem, we use finite number of Chebyshev polynomials to estimate the control and state vectors. To eliminate the errors at non-collocation points caused by conventional collocation methods, we additionally estimate the coefficient functions involved in the linear constraints and dynamic system by Chebyshev polynomials. By leveraging the characteristics of Chebyshev polynomials, the approximate sub-problem is changed into an equivalent nonlinear optimization problem with linear equality constraints. Consequently, any feasible point of the approximate sub-problem will satisfy the constraints and dynamic system throughout the entire time scale. To validate the efficacy of the new method, we solve three examples and assess the accuracy of the method through the computation of its approximation error. Numerical results obtained show that our approach achieves lower approximation error when compared to the Chebyshev pseudo-spectral method. The proposed method is particularly suitable for scenarios that require high-precision approximation, such as aerospace and precision instrument production.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Related Concept Videos
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:15
Chebyshev's Theorem to Interpret Standard Deviation
 01:16
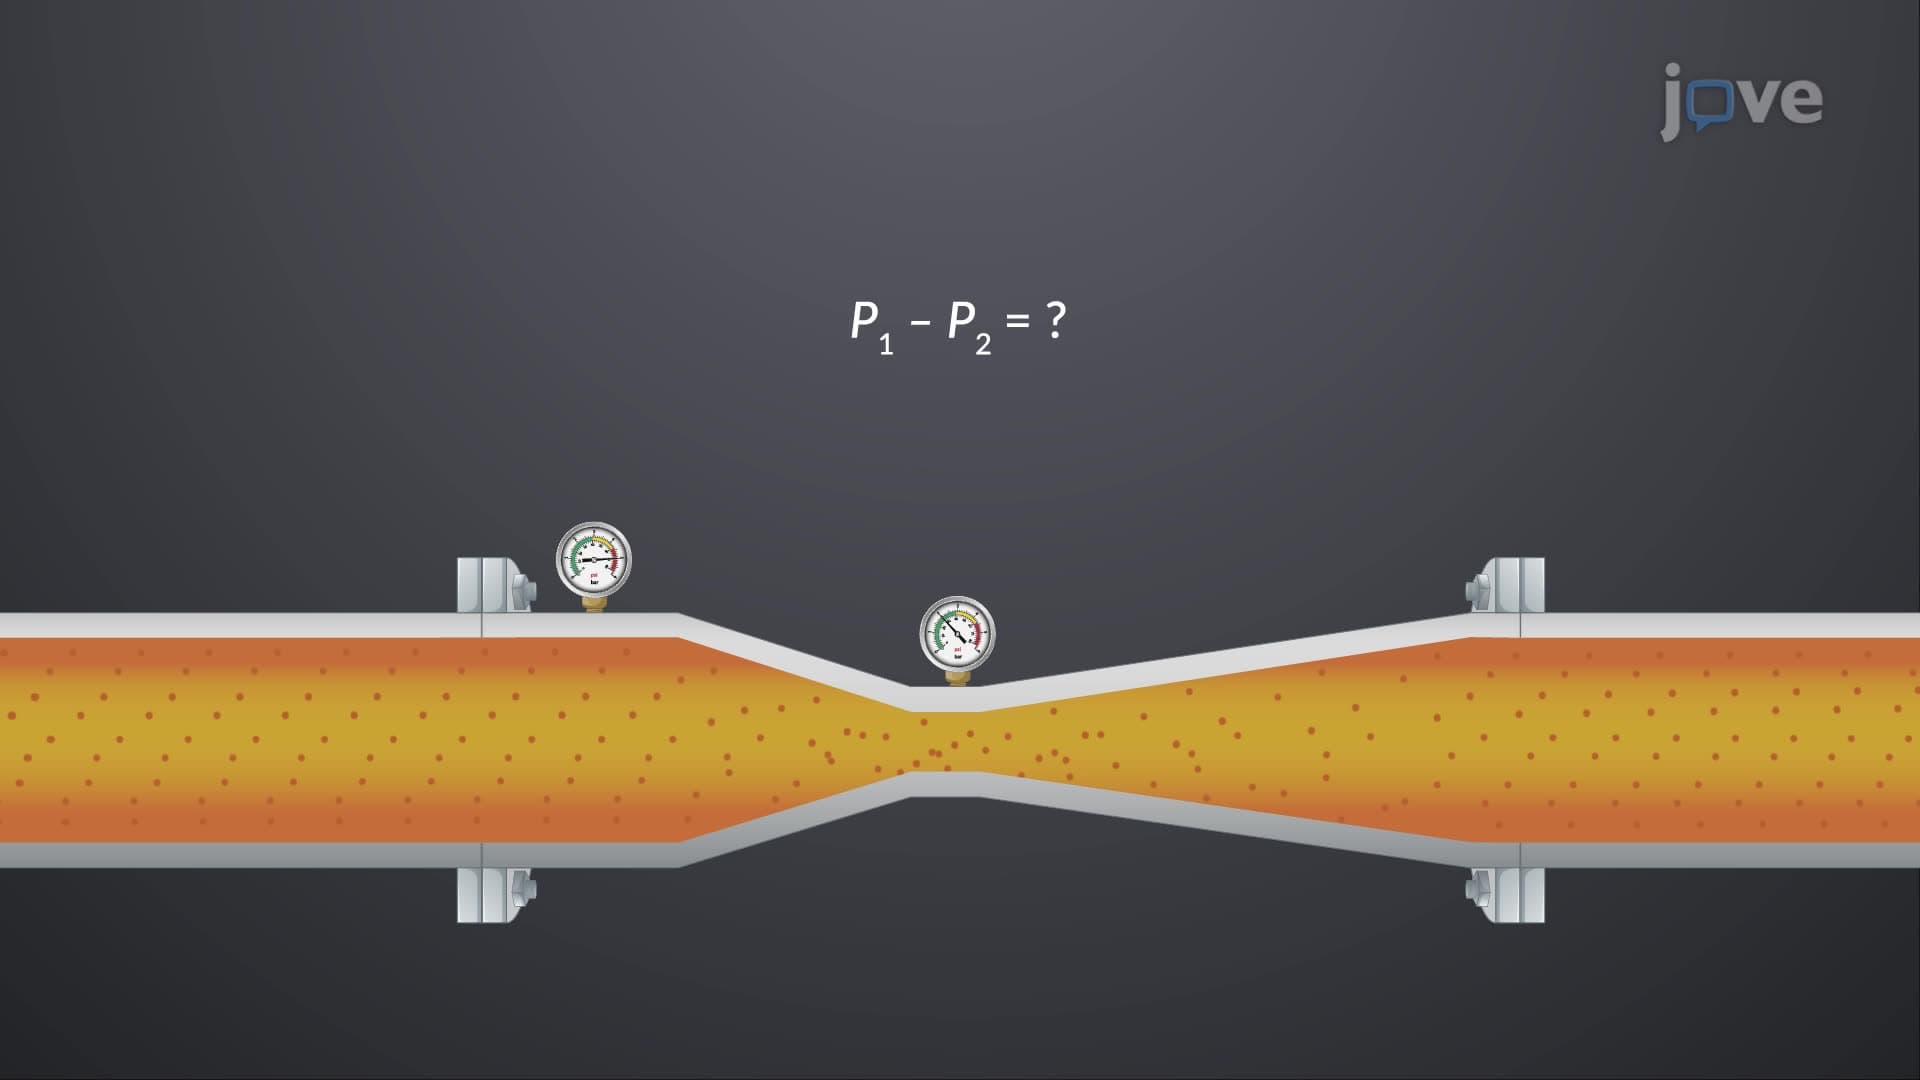
Bernoulli's Equation: Problem Solving
The first step is to compute the cross-sectional areas of the pipe and the Venturi throat to analyze the pressure difference indicated by the pressure gauge. Next, the continuity...
 01:10
Control Systems
At the heart...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....