Sliding mode observer-based model predictive tracking control for Mecanum-wheeled mobile robot
Related Experiment Video
Updated: Jun 22, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Dongliang Wang1, Yong Gao2, Wu Wei2
1School of Department of Electronic and Information Engineering, Shantou University, 515063, Guangdong, China; Key Lab of Digital Signal and Image Processing of Guangdong Province, Shantou University, 515063, Guangdong, China.

Abstract:
This paper proposes a novel adaptive variable power sliding mode observer-based model predictive control (AVPSMO-MPC) method for the trajectory tracking of a Mecanum-wheeled mobile robot (MWMR) with external disturbances and model uncertainties. First, in the absence of disturbances and uncertainties, a model predictive controller that considers various physical constraints is designed based on the nominal dynamics model of the MWMR, which can transform the tracking problem into a constrained quadratic programming (QP) problem to solve the optimal control inputs online. Subsequently, to improve the anti-jamming ability of the MWMR, an AVPSMO is designed as a feedforward compensation controller to suppress the effects of external disturbances and model uncertainties during the actual motion of the MWMR, and the stability of the AVPSMO is proved via Lyapunov theory. The proposed AVPSMO-MPC method can achieve precise tracking control while ensuring that the constraints of MWMR are not violated in the presence of disturbances and uncertainties. Finally, comparative simulation cases are presented to demonstrate the effectiveness and robustness of the proposed method.


Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
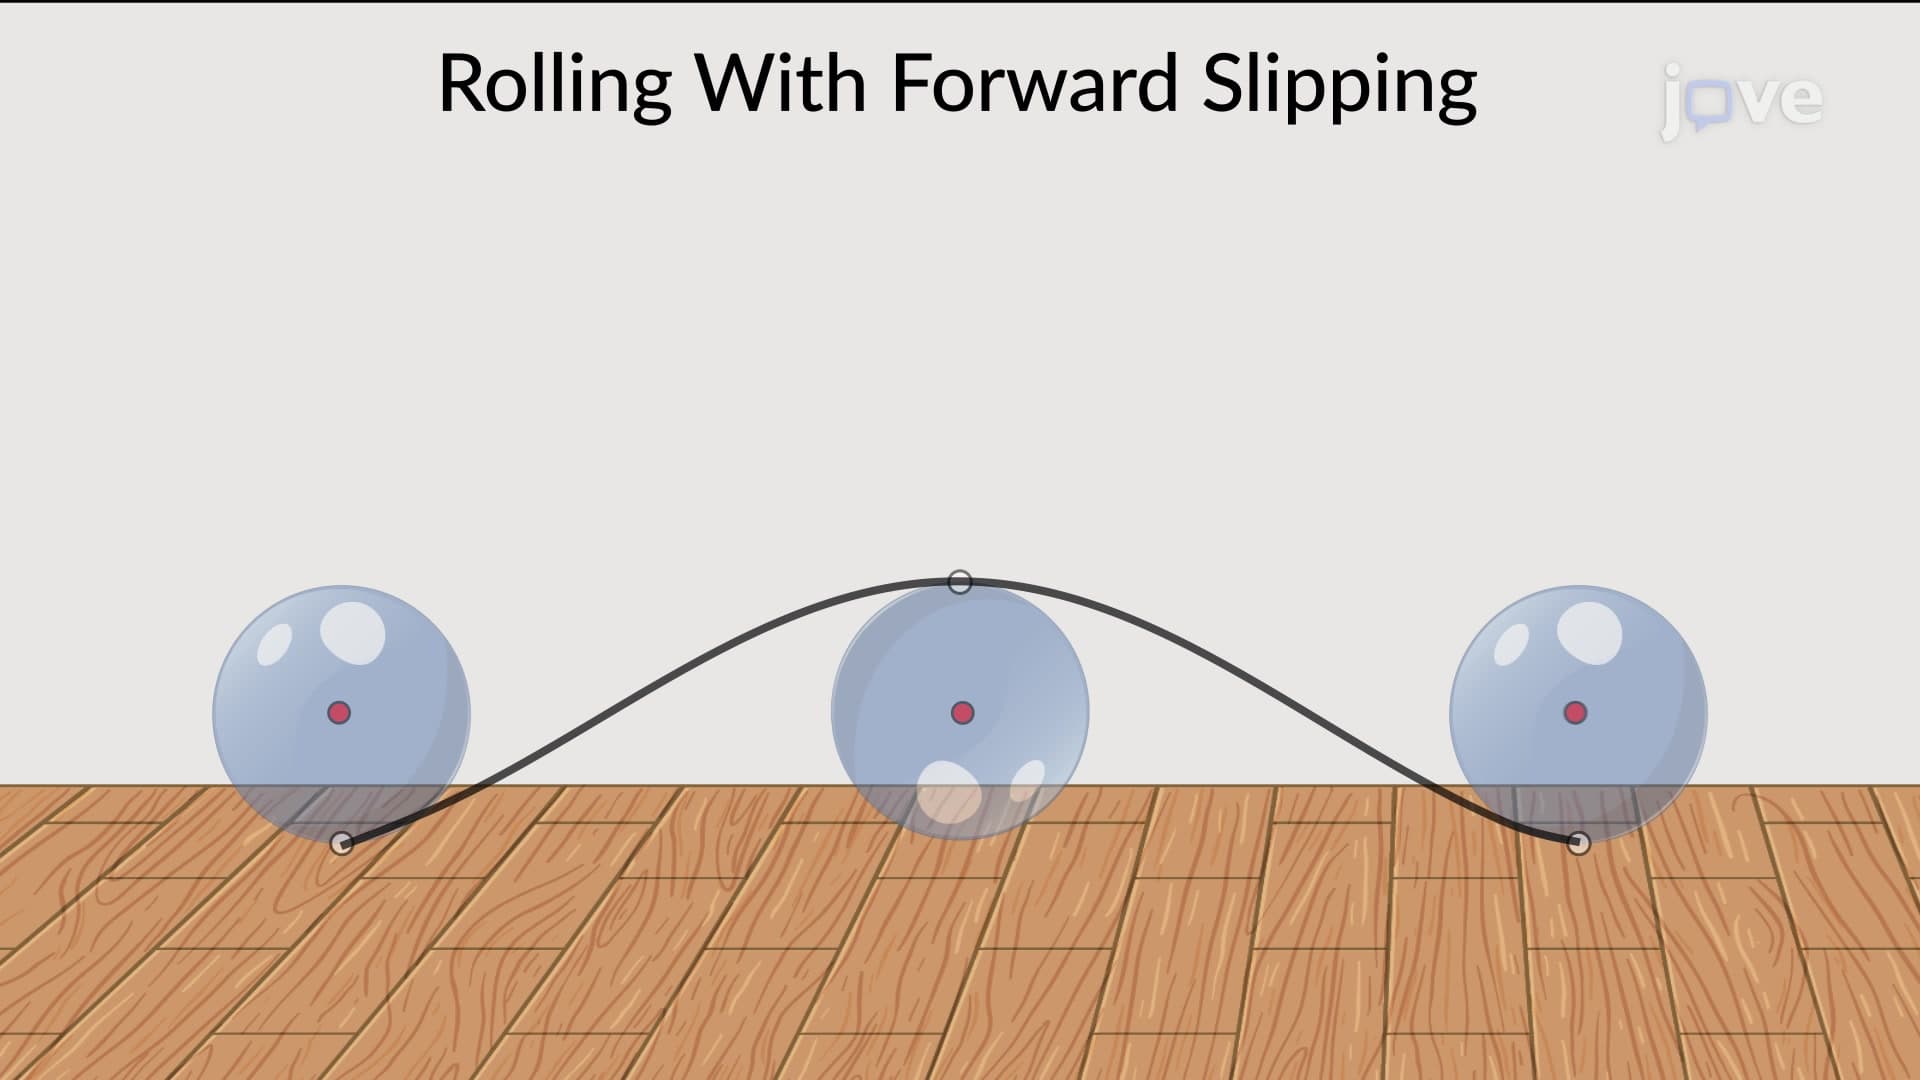 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...