Related Experiment Video
Updated: Jun 27, 2026


Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
A model of task-level human stepping regulation yields semistable walking
Navendu S Patil1,2, Jonathan B Dingwell1, Joseph P Cusumano2
1Department of Kinesiology, Pennsylvania State University, University Park, PA 16802, USA.

Abstract:
A simple lateral dynamic walker, with swing leg dynamics and three adjustable input parameters, is used to study how motor regulation affects frontal plane stepping. Motivated by experimental observations and phenomenological models, we imposed task-level multiobjective regulation targeting the walker's optimal lateral foot placement at each step. The regulator prioritizes achieving step width and lateral body position goals to varying degrees by choosing a mixture parameter. Our model thus integrates a lateral mechanical template, which captures fundamental mechanics of frontal-plane walking, with a lateral motor regulation template, an empirically verified model of how humans manipulate lateral foot placements in a goal-directed manner. The model captures experimentally observed stepping fluctuation statistics and demonstrates how linear empirical models of stepping dynamics can emerge from first-principles nonlinear mechanics. We find that task-level regulation gives rise to a goal equivalent manifold in the system's extended state space of mechanical states and inputs, a subset of which contains a continuum of period-1 gaits forming a semistable set: perturbations off of any of its gaits result in transients that return to the set, though typically to different gaits.


Related Concept Videos
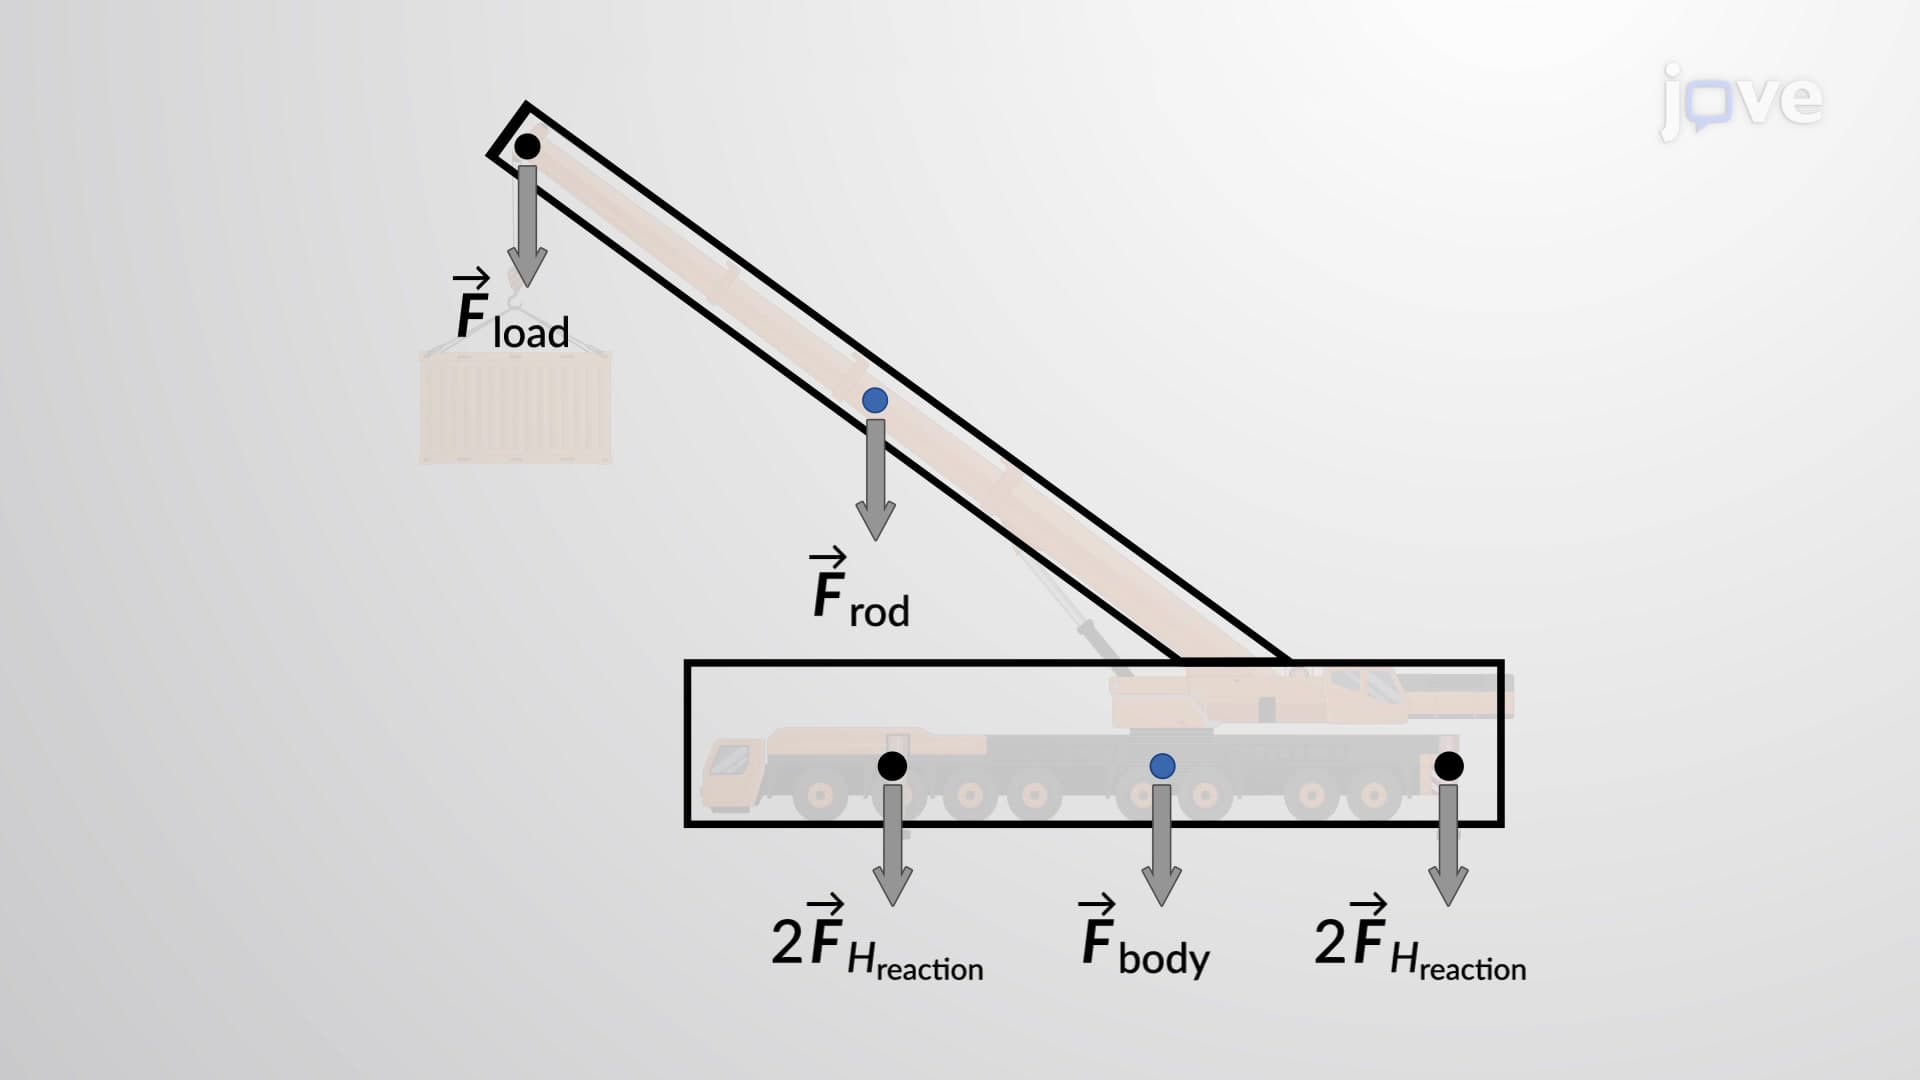 00:49
Rigid Body Equilibrium Problems - I
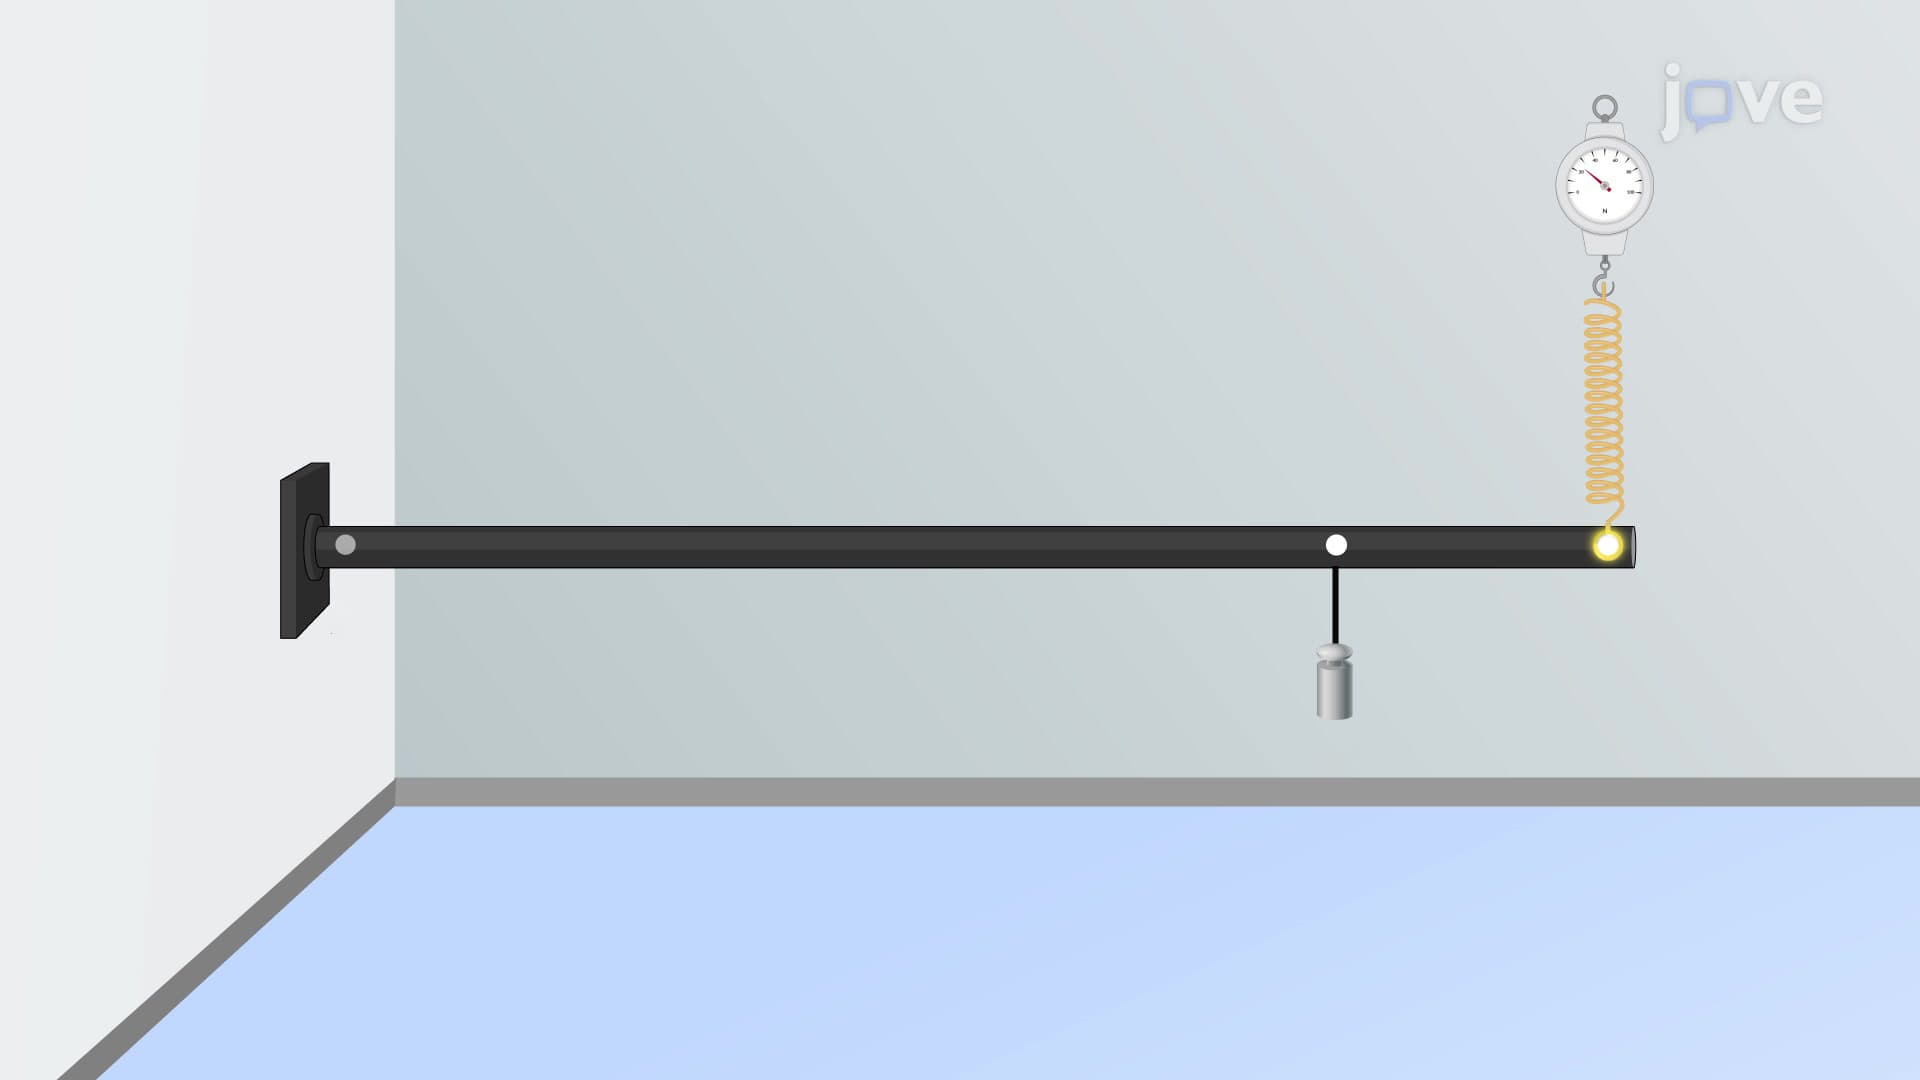 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?