Normal Reorientation for Scene Consistency
Related Experiment Video
Updated: Jun 21, 2025
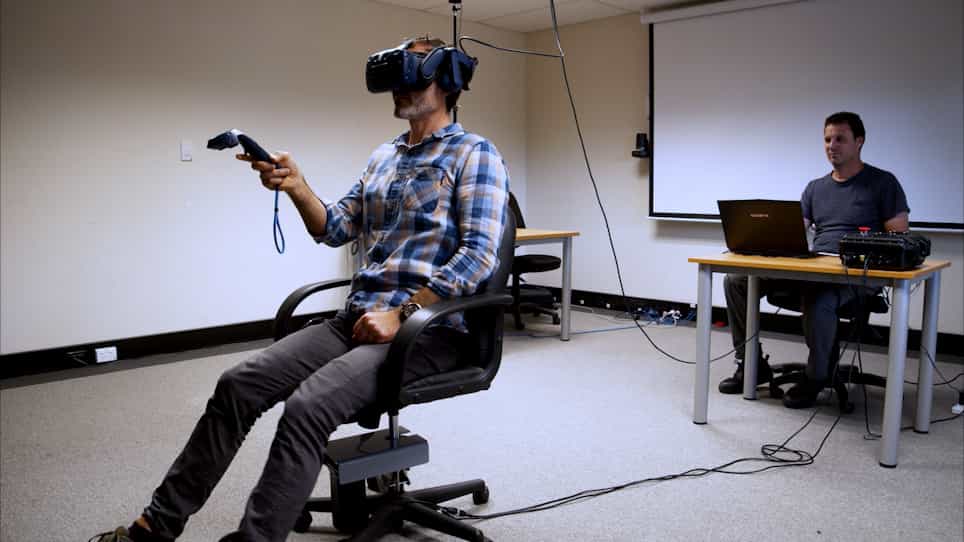
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022

Abstract:
With the remarkable progress of 3D scanning technique, the captured indoor scenes appear increasingly in last decade. Generating orientation-consistent normals for indoor point clouds is a fundamental and important task. The existing orientation rectification methods pay more attention to object-level targets with connected surface. However, it is challenging to compute consistent surface orientation for real scanned indoor point clouds. In this paper, we analyze the causes of this difficulty and propose a new normal reorienting framework for indoor scene consistency, namely NRSC. It first estimates normals for an indoor point cloud and extracts all the connected regions. We then design and construct an abstract orientation bridging tree (OBT) to organize the extracted regions in a hierarchical way. For all node regions, NRSC iteratively implements a set of orientation propagations to generate locally orientation-consistent regions. Moreover, we define an auxiliary viewpoint set for each pairwise parent-child node regions and introduce a voting mechanism to rectify the region orientation of child node according to its parent. After processing all the child node regions along OBT, we finally eliminate the orientation inconsistencies between related regions. Multi-groups of experimental results on both fused indoor scenes and single-view-scenes show that our method generates globally consistent orientation for indoor point clouds.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:03
Inertial Frames of Reference
 01:27
Non-inertial Frames of Reference
 01:11
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...