LPV interpolation modeling and modal-based pole placement control for ball screw drive with dynamic variations
Related Experiment Video
Updated: Jun 20, 2025

A Modeling and Simulation Method for Preliminary Design of an Electro-Variable Displacement Pump
Published on: June 1, 2022
Peng Deng1, Tao Huang1, Weigui Zhang2
1State Key Laboratory of Mechanical Transmissions for Advanced Equipment, Chongqing University, Chongqing 400044, China; College of Mechanical and Vehicle Engineering, Chongqing University, Chongqing 400044, China.

Abstract:
This paper presents a linear parameter varying (LPV) interpolation modeling method and modal-based pole placement (PP) control strategy for the ball screw drive (BSD) with varying dynamics. The BSD is modeled as a global LPV model with position-load dependence by selecting position and load as scheduling variables. The global LPV model is obtained from local subspace closed-loop identification and LPV interpolation modeling. A modal-based global LPV model is obtained through the similarity transformation. Based on this model, a modal-based LPV PP control strategy is proposed to achieve various modal control. Specifically, a state feedback control structure with an LPV state observer is designed to realize online state estimation and real-time state feedback control of modal state variables which cannot be measured directly. The steady-state error is minimized by introducing an error state space (SS) model with the integral effects. Moreover, the stability of the closed-loop system is analyzed according to the controllable decomposition and principle of separation. It is experimentally demonstrated that the proposed modal-based LPV PP control strategy can effectively achieve precise tracking and outstanding robustness meantime.


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:19
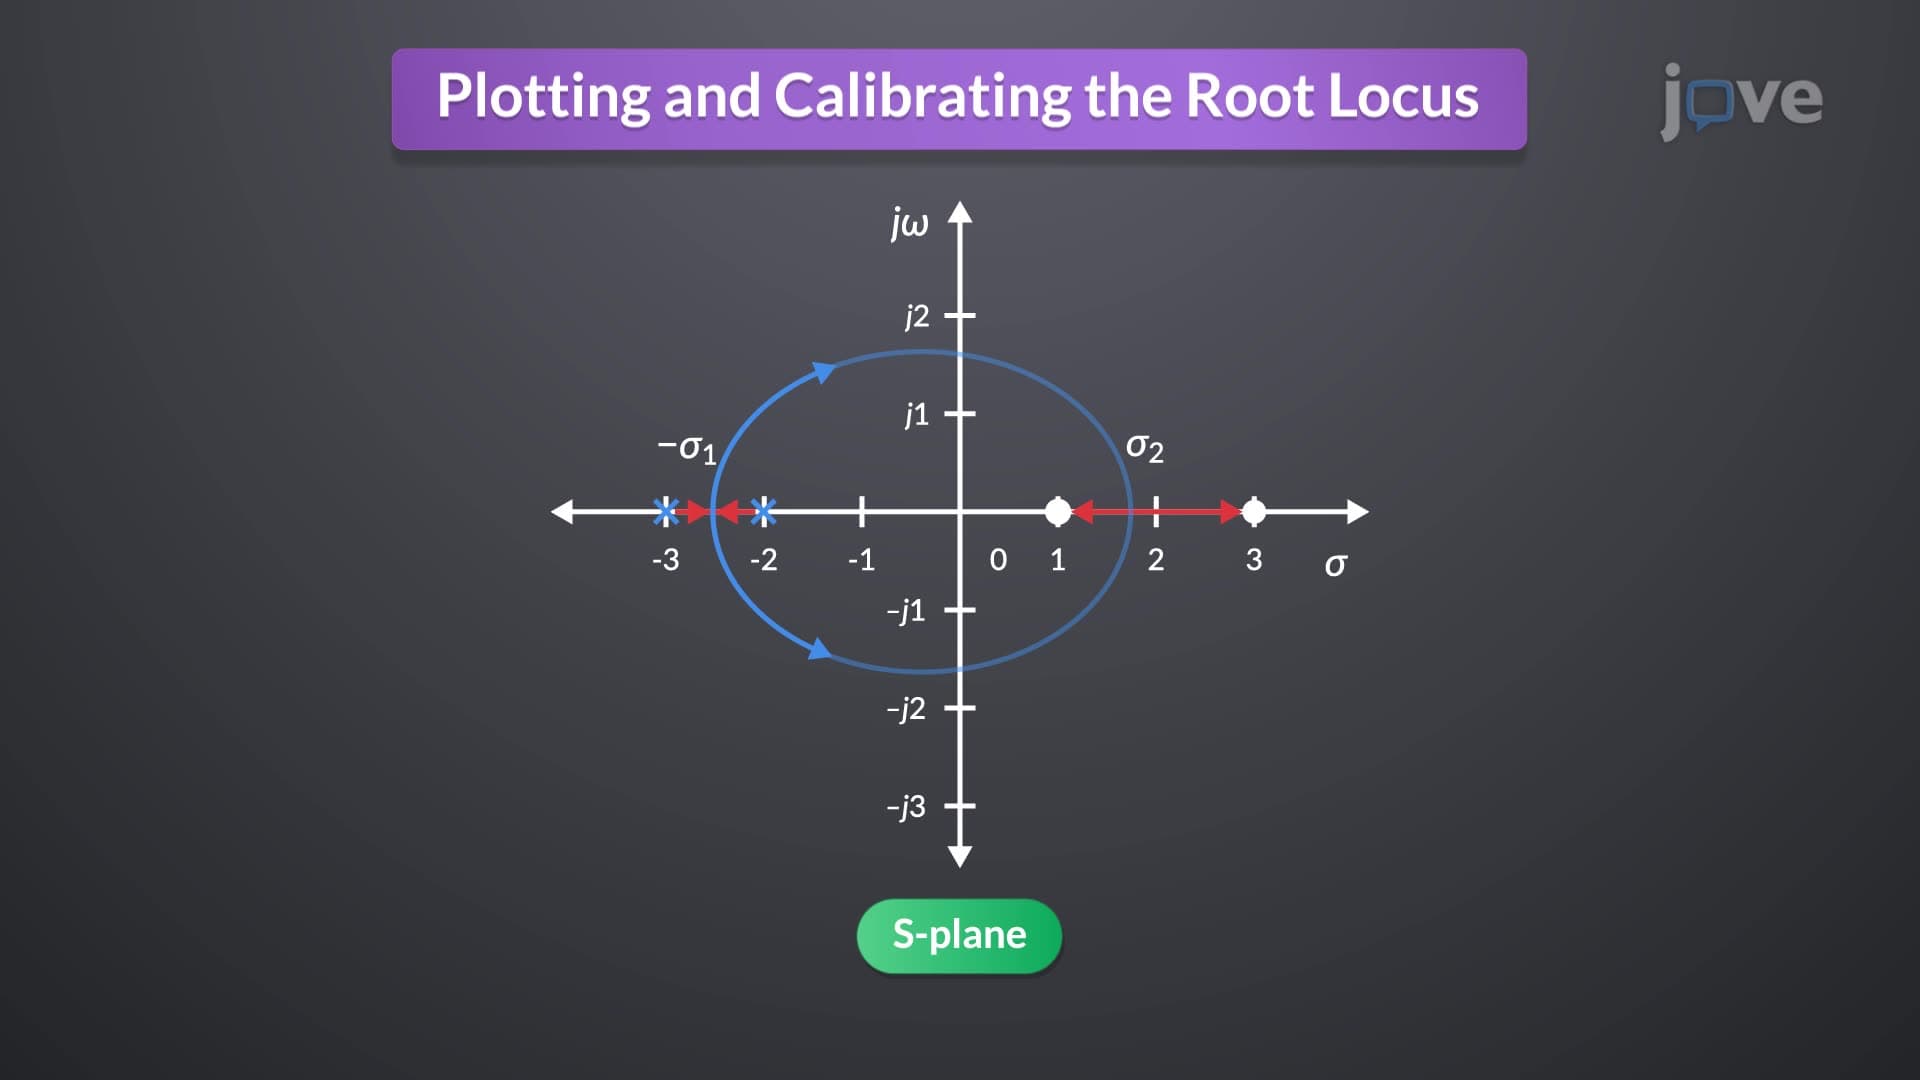
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:13
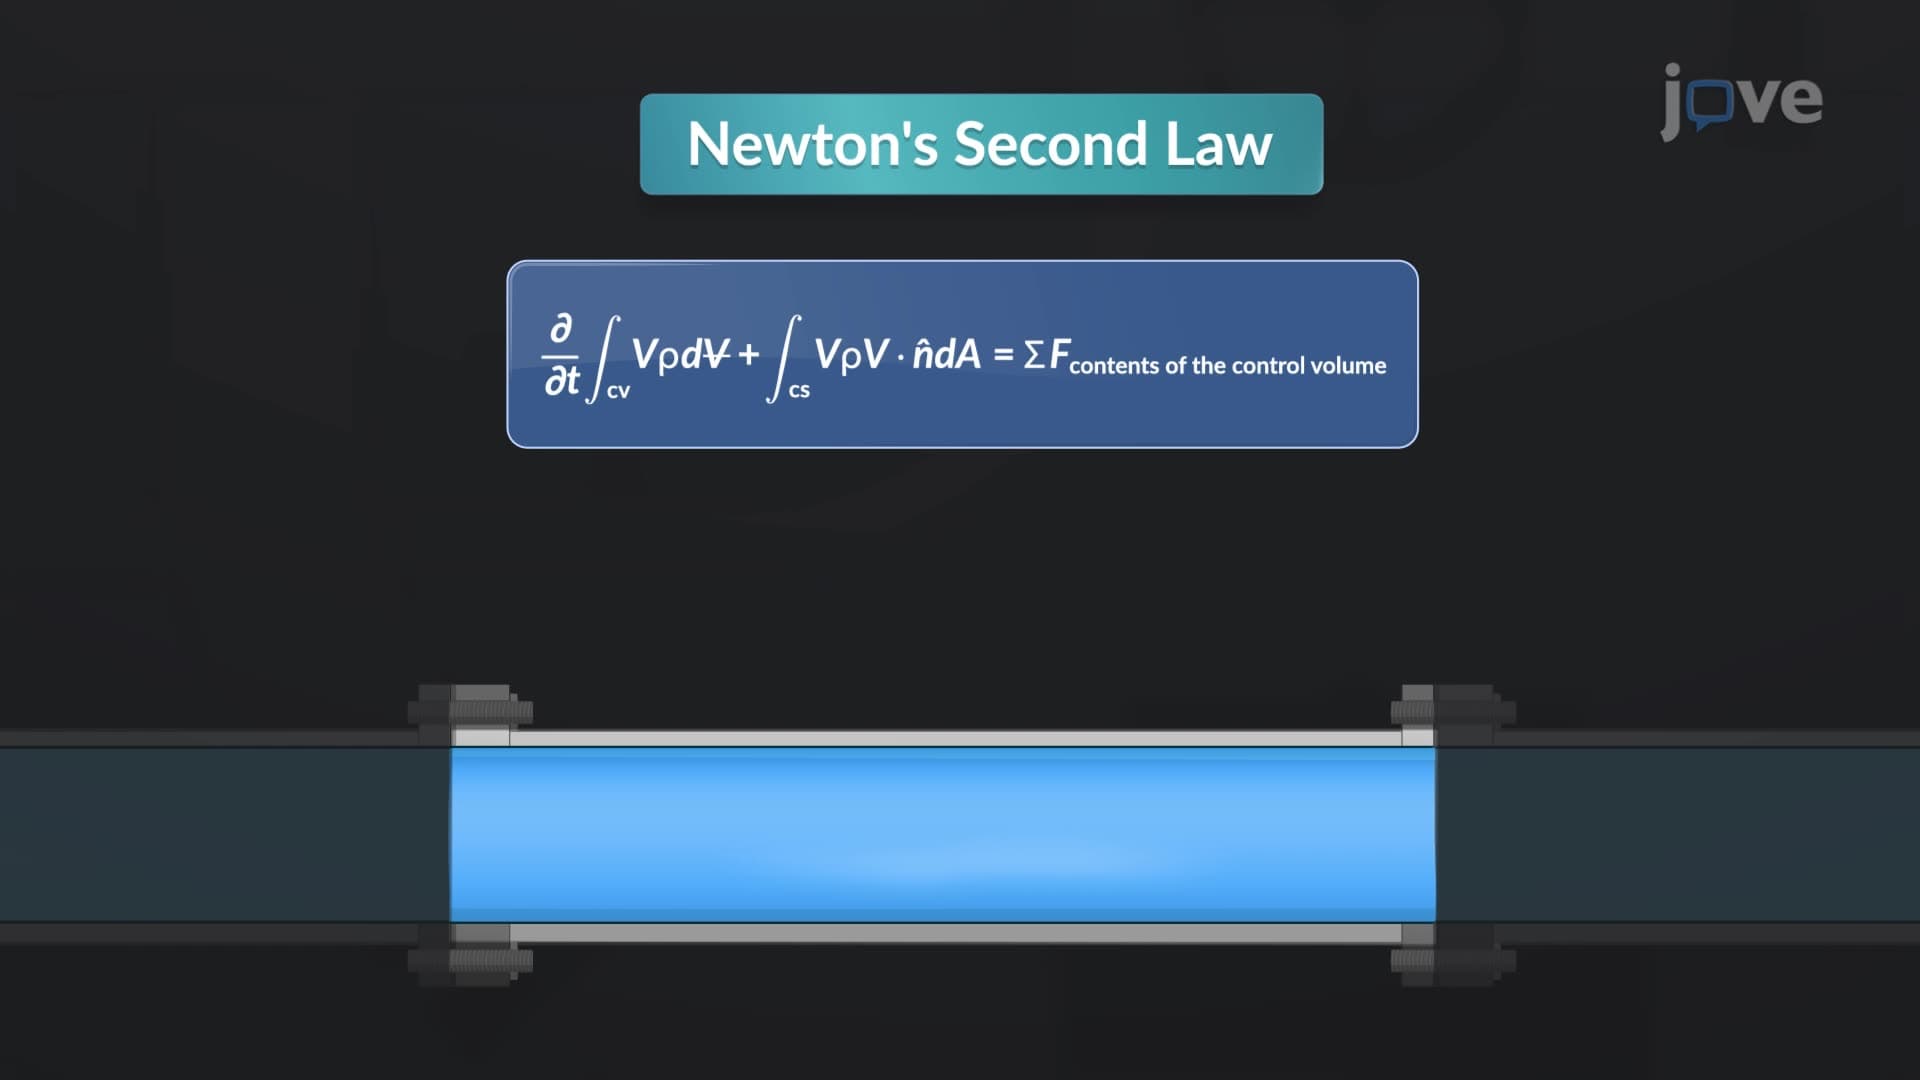
Linear Momentum in Control Volume