Kuramoto model subject to subsystem resetting: How resetting a part of the system may synchronize the whole of it
Rupak Majumder1, Rohitashwa Chattopadhyay1, Shamik Gupta1
1Department of Theoretical Physics, <a href="https://ror.org/03ht1xw27">Tata Institute of Fundamental Research</a>, Homi Bhabha Road, Mumbai 400005, India.

Abstract:
We introduce and investigate the effects of a new class of stochastic resetting protocol called subsystem resetting, whereby a subset of the system constituents in a many-body interacting system undergoes bare evolution interspersed with simultaneous resets at random times, while the remaining constituents evolve solely under the bare dynamics. Here, by reset is meant a reinitialization of the dynamics from a given state. We pursue our investigation within the ambit of the well-known Kuramoto model of coupled phase-only oscillators of distributed natural frequencies. Here, the reset protocol corresponds to a chosen set of oscillators being reset to a synchronized state at random times. We find that the mean ω_{0} of the natural frequencies plays a defining role in determining the long-time state of the system. For ω_{0}=0, the system reaches a synchronized stationary state at long times, characterized by a time-independent nonzero value of the synchronization order parameter that quantifies macroscopic order in the system. Moreover, we find that resetting even an infinitesimal fraction of the total number of oscillators, in the extreme limit of infinite resetting rate, has the drastic effect of synchronizing the entire system, even in parameter regimes in which the bare evolution does not support global synchrony. By contrast, for ω_{0}≠0, the dynamics allows at long times either a synchronized stationary state or an oscillatory synchronized state, with the latter characterized by an oscillatory behavior as a function of time of the order parameter, with a nonzero time-independent time average. Our results thus imply that the nonreset subsystem always gets synchronized at long times through the act of resetting of the reset subsystem. Our results, analytical using the Ott-Antonsen ansatz as well as those based on numerical simulations, are obtained for two representative oscillator frequency distributions, namely, a Lorentzian and a Gaussian. Given that it is easier to reset a fraction of the system constituents than the entire system, we discuss how subsystem resetting may be employed as an efficient mechanism to control attainment of global synchrony in the Kuramoto system.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 11:25
Simultaneous Scalp Electroencephalography EEG, Electromyography EMG, and Whole-body Segmental Inertial Recording for Multi-modal Neural Decoding
Published on: July 26, 2013
Related Concept Videos
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:30
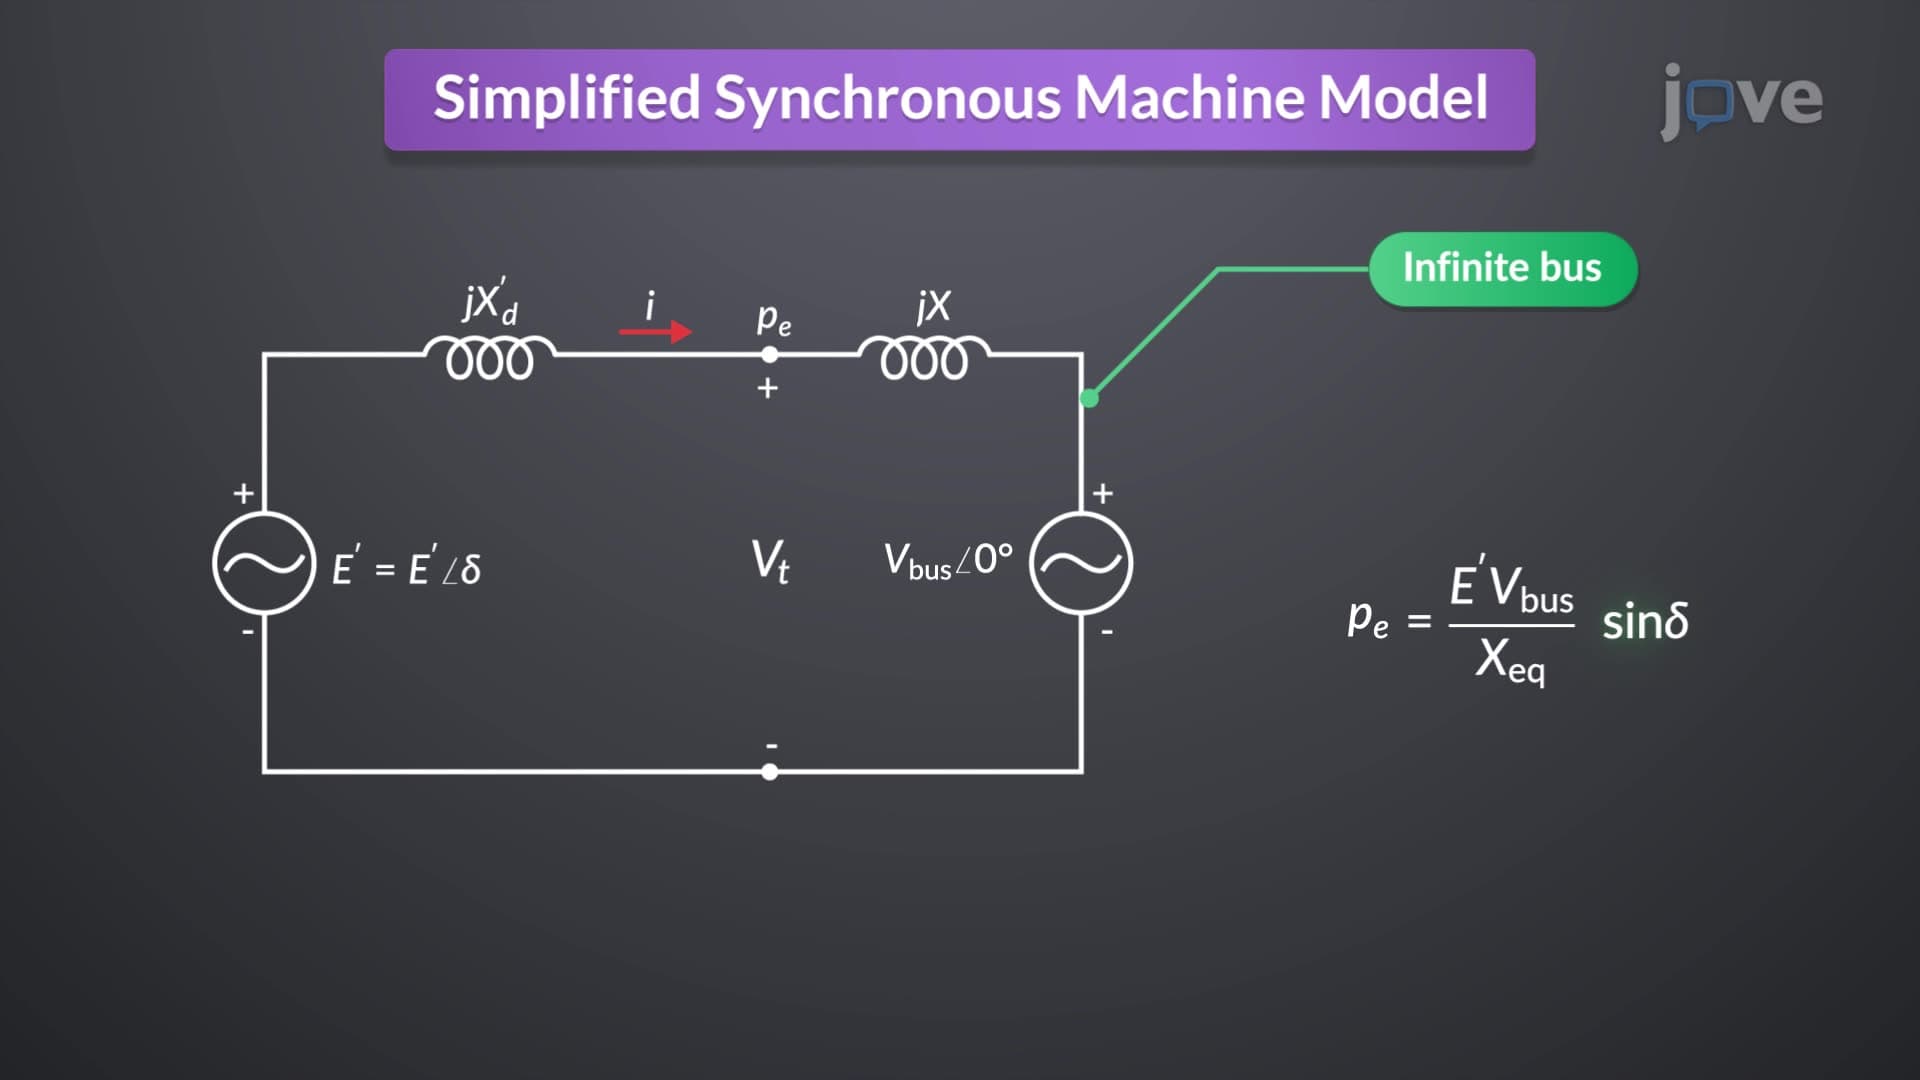
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:04
Oscillations about an Equilibrium Position
 01:13
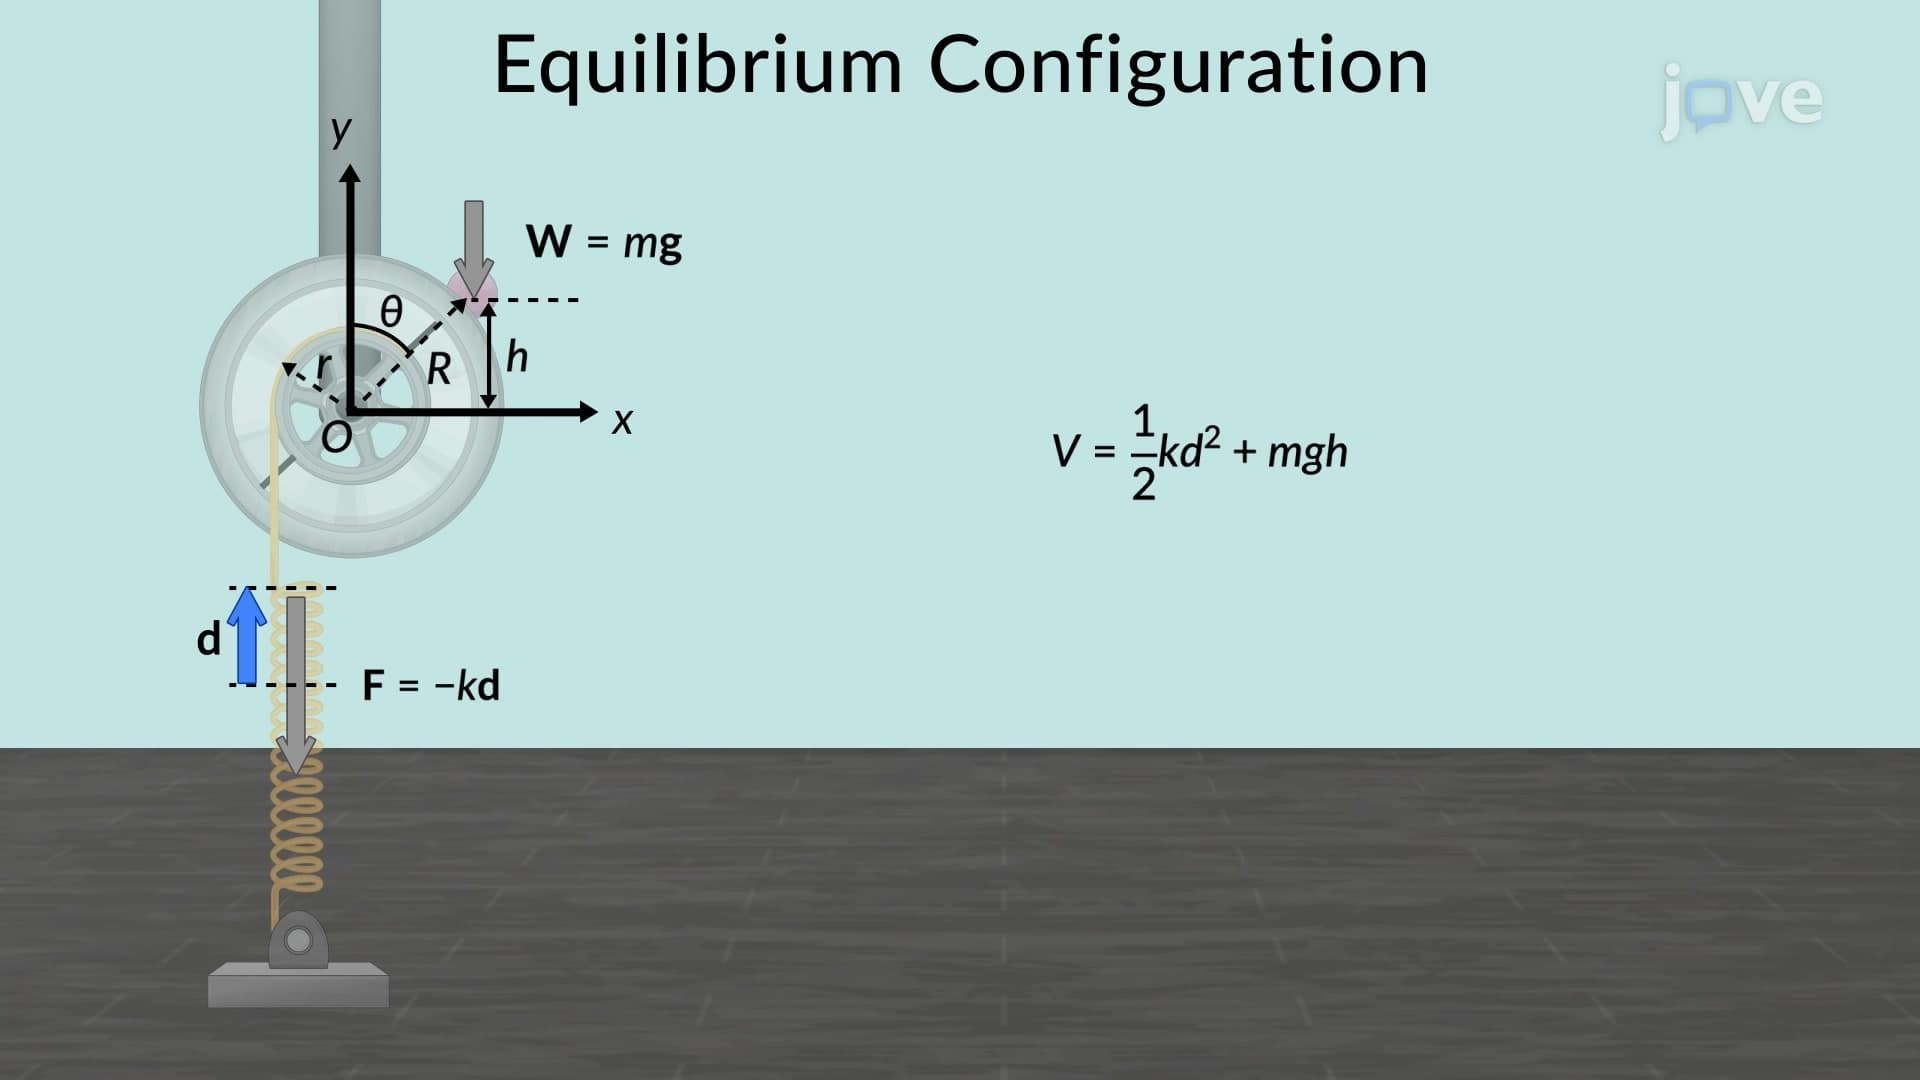
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...