Related Experiment Video
Updated: Jul 8, 2026
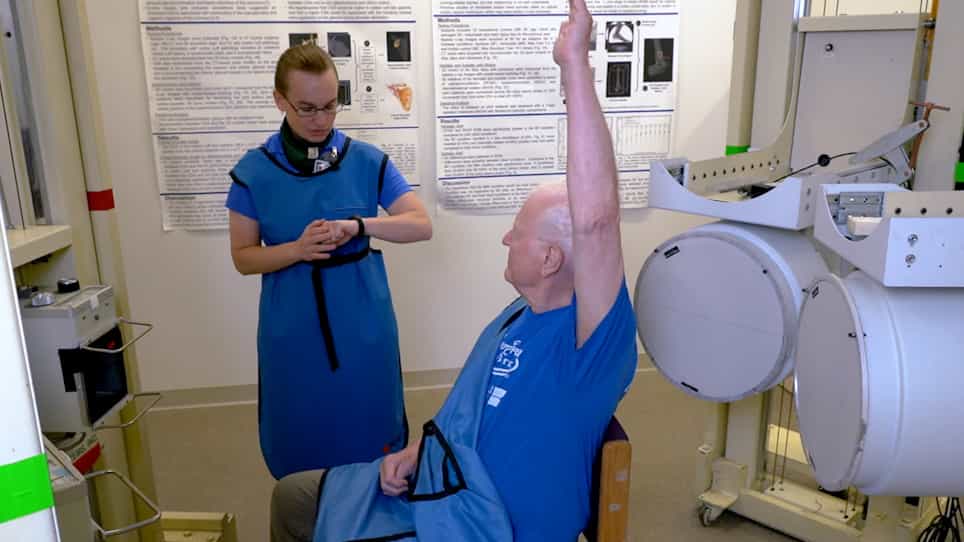
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Area of origin estimation from multiple arbitrarily oriented surfaces using marker-guided structure from motion
Philip Joris1, Ruben Moermans1, Els Jenar2
1Forentrics, Antwerp, Belgium; Department of Electrical Engineering, ESAT/PSI, KU Leuven, Leuven, Belgium; Medical Imaging Research Center, MIRC, KU Leuven, Leuven, Belgium.

Bloodstain pattern analysis plays a crucial role in forensic investigations. Projected patterns can offer valuable insights into the dynamics of crime scenes. In this paper, we propose and validate a novel approach that extends existing software, HemoVision, to analyze impact patterns that are distributed across multiple arbitrarily oriented surfaces. The proposed method integrates HemoVision's marker-based system with structure from motion (SfM) techniques to reconstruct the three-dimensional geometry of impact patterns using only two-dimensional photographs. Controlled experiments were used to validate the proposed approach, demonstrating robustness in reconstruction accuracy with median translation errors below 3 mm and median angular errors below 0.2°, irrespective of imaging device or image resolution. Comparing the estimated areas origin to their known ground truth, the proposed method achieved an average total error of 8.12 cm, with the primary source of error being the vertical dimension. Despite this, the overall error remains well within the ranges of error reported in prior work. This study demonstrates that HemoVision can be used to analyze complex impact patterns using only two-dimensional photographs, providing forensic experts with an efficient and accessible tool for investigating intricate crime scenes involving multi-surface impact patterns.
Bloodstain pattern analysis plays a crucial role in forensic investigations. Projected patterns can offer valuable insights into the dynamics of crime scenes. In this paper, we propose and validate a novel approach that extends existing software, HemoVision, to analyze impact patterns that are distributed across multiple arbitrarily oriented surfaces. The proposed method integrates HemoVision's marker-based system with structure from motion (SfM) techniques to reconstruct the three-dimensional geometry of impact patterns using only two-dimensional photographs. Controlled experiments were used to validate the proposed approach, demonstrating robustness in reconstruction accuracy with median translation errors below 3 mm and median angular errors below 0.2°, irrespective of imaging device or image resolution. Comparing the estimated areas origin to their known ground truth, the proposed method achieved an average total error of 8.12 cm, with the primary source of error being the vertical dimension. Despite this, the overall error remains well within the ranges of error reported in prior work. This study demonstrates that HemoVision can be used to analyze complex impact patterns using only two-dimensional photographs, providing forensic experts with an efficient and accessible tool for investigating intricate crime scenes involving multi-surface impact patterns.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Oriented Surfaces