Related Experiment Video
Updated: Jun 20, 2025

A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
Bayesian reinforcement learning for navigation planning in unknown environments
1Department of Electrical and Computer Engineering, Northeastern University, Boston, MA, United States.

Abstract:
This study focuses on a rescue mission problem, particularly enabling agents/robots to navigate efficiently in unknown environments. Technological advances, including manufacturing, sensing, and communication systems, have raised interest in using robots or drones for rescue operations. Effective rescue operations require quick identification of changes in the environment and/or locating the victims/injuries as soon as possible. Several techniques have been developed in recent years for autonomy in rescue missions, including motion planning, adaptive control, and more recently, reinforcement learning techniques. These techniques rely on full knowledge of the environment or the availability of simulators that can represent real environments during rescue operations. However, in practice, agents might have little or no information about the environment or the number or locations of injuries, preventing/limiting the application of most existing techniques. This study provides a probabilistic/Bayesian representation of the unknown environment, which jointly models the stochasticity in the agent's navigation and the environment uncertainty into a vector called the belief state. This belief state allows offline learning of the optimal Bayesian policy in an unknown environment without the need for any real data/interactions, which guarantees taking actions that are optimal given all available information. To address the large size of belief space, deep reinforcement learning is developed for computing an approximate Bayesian planning policy. The numerical experiments using different maze problems demonstrate the high performance of the proposed policy.
Related Concept Videos
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:25
The Anchoring-and-Adjustment Heuristic
 01:16
Statically Indeterminate Problem Solving
 01:09
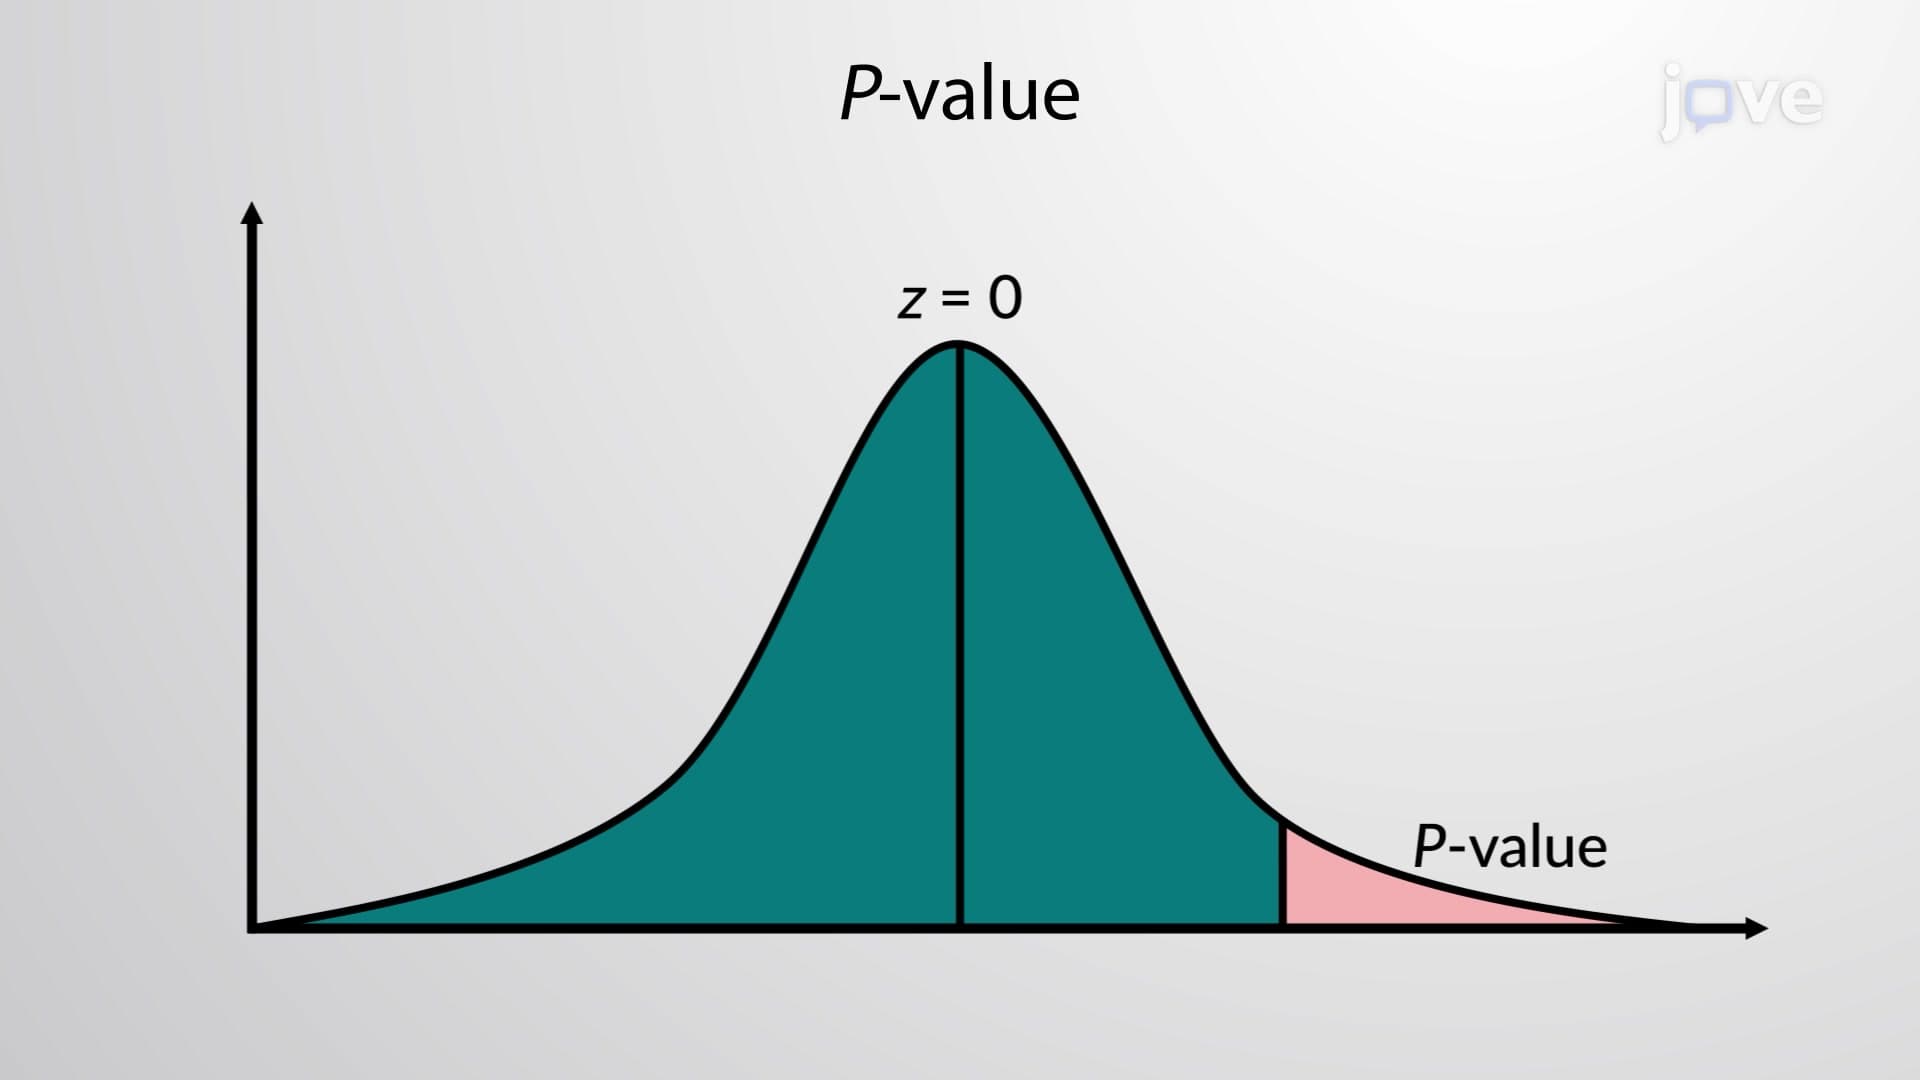
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...