Related Experiment Video
Updated: Jun 25, 2026
Using an Automated 3D-tracking System to Record Individual and Shoals of Adult Zebrafish
Published on: December 5, 2013
A 3-DOF caudal fin for precise maneuvering of thunniform-inspired unmanned underwater vehicles
Cecilia Huertas-Cerdeira1,2, Morteza Gharib3
1Division of Engineering and Applied Science, California Institute of Technology, Pasadena, CA, USA. huertas@umd.edu.

Abstract:
Unmanned underwater vehicles (UUVs) will see increased use in scientific research, military operations and maintenance of industrial infrastructure. Many of these applications require that the vehicle possess a long range while retaining precise maneuvering or station-keeping capabilities. Both current UUVs and biological swimmers, often considered the basis for the next generation of UUVs, face a trade-off between the two characteristics. Here, we introduce a novel hybrid propeller concept that enables thunniform-inspired vehicles, which imitate nature's most efficient swimmers, to also achieve high maneuverability. The propeller can produce enhanced three-dimensional kinematics of the caudal fin. An optimization procedure based on real-time experimental data is used to obtain the best kinematics to maneuver the vehicle, and a 4-step strategy is uncovered that results in a 49% increase in maneuverability with respect to conventional 2-D kinematics. The proposed mechanism is shown to be effective for a wide range of fin geometries and stiffness values.
Related Concept Videos
 01:12
Buoyancy
To get...
 01:30
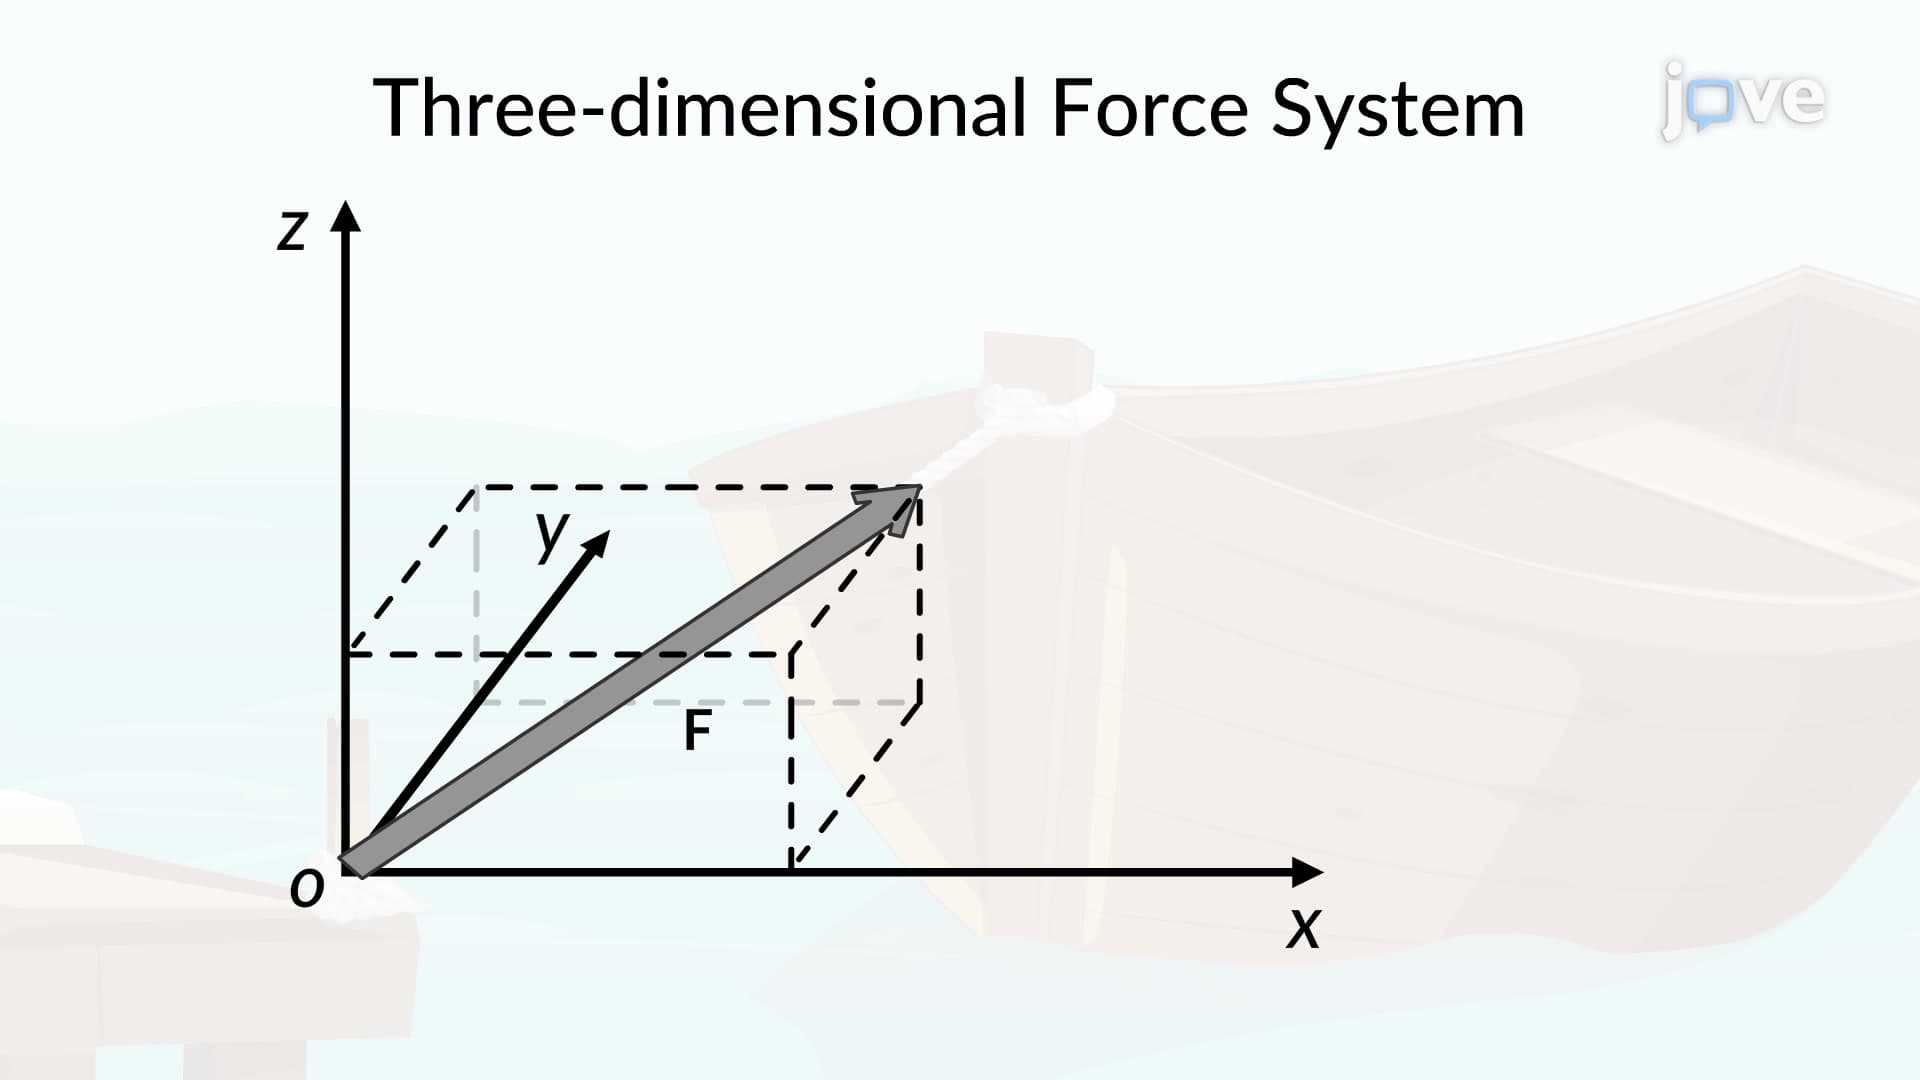
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies