Related Experiment Video
Updated: May 7, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Polarimetric Imaging for Robot Perception: A Review
Camille Taglione1, Carlos Mateo2, Christophe Stolz1
1Vibot, ImViA UR 7535, Université de Bourgogne, 12 Rue de la Fonderie, 71200 Le Creusot, France.

Abstract:
In recent years, the integration of polarimetric imaging into robotic perception systems has increased significantly, driven by the accessibility of affordable polarimetric sensors. This technology complements traditional color imaging by capturing and analyzing the polarization characteristics of light. This additional information provides robots with valuable insights into object shape, material composition, and other properties, ultimately enabling more robust manipulation tasks. This review aims to provide a comprehensive analysis of the principles behind polarimetric imaging and its diverse applications within the field of robotic perception. By exploiting the polarization state of light, polarimetric imaging offers promising solutions to three key challenges in robot vision: Surface segmentation; depth estimation through polarization patterns; and 3D reconstruction using polarimetric data. This review emphasizes the practical value of polarimetric imaging in robotics by demonstrating its effectiveness in addressing real-world challenges. We then explore potential applications of this technology not only within the core robotics field but also in related areas. Through a comparative analysis, our goal is to elucidate the strengths and limitations of polarimetric imaging techniques. This analysis will contribute to a deeper understanding of its broad applicability across various domains within and beyond robotics.
More Related Videos

Related Concept Videos
 01:24
Gyroscope: Precession
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:24
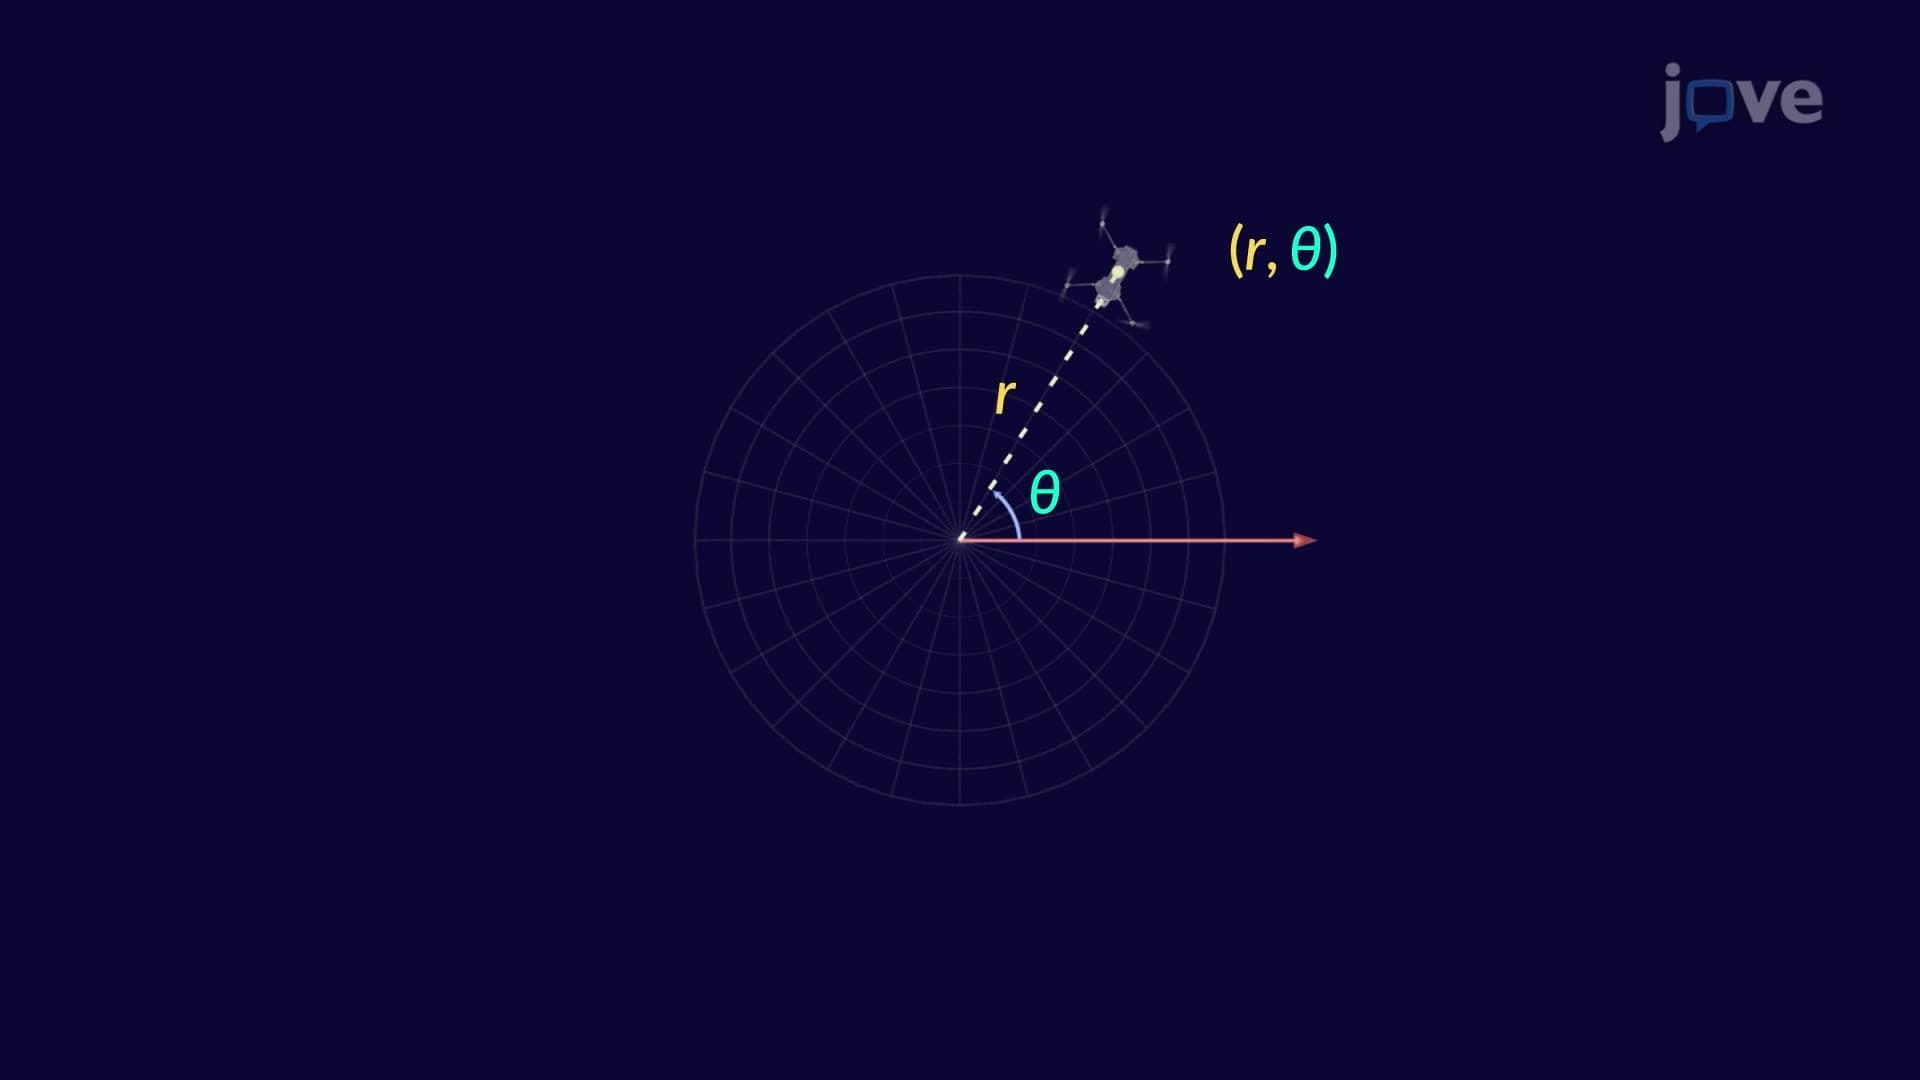
Polar Coordinates