Related Experiment Video
Updated: Jun 17, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Hybrid Orientation and Position Collaborative Motion Generation Scheme for a Multiple Mobile Redundant Manipulator

Abstract:
To enable distributed multiple mobile manipulator systems to complete collaborative tasks safely and stably, this article investigates and presents a motion generation scheme that considers both orientation and position coordination based on a distributed recurrent neural network. Moreover, physical limits are also considered. Specifically, the orientation and position coordination constraints and physical limits are modeled separately as equality and inequality constraints with coupled variables. Subsequently, a motion generation scheme for multiple mobile manipulators based on quadratic programming is established. Finally, a distributed linear variational inequality-based primal-dual neural network is constructed to solve the motion generation scheme and obtain the motion trajectories of all the mobile manipulators. The simulation results demonstrate that the hybrid orientation and position collaboration motion generation scheme effectively addresses the position and orientation coordination problem for multiple mobile manipulator systems. Compared to other schemes, the proposed scheme based on a distributed computing structure greatly enhances the stability of the system. Additionally, the proposed approach introduces orientation coordination and physical limits, which increases the practicality of the system.


Related Concept Videos
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:23
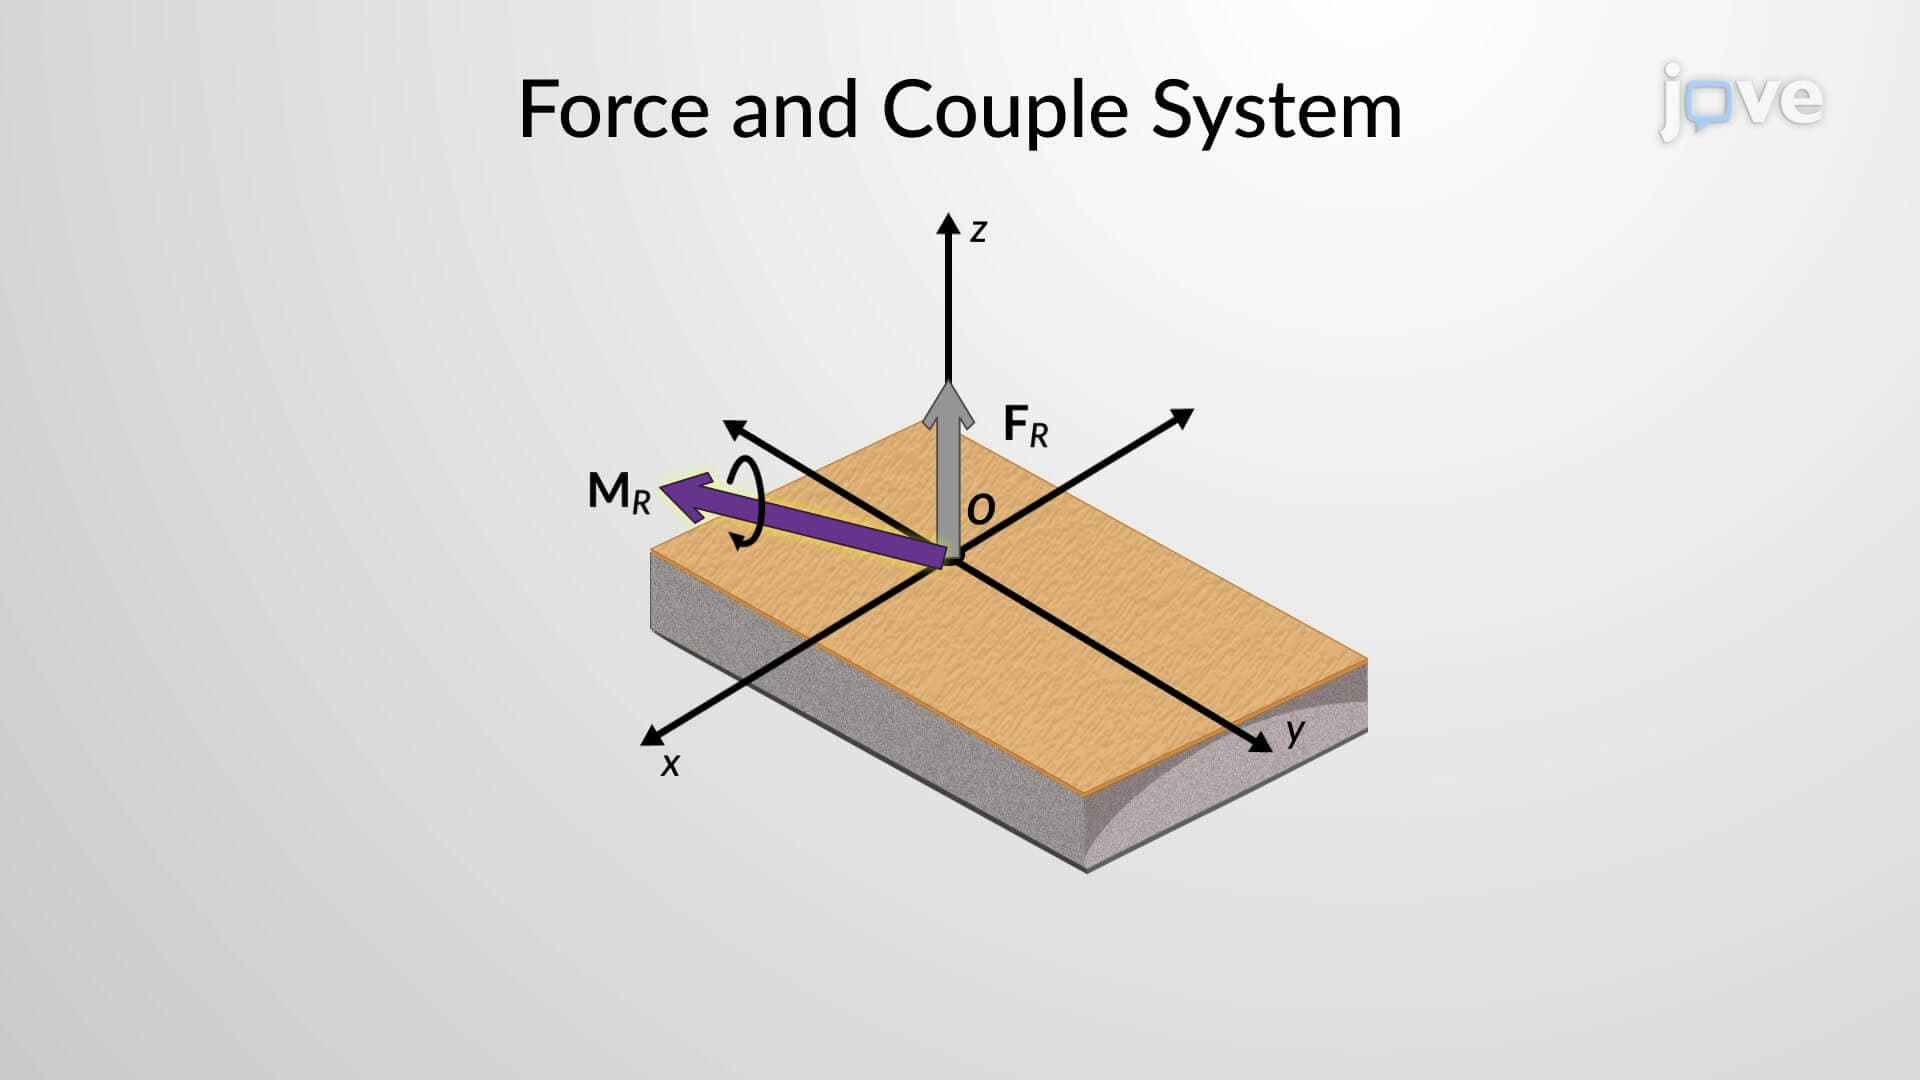
Simplification of a Force and Couple System: II
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...