360 Layout Estimation via Orthogonal Planes Disentanglement and Multi-View Geometric Consistency Perception
Related Experiment Video
Updated: Jun 17, 2025

Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021

Abstract:
Existing panoramic layout estimation solutions tend to recover room boundaries from a vertically compressed sequence, yielding imprecise results as the compression process often muddles the semantics between various planes. Besides, these data-driven approaches impose an urgent demand for massive data annotations, which are laborious and time-consuming. For the first problem, we propose an orthogonal plane disentanglement network (termed DOPNet) to distinguish ambiguous semantics. DOPNet consists of three modules that are integrated to deliver distortion-free, semantics-clean, and detail-sharp disentangled representations, which benefit the subsequent layout recovery. For the second problem, we present an unsupervised adaptation technique tailored for horizon-depth and ratio representations. Concretely, we introduce an optimization strategy for decision-level layout analysis and a 1D cost volume construction method for feature-level multi-view aggregation, both of which are designed to fully exploit the geometric consistency across multiple perspectives. The optimizer provides a reliable set of pseudo-labels for network training, while the 1D cost volume enriches each view with comprehensive scene information derived from other perspectives. Extensive experiments demonstrate that our solution outperforms other SoTA models on both monocular layout estimation and multi-view layout estimation tasks.


Related Concept Videos
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
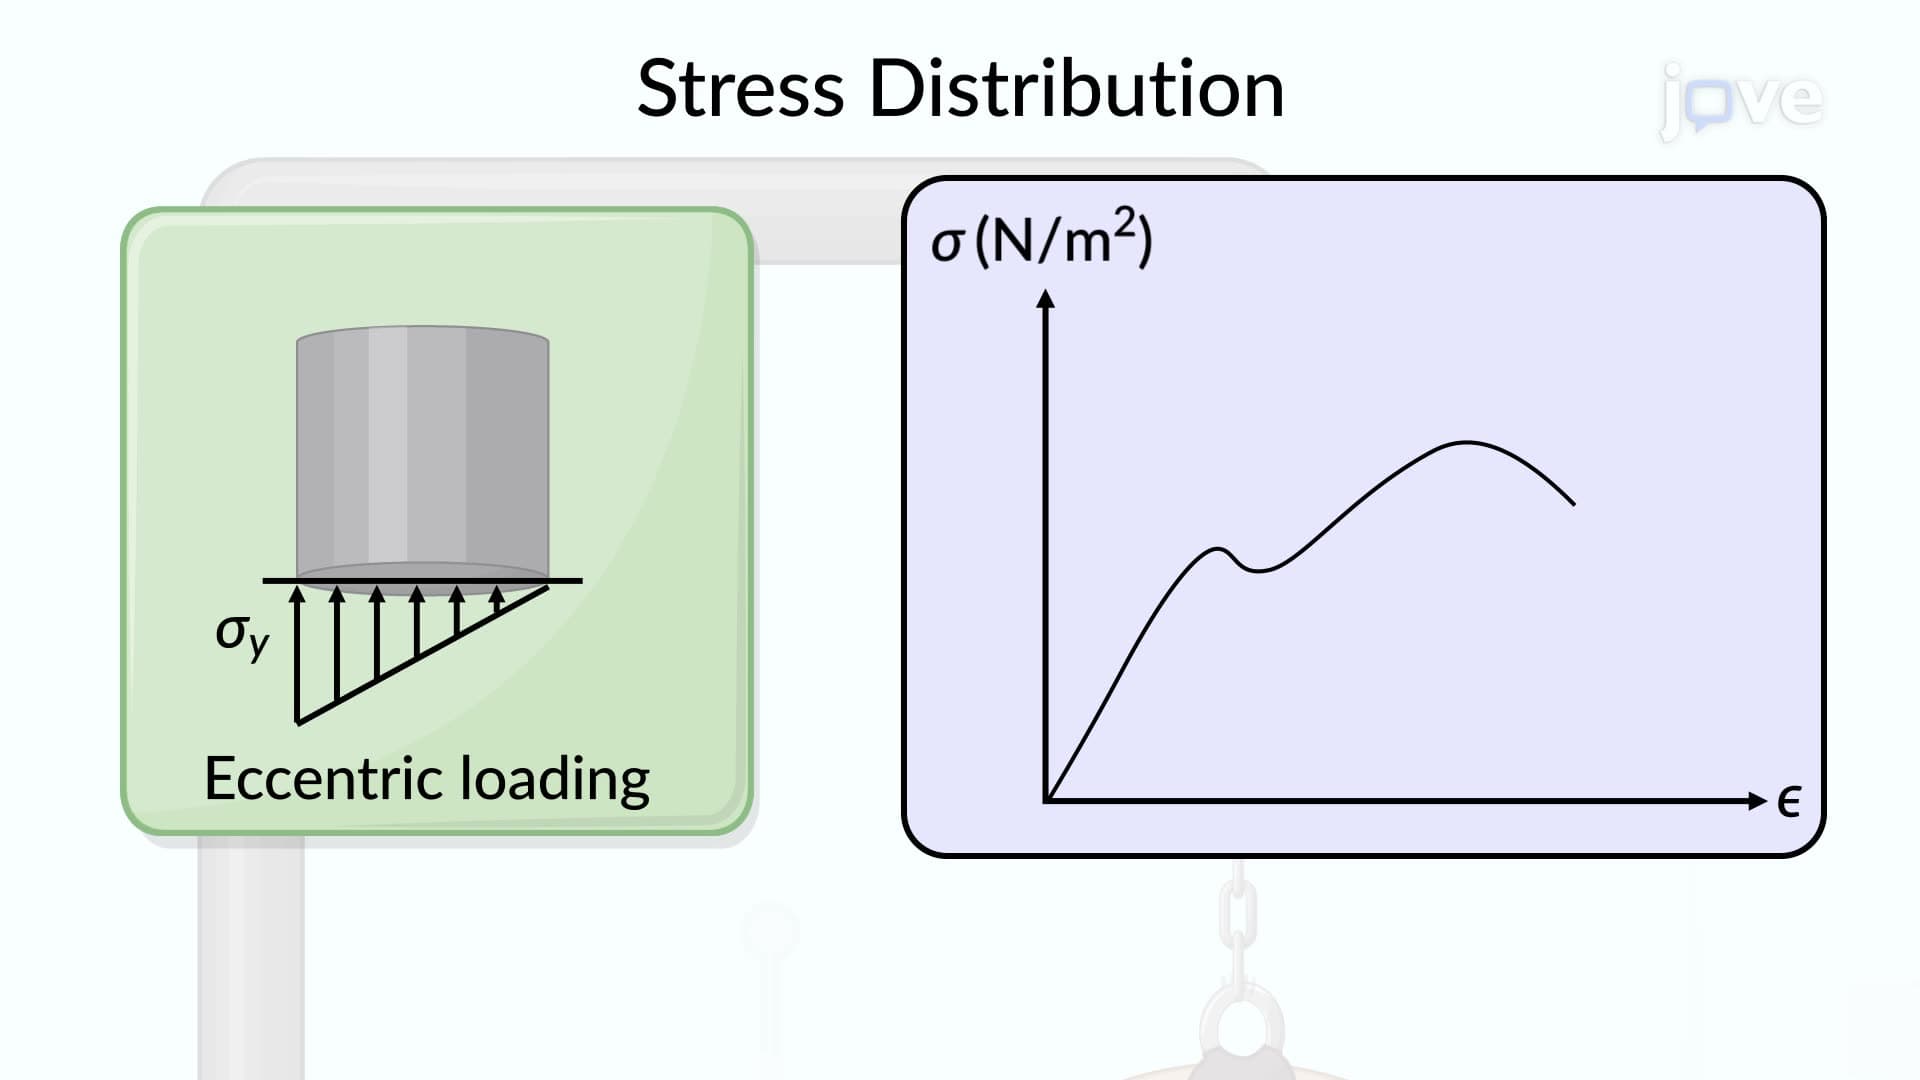
Eccentric Axial Loading in a Plane of Symmetry
 01:12
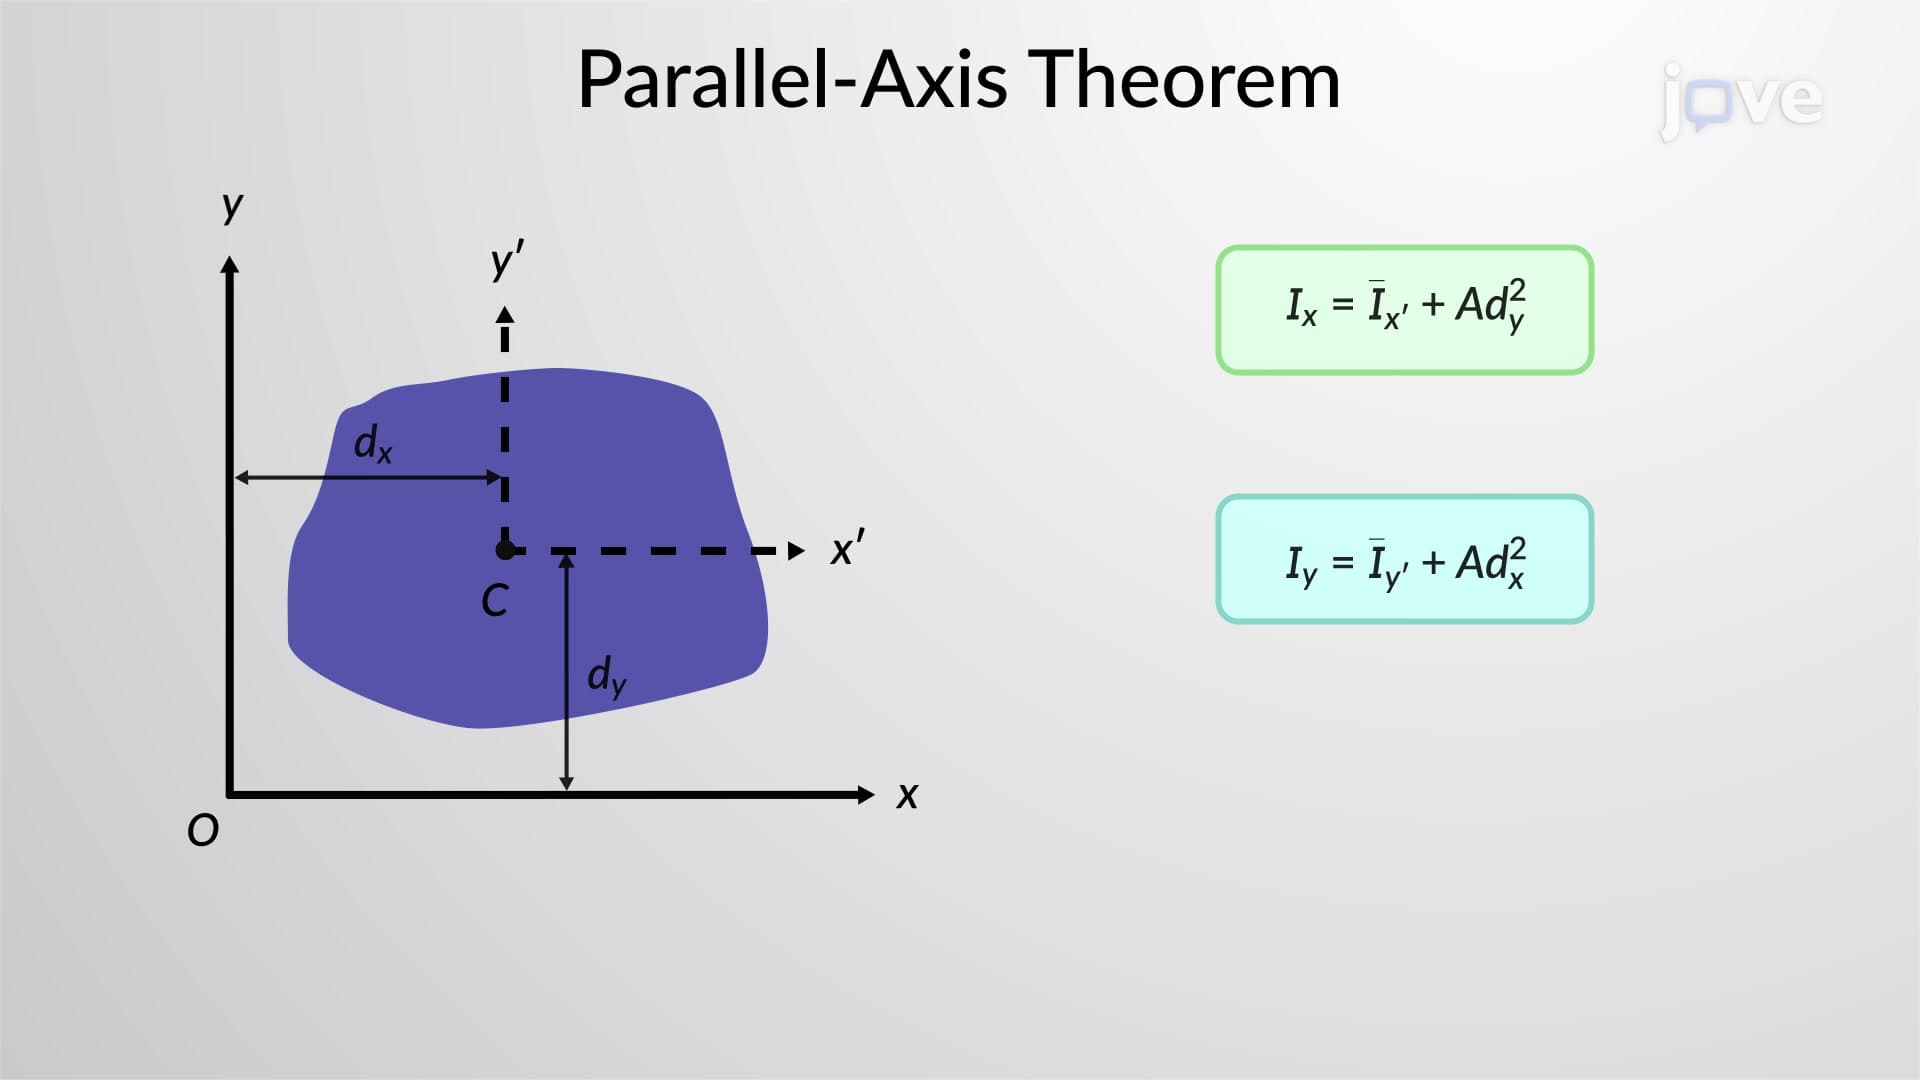
Parallel-Axis Theorem for an Area
For a flywheel approximated as a solid disc, consider an infinitesimal differential element with an arbitrary distance...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:16
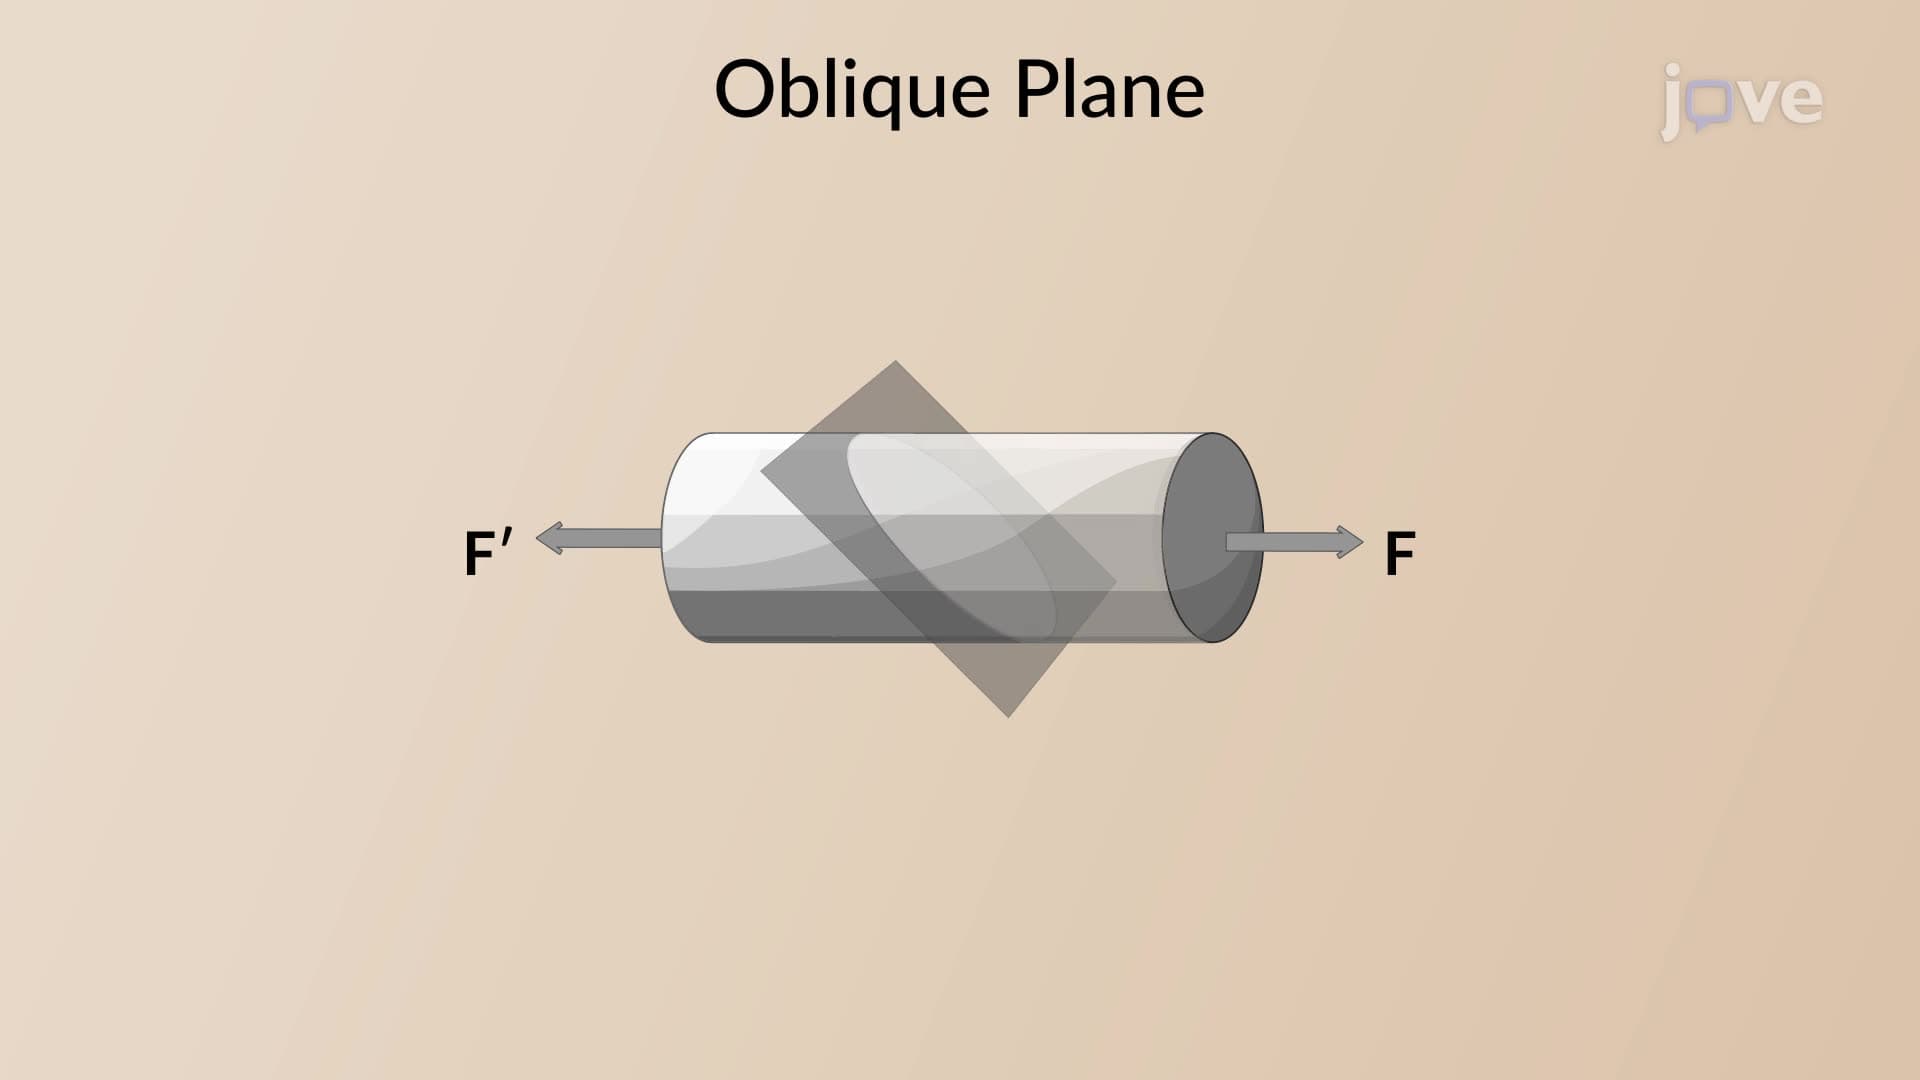
Stress on an Oblique Plane