Metric3D v2: A Versatile Monocular Geometric Foundation Model for Zero-Shot Metric Depth and Surface Normal Estimation
Related Experiment Video
Updated: May 10, 2026
Extracting Metrics for Three-dimensional Root Systems: Volume and Surface Analysis from In-soil X-ray Computed Tomography Data
Published on: April 26, 2016

Abstract:
We introduce Metric3D v2, a geometric foundation model designed for zero-shot metric depth and surface normal estimation from single images, critical for accurate 3D recovery. Depth and normal estimation, though complementary, present distinct challenges. State-of-the-art monocular depth methods achieve zero-shot generalization through affine-invariant depths, but fail to recover real-world metric scale. Conversely, current normal estimation techniques struggle with zero-shot performance due to insufficient labeled data. We propose targeted solutions for both metric depth and normal estimation. For metric depth, we present a canonical camera space transformation module that resolves metric ambiguity across various camera models and large-scale datasets, which can be easily integrated into existing monocular models. For surface normal estimation, we introduce a joint depth-normal optimization module that leverages diverse data from metric depth, allowing normal estimators to improve beyond traditional labels. Our model, trained on over 16 million images from thousands of camera models with varied annotations, excels in zero-shot generalization to new camera settings. As shown in Fig. 1, It ranks the 1st in multiple zero-shot and standard benchmarks for metric depth and surface normal prediction. Our method enables the accurate recovery of metric 3D structures on randomly collected internet images, paving the way for plausible single-image metrology. Our model also relieves the scale drift issues of monocular-SLAM (Fig. 3), leading to high-quality metric scale dense mapping. Such applications highlight the versatility of Metric3D v2 models as geometric foundation models.

Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
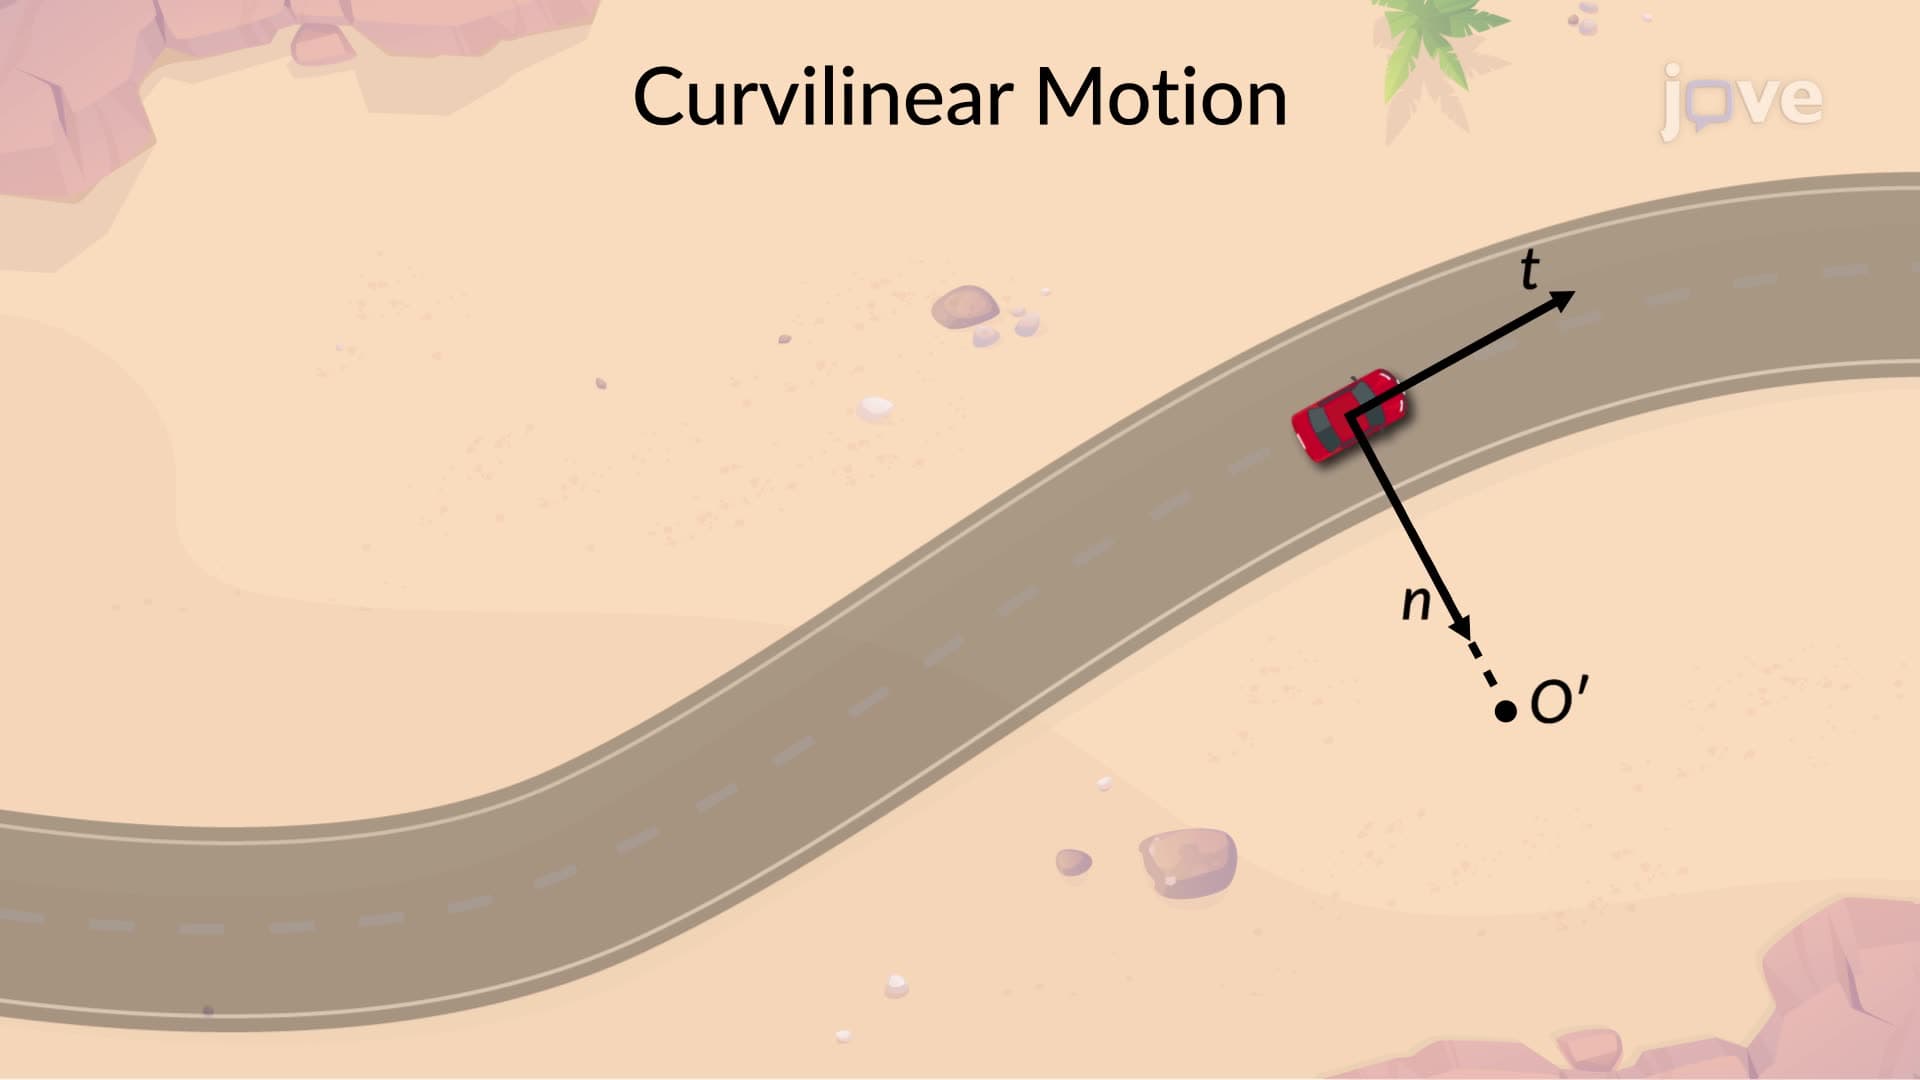
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:15
Depth Perception and Spatial Vision
 01:26
Introduction and Methods of Leveling
 01:29
Two-Dimensional Microscopy in Microbiology
 01:28
Three-Dimensional Microscopy in Microbiology