
Skew-product attractors of non-autonomous Caputo fractional differential equations

Hongyong Cui1, Peter E Kloeden2

  • 1School of Mathematics and Statistics and Hubei Key Laboratory of Engineering Modeling and Scientific Computing, Huazhong University of Science and Technology, Wuhan 430074, People's Republic of China.

Chaos (Woodbury, N.Y.)
|August 20, 2024
PubMed

Related Concept Videos

Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
75
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
96
Linear Approximation in Frequency Domain01:26

Linear Approximation in Frequency Domain

Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
88
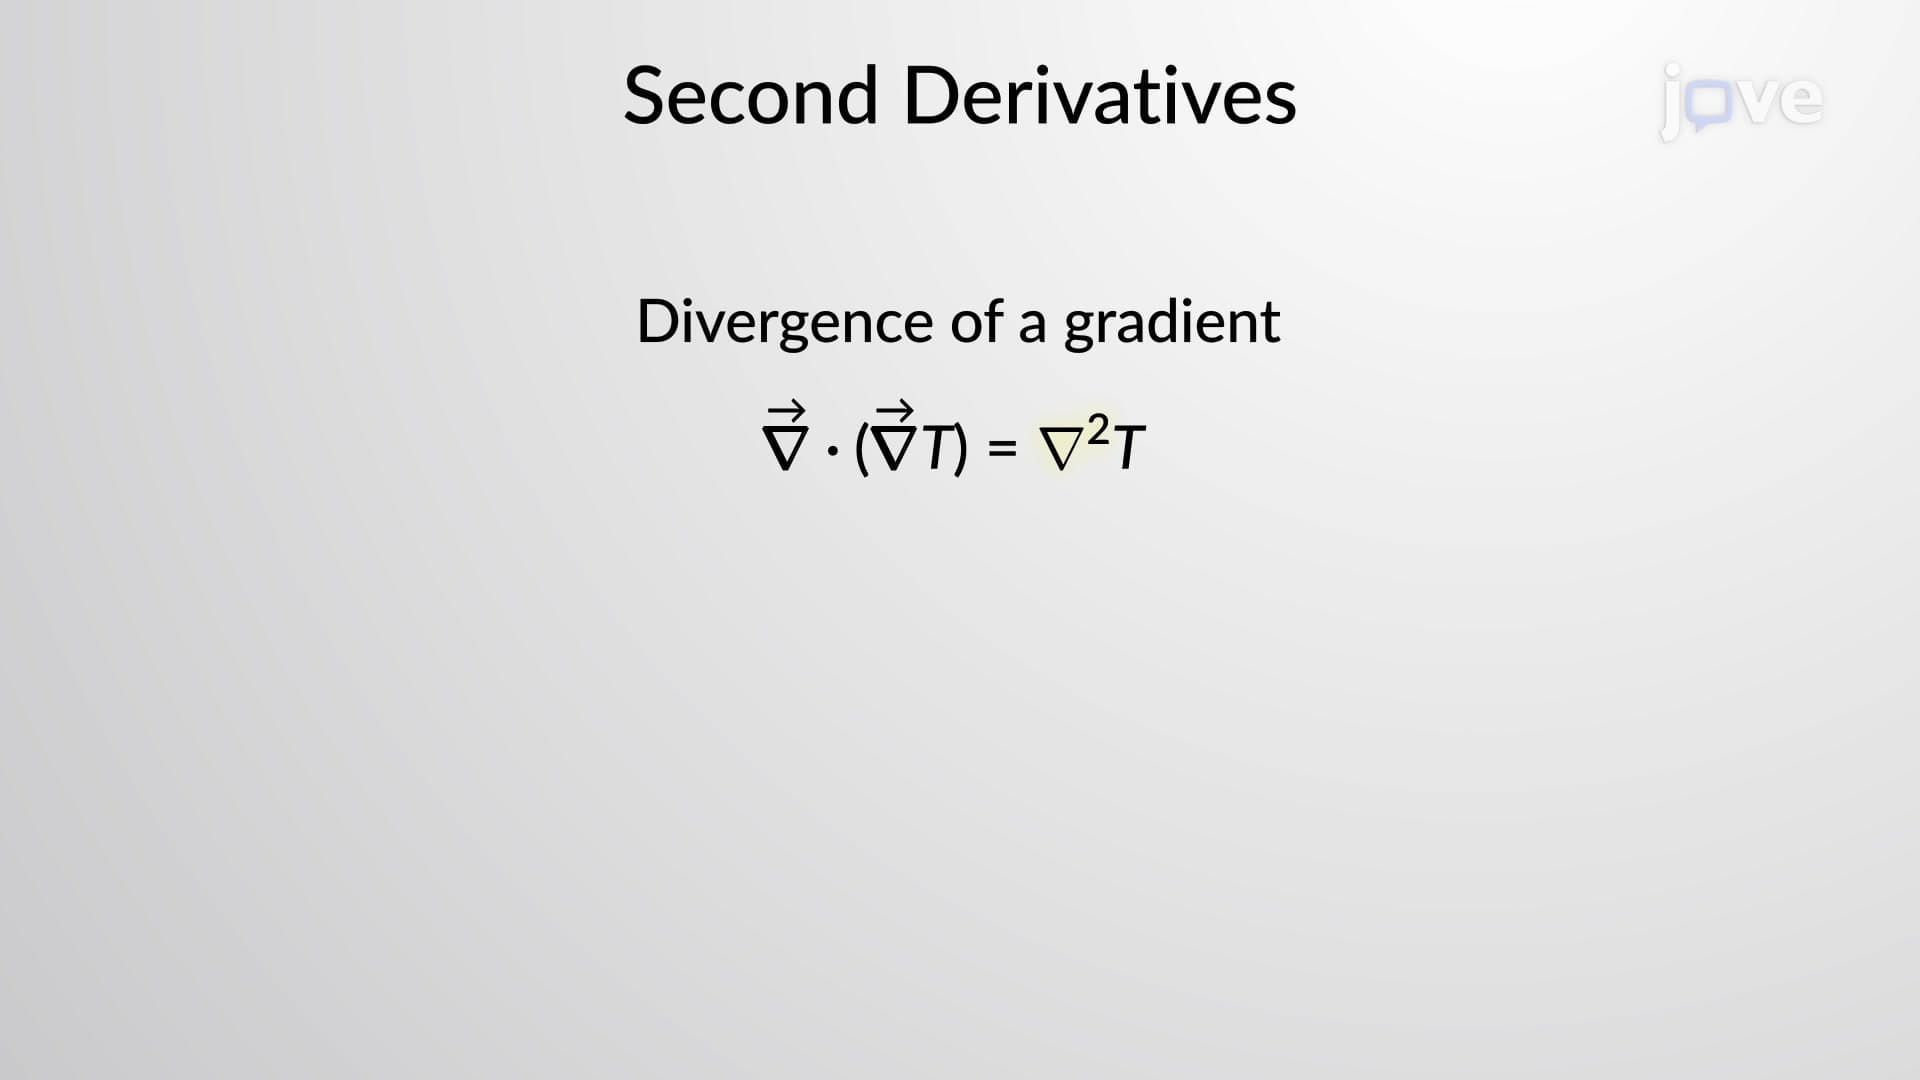
Second Derivatives and Laplace Operator01:22

Second Derivatives and Laplace Operator

The first order operators using the del operator include the gradient, divergence and curl. Certain combinations of first order operators on a scalar or vector function yield second order expressions. Second-order expressions play a very important role in mathematics and physics. Some second order expressions include the divergence and curl of a gradient function, the divergence and curl of a curl function, and the gradient of a divergence function.
Consider a scalar function. The curl of its...
1.2K
Transmission-Line Differential Equations01:26

Transmission-Line Differential Equations

Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
251
State Space Representation01:27

State Space Representation

The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
183

