Related Experiment Video
Updated: Jun 15, 2025


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Numerical model of the locomotion of oscillating 'robots' with frictional anisotropy on differently-structured
Alexander Filippov1,2, Stanislav Gorb3
1Department of Functional Morphology and Biomechanics, Zoological Institute of the Kiel University, Am Botanischen Garten 1-9, 24098, Kiel, Germany.

Abstract:
In engineering materials, surface anisotropy is known in certain textured patterns that appear during the manufacturing process. In biology, there are numerous examples of mechanical systems which combine anisotropic surfaces with the motion, elicited due to some actuation using muscles or stimuli-responsive materials, such as highly ordered cellulose fiber arrays of plant seeds. The systems supplemented by the muscles are rather fast actuators, because of the relatively high speed of muscle contraction, whereas the latter ones are very slow, because they generate actuation depending on the daily changes in the environmental air humidity. If the substrate has ordered surface profile, one can expect certain statistical order of potential trajectories (depending on the order of the spatial distribution of the surface asperities). If not, the expected trajectories can be statistically rather random. The same presumably holds true for the artificial miniature robots that use actuation in combination with frictional anisotropy. In order to prove this hypothesis, we developed numerical model helping us to study abovementioned cases of locomotion in 2D space on an uneven terrain. We show that at extremely long times, these systems tends to behave according to the rules of ballistic diffusion. Physically, it means that their motion tends to be associated with the "channels" of the patterned substrate. Such a motion is more or less the same as it should be in the uniform space. Such asymptotic behavior is specific for the motion in model regular potential and would be impossible on more realistic (and complex) fractal reliefs. However, one can expect that in any kind of the potential with certain symmetry (hexagonal or rhombic, for example), where it is still possible to find the ways, the motion along fixed direction during long (or even almost infinite) time intervals is possible.

Related Concept Videos
 01:05
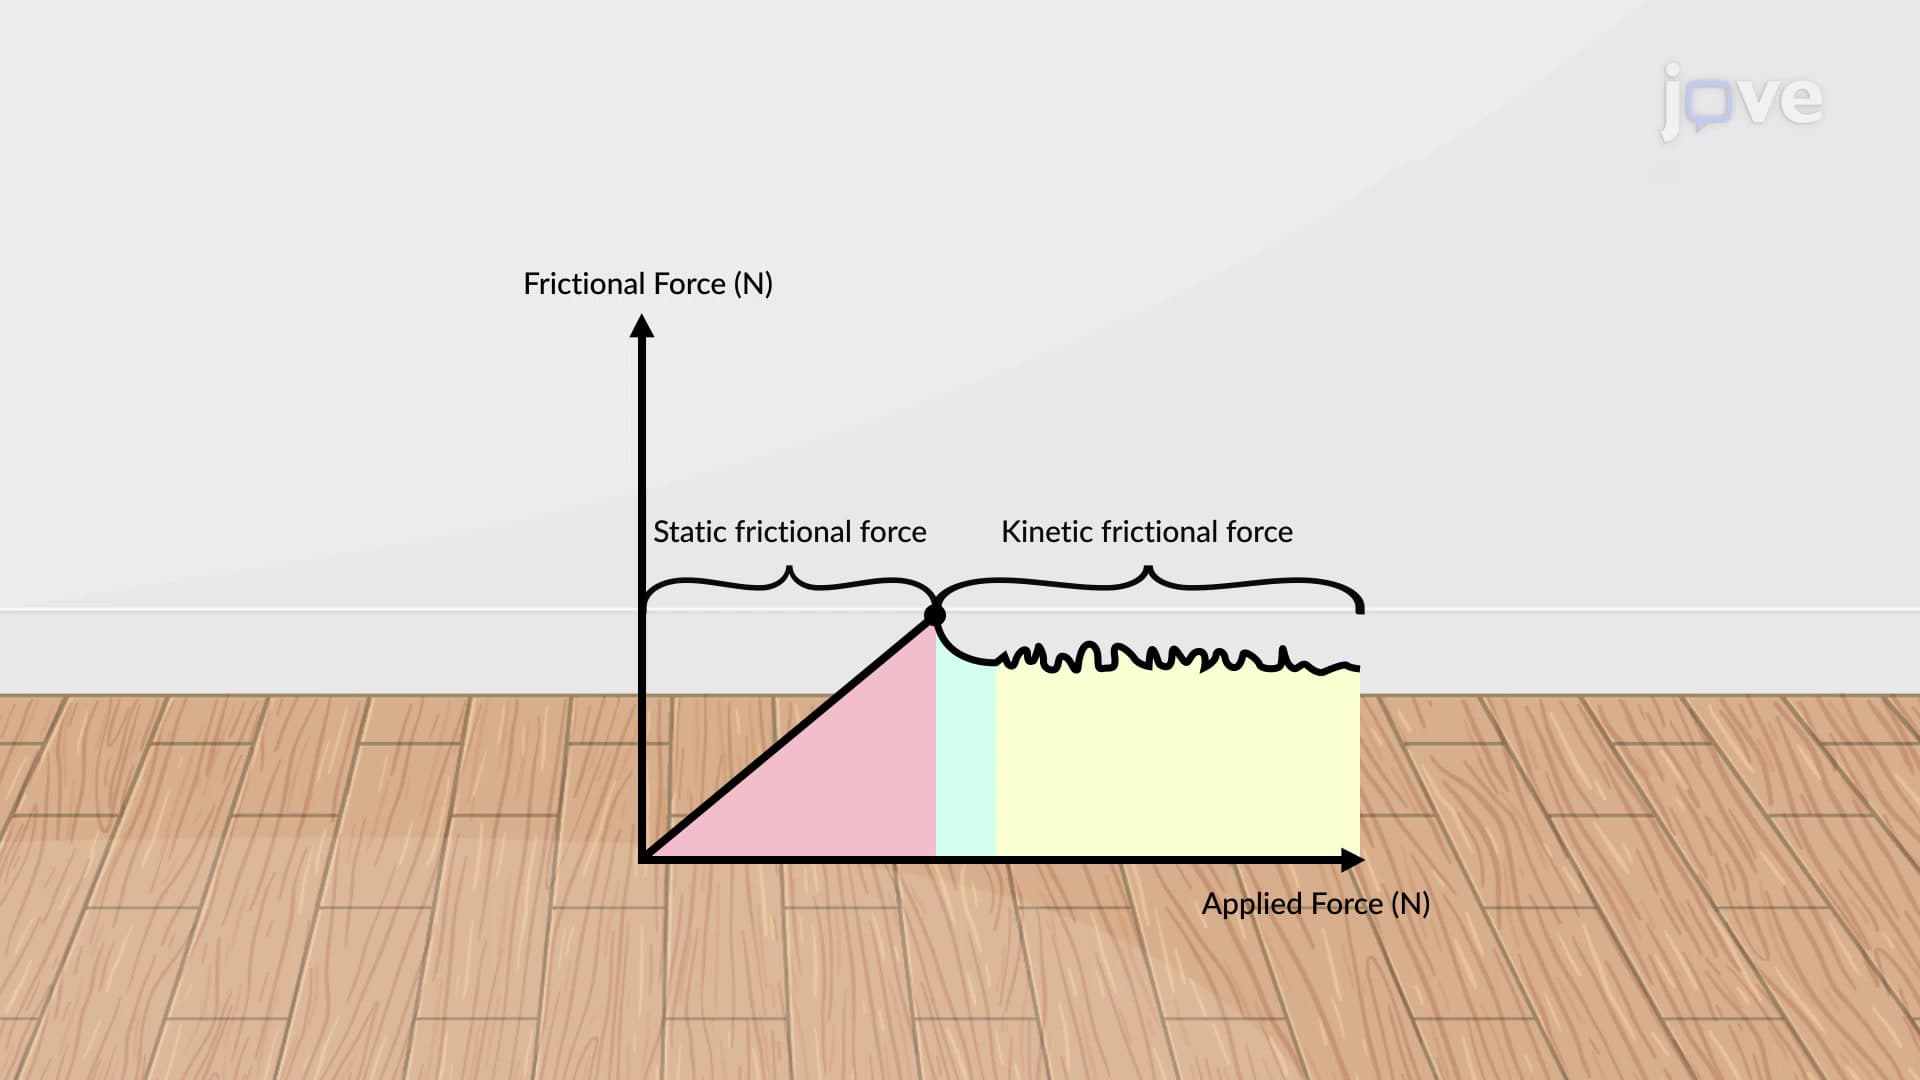
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:07
Frictional Force
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
Kinetic Friction