Enhanced pendulum appliance utilizing temporary anchorage device-based Nance arch and modified springs for optimized molar distalization control: a case report
Related Experiment Video
Updated: May 3, 2026
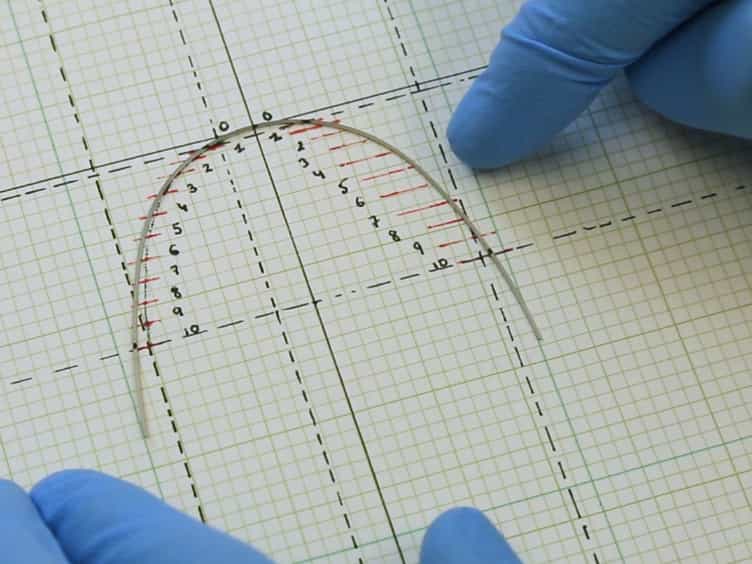
Force System with Vertical V-Bends: A 3D In Vitro Assessment of Elastic and Rigid Rectangular Archwires
Published on: July 24, 2018

Abstract:
A 20-year-old female patient with severe maxillary crowding and skeletal Class III malocclusion was successfully treated using an enhanced pendulum appliance. Camouflage treatment was chosen because the patient refused surgical intervention. Detailed examination and analysis revealed that labial inclination of the maxillary anterior teeth could provide the alignment space necessary after tooth extraction in the maxillary arch but it would not be beneficial esthetically and would increase the moment perpendicular to the tooth long axis as well as increase the risk of bone dehiscence. Therefore, lingual inclination of the mandibular anterior teeth was performed. To create space for aligning the maxillary arch, an enhanced pendulum appliance was utilized, in addition to premolar extraction. The enhanced pendulum appliance had one mesial and one distal helix on each spring, exerting opposing forces in the buccolingual direction and reducing the buccolingual inclination of the molars. In addition, miniscrews were integrated into the Nance arch of the enhanced pendulum appliance to provide skeletal anchorage, minimizing the reciprocal movement of anchorage teeth. This modification not only enhanced control over tooth movement but also improved treatment efficiency. During the entire treatment duration of 17 months, substantial improvement in facial and occlusal aspects were noted. Additionally, the patient retained these positive changes until the subsequent 2-year follow-up period.
Related Concept Videos
 01:10
Deformation in a Circular Shaft
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...