Related Experiment Video
Updated: Jun 14, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
RobotSDF: Implicit Morphology Modeling for the Robotic Arm
Yusheng Yang1,2, Jiajia Liu1,2, Hongpeng Zhou3
1School of Mechatronic Engineering and Automation, Shanghai University, Shanghai 200444, China.

Abstract:
The expression of robot arm morphology is a critical foundation for achieving effective motion planning and collision avoidance in robotic systems. Traditional geometry-based approaches usually suffer from the contradiction between the high demand for computing resources for fine expression and the insufficient detail expression caused by the pursuit of efficiency. The signed distance function addresses these drawbacks due to its ability to handle complex and arbitrary shapes and lower computational requirements. However, conventional robotic morphology methods based on the signed distance function often face challenges when the robot moves dynamically, since robots with different postures are modeled as independent individuals but the postures of robots are infinite. In this paper, we introduce RobotSDF, an implicit morphology modeling approach that can express the robot shape of arbitrary posture precisely. Instead of depicting a whole model of the robot arm, RobotSDF models the robot morphology as integrated implicit joint models driven by joint configurations. In this approach, the dynamic shape change process of the robot is converted into the coordinate transformations of query points within each joint's coordinate system. Experimental results with the Elfin robot demonstrate that RobotSDF can accurately depict robot shapes across different postures up to the millimeter level, which exhibits 38.65% and 66.24% improvement over the Neural-JSDF and configuration space distance field algorithms, respectively, in representing robot morphology. We further verified the efficiency of RobotSDF through collision avoidance in both simulation and actual human-robot collaboration experiments.
More Related Videos
 11:06
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
Related Concept Videos
 01:20
Plastic Deformation in Circular Shafts
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
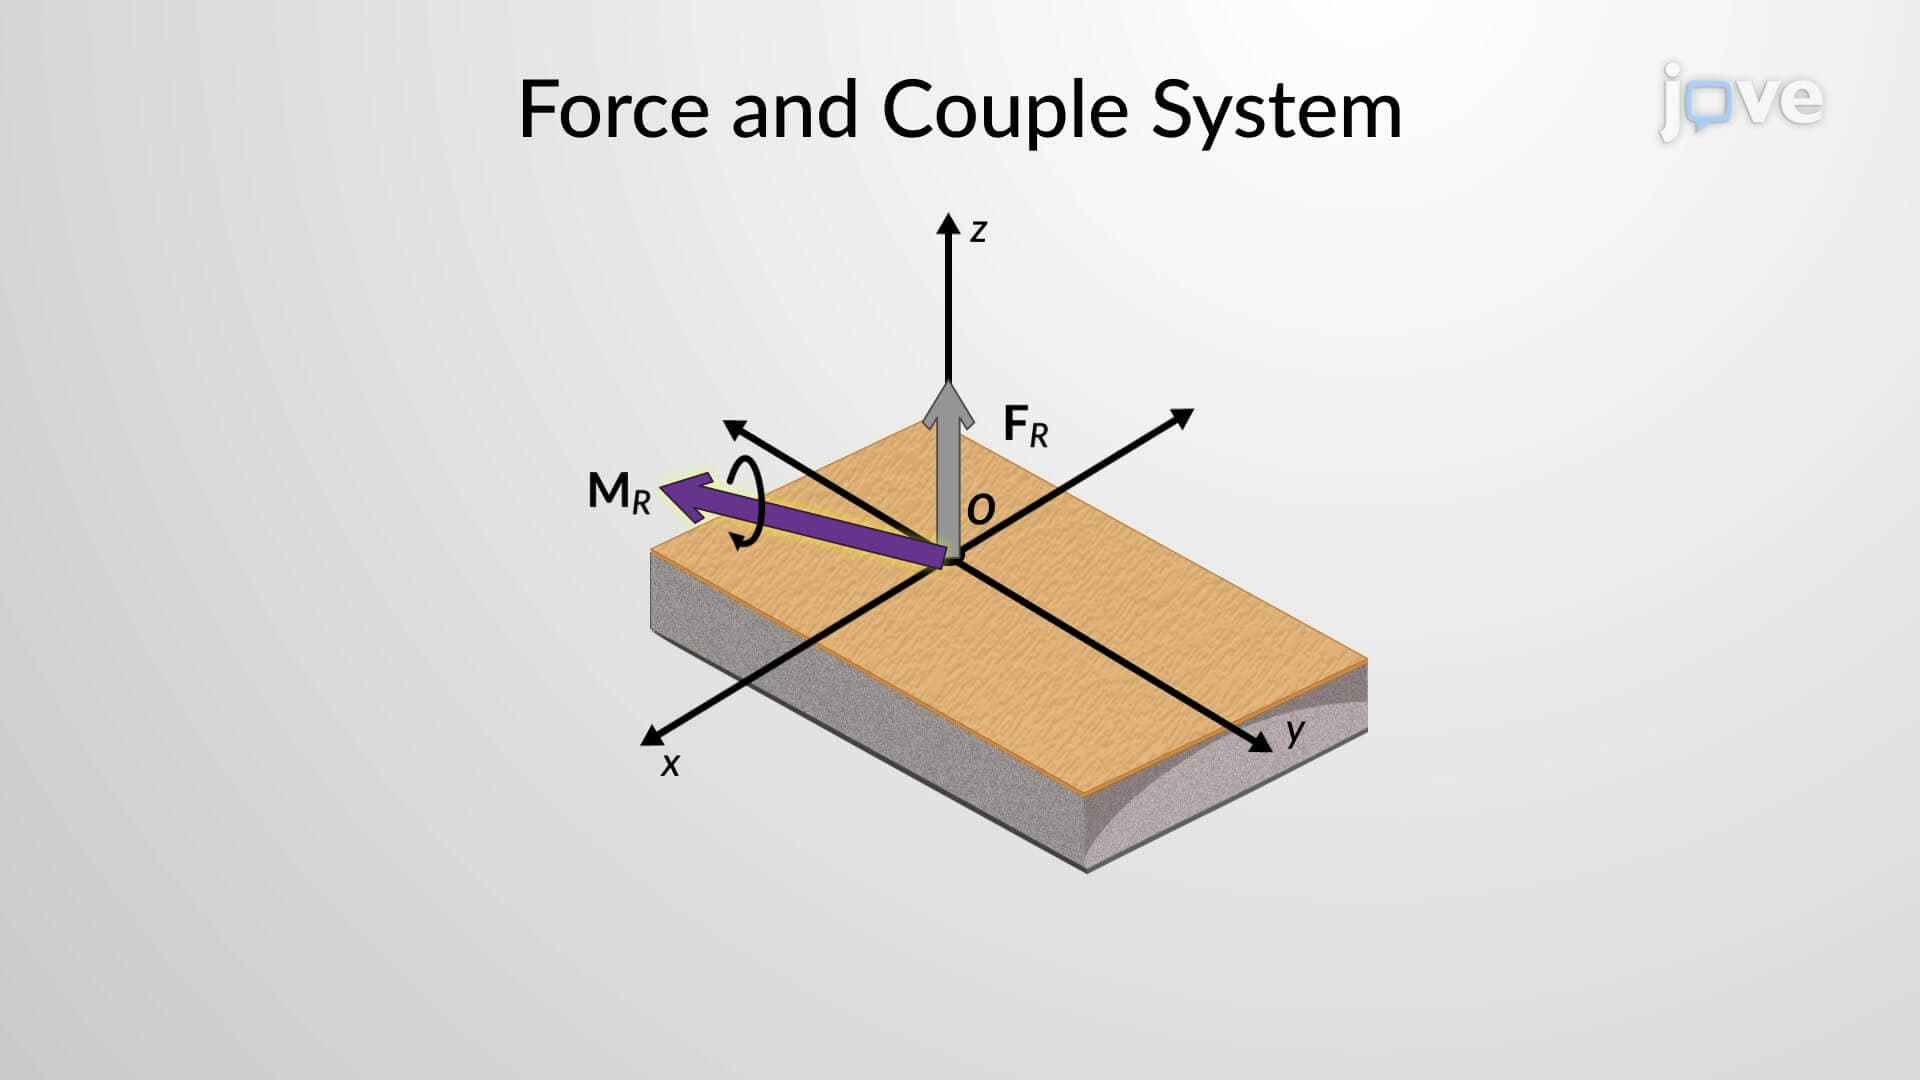
Simplification of a Force and Couple System: II
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...