View-Guided Cost Volume for Light Field Arbitrary-View Disparity Estimation
Related Experiment Video
Updated: Jun 14, 2025
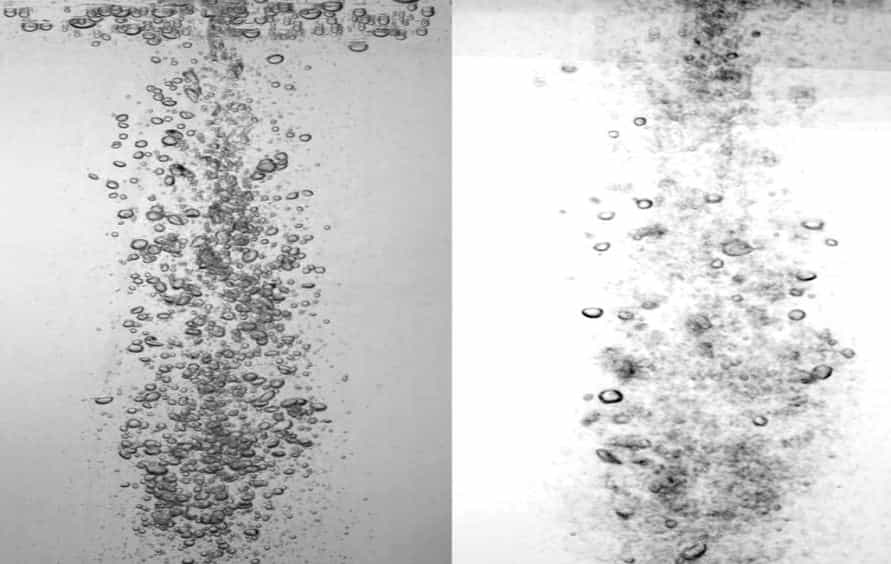
Determining 3D Flow Fields via Multi-camera Light Field Imaging
Published on: March 6, 2013

Abstract:
Per-view disparity estimation for light field (LF) is critical for various applications such as light field editing, but previous work mostly focuses on estimating disparity for the center view. In this paper, we propose a view-guided cost volume (VGCV), which successfully generates high-quality disparity maps for LF arbitrary view. Unlike previous methods that construct a static cost for center view only, VGCV is designed with view information and can be applicable to arbitrary-view estimation. In particular, since the key to achieving it is to condition cost on view, we extend previous static cost to a conditional one by introducing the spatial and angular information of target view into cost construction and aggregation, experiments show that this way can effectively adapt VGCV to arbitrary-view task. For construction, previous stereo-matching methods usually adopt correlation (e.g., variance) for dynamic estimation, but just using correlation can lose image structure information, which is essential for scene detail recovery, therefore we design an image-guided construction module and use cross-view attention to adapt cost for conditional construction while keeping its spatial information. Then for aggregation, we present a coordinate-guided aggregation module for VGCV regularization, which is specially designed to solve the problem of LF view deviation. Finally, we implement a Light Field Arbitrary-View Disparity Estimation Network (LFAVNet), then perform it on both synthetic and real LFs. Experiments demonstrate that LFAVNet can generate a higher-quality disparity map for arbitrary view in LF. We also extend our method to center-view estimation and light field editing tasks, which all achieve advanced performance.
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:15
Depth Perception and Spatial Vision
 01:05
Estimation of the Physical Quantities
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:12
Differential Leveling