Related Experiment Video
Updated: Jun 14, 2025
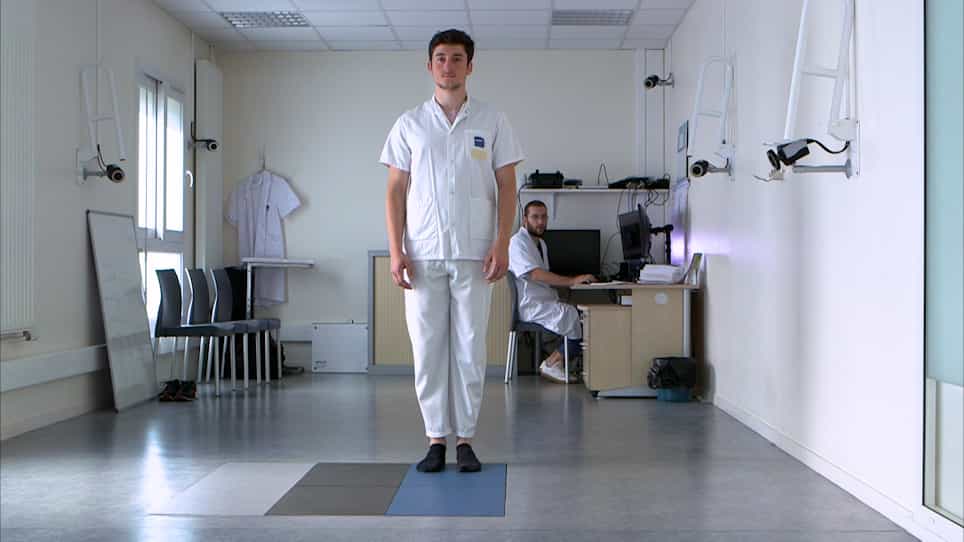
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
An approximate solution of the SLIP model under the regime of linear angular dynamics during stance and the stability
Alessandro Maria Selvitella1, Kathleen Lois Foster2
1Department of Mathematical Sciences, Purdue University Fort Wayne, 2101 E Coliseum Blvd, Fort Wayne, IN, 46805, United States of America; eScience Institute, University of Washington, 3910 15th Ave NE, Seattle, WA 98195, United States of America; NSF-Simons Center for Quantitative Biology, Northwestern University, 2200 Campus Drive, Evanston, IL 60208, United States of America.

Abstract:
Terrestrial locomotion is a complex phenomenon that is often linked to the survival of an individual and of an animal species. Mathematical models seek to express in quantitative terms how animals move, but this is challenging because the ways in which the nervous and musculoskeletal systems interact to produce body movement is not completely understood. Models with many variables tend to lack biological interpretability and describe the motion of an animal with too many independent degrees of freedom. Instead, reductionist models aim to describe the essential features of a gait with the smallest number of variables, often concentrating on the center of mass dynamics. In particular, spring-mass models have been successful in extracting and describing important characteristics of running. In this paper, we consider the spring loaded inverted pendulum model under the regime of constant angular velocity, small compression, and small angle swept during stance. We provide conditions for the asymptotic stability of periodic trajectories for the full range of parameters. The hypothesis of linear angular dynamics during stance is successfully tested on publicly available human data of individuals running on a treadmill at different velocities. Our analysis highlights a novel bifurcation phenomenon for varying Froude number: there are periodic trajectories of the spring loaded inverted pendulum model that are stable only in a restricted range of Froude numbers, while they become unstable for smaller or larger Froude numbers.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:10
Relative Motion Analysis - Acceleration
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...