Related Experiment Video
Updated: Jun 12, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Minimum-Cost State-Flipped Control for Reachability of Boolean Control Networks Using Reinforcement Learning

Abstract:
This article proposes model-free reinforcement learning methods for minimum-cost state-flipped control in Boolean control networks (BCNs). We tackle two questions: 1) finding the flipping kernel, namely, the flip set with the smallest cardinality ensuring reachability and 2) deriving optimal policies to minimize the number of flipping actions for reachability based on the obtained flipping kernel. For Question 1), Q-learning's capability in determining reachability is demonstrated. To expedite convergence, we incorporate two improvements: 1) demonstrating that previously reachable states remain reachable after adding elements to the flip set, followed by employing transfer learning and 2) initiating each episode with special initial states whose reachability to the target state set are currently unknown. For Question 2), it is challenging to encapsulate the objective of simultaneously reducing control costs and satisfying terminal constraints exclusively through the reward function employed in the Q-learning framework. To bridge the gap, we propose a BCN-characteristics-based reward scheme and prove its optimality. Questions 1) and 2) with large-scale BCNs are addressed by employing small memory Q-learning, which reduces memory usage by only recording visited action-values. An upper bound on memory usage is provided to assess the algorithm's feasibility. To expedite convergence for Question 2) in large-scale BCNs, we introduce adaptive variable rewards based on the known maximum steps needed to reach the target state set without cycles. Finally, the effectiveness of the proposed methods is validated on both small- and large-scale BCNs.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:21
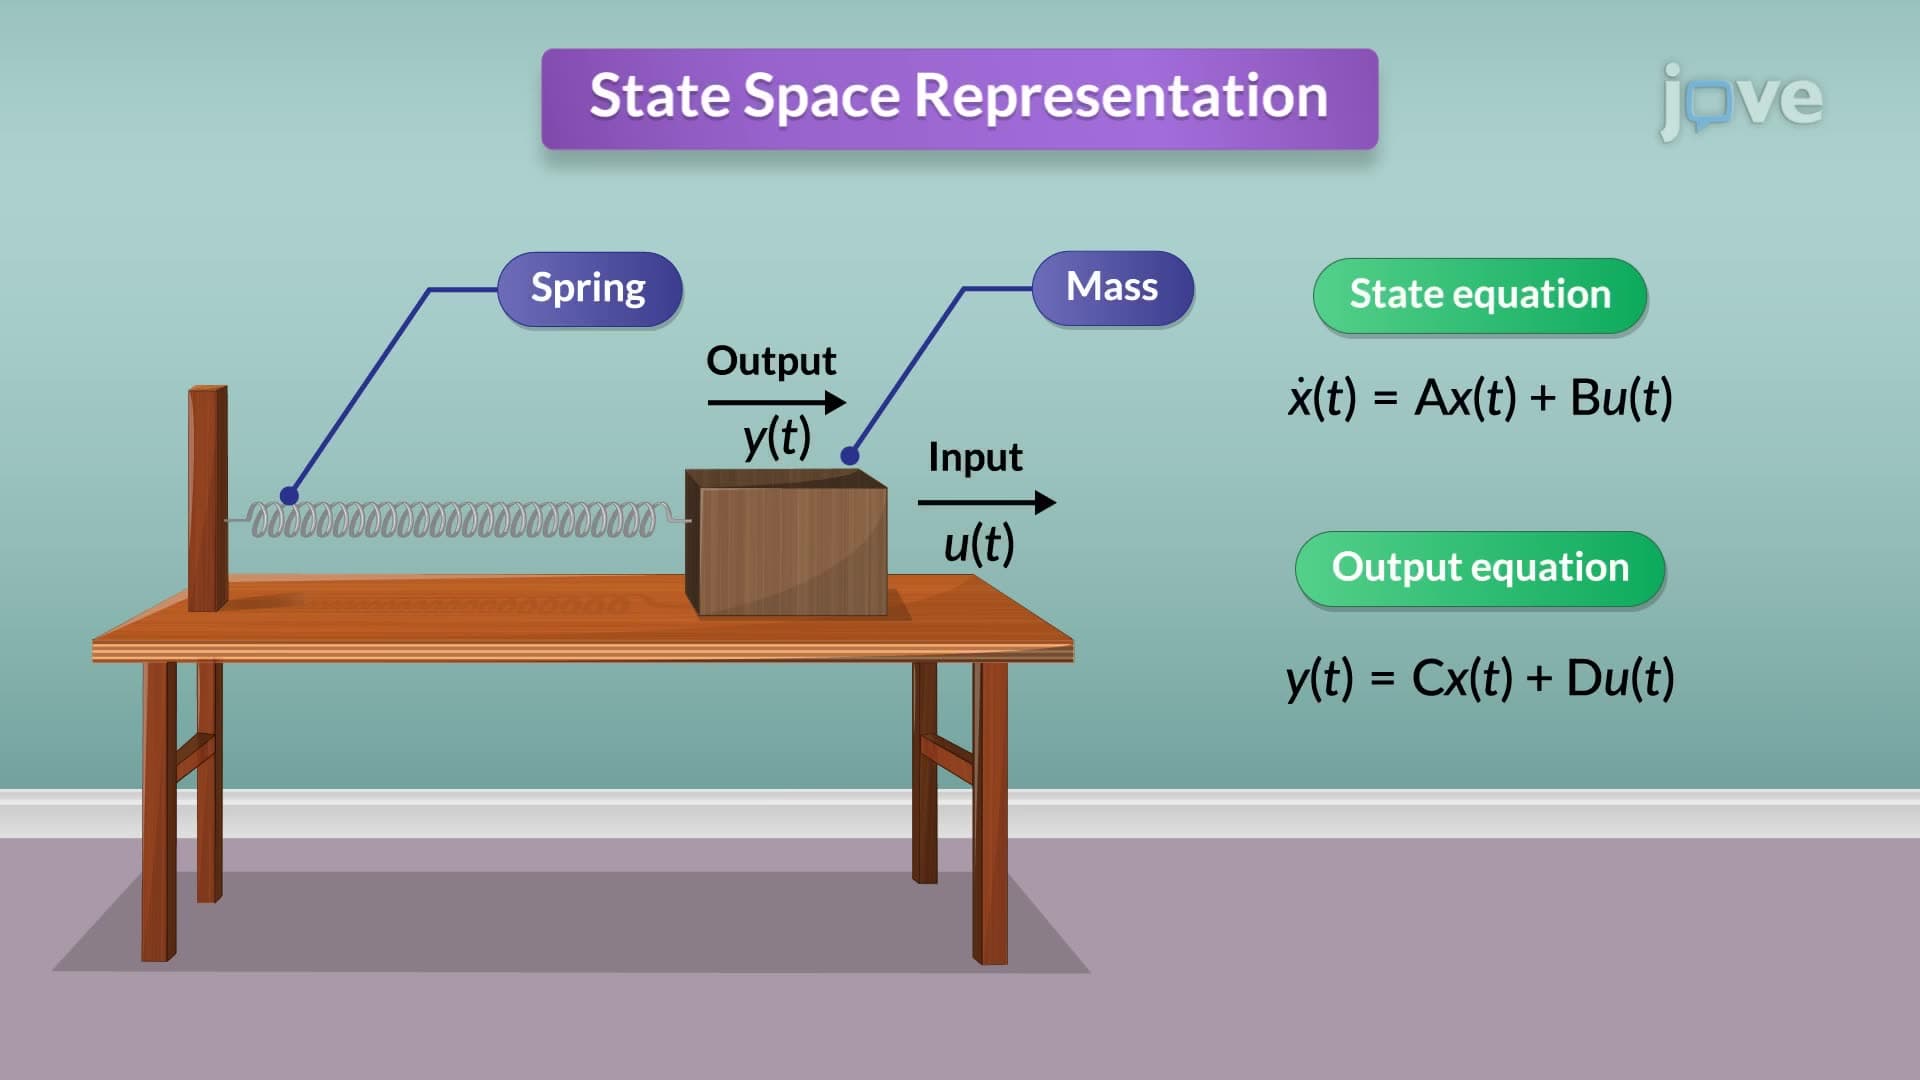
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
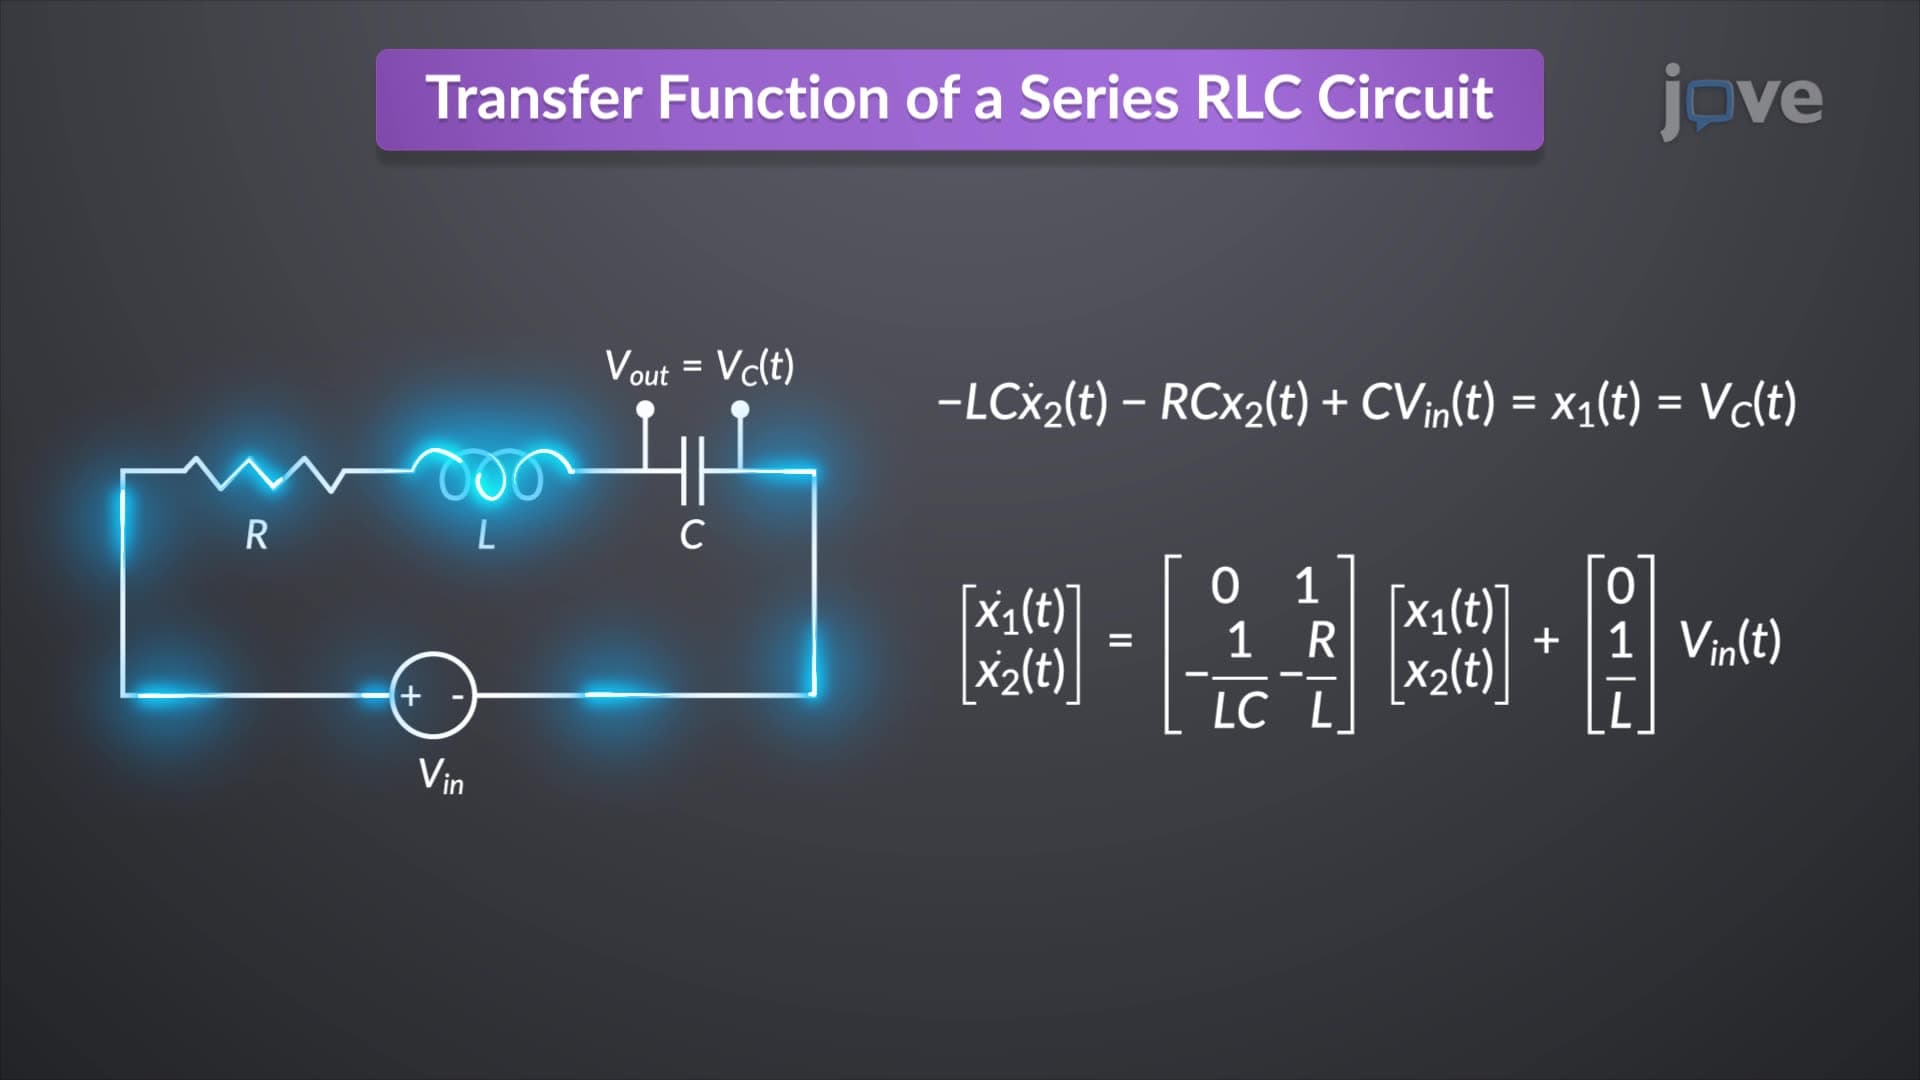
Transfer Function to State Space
In an...
 01:22
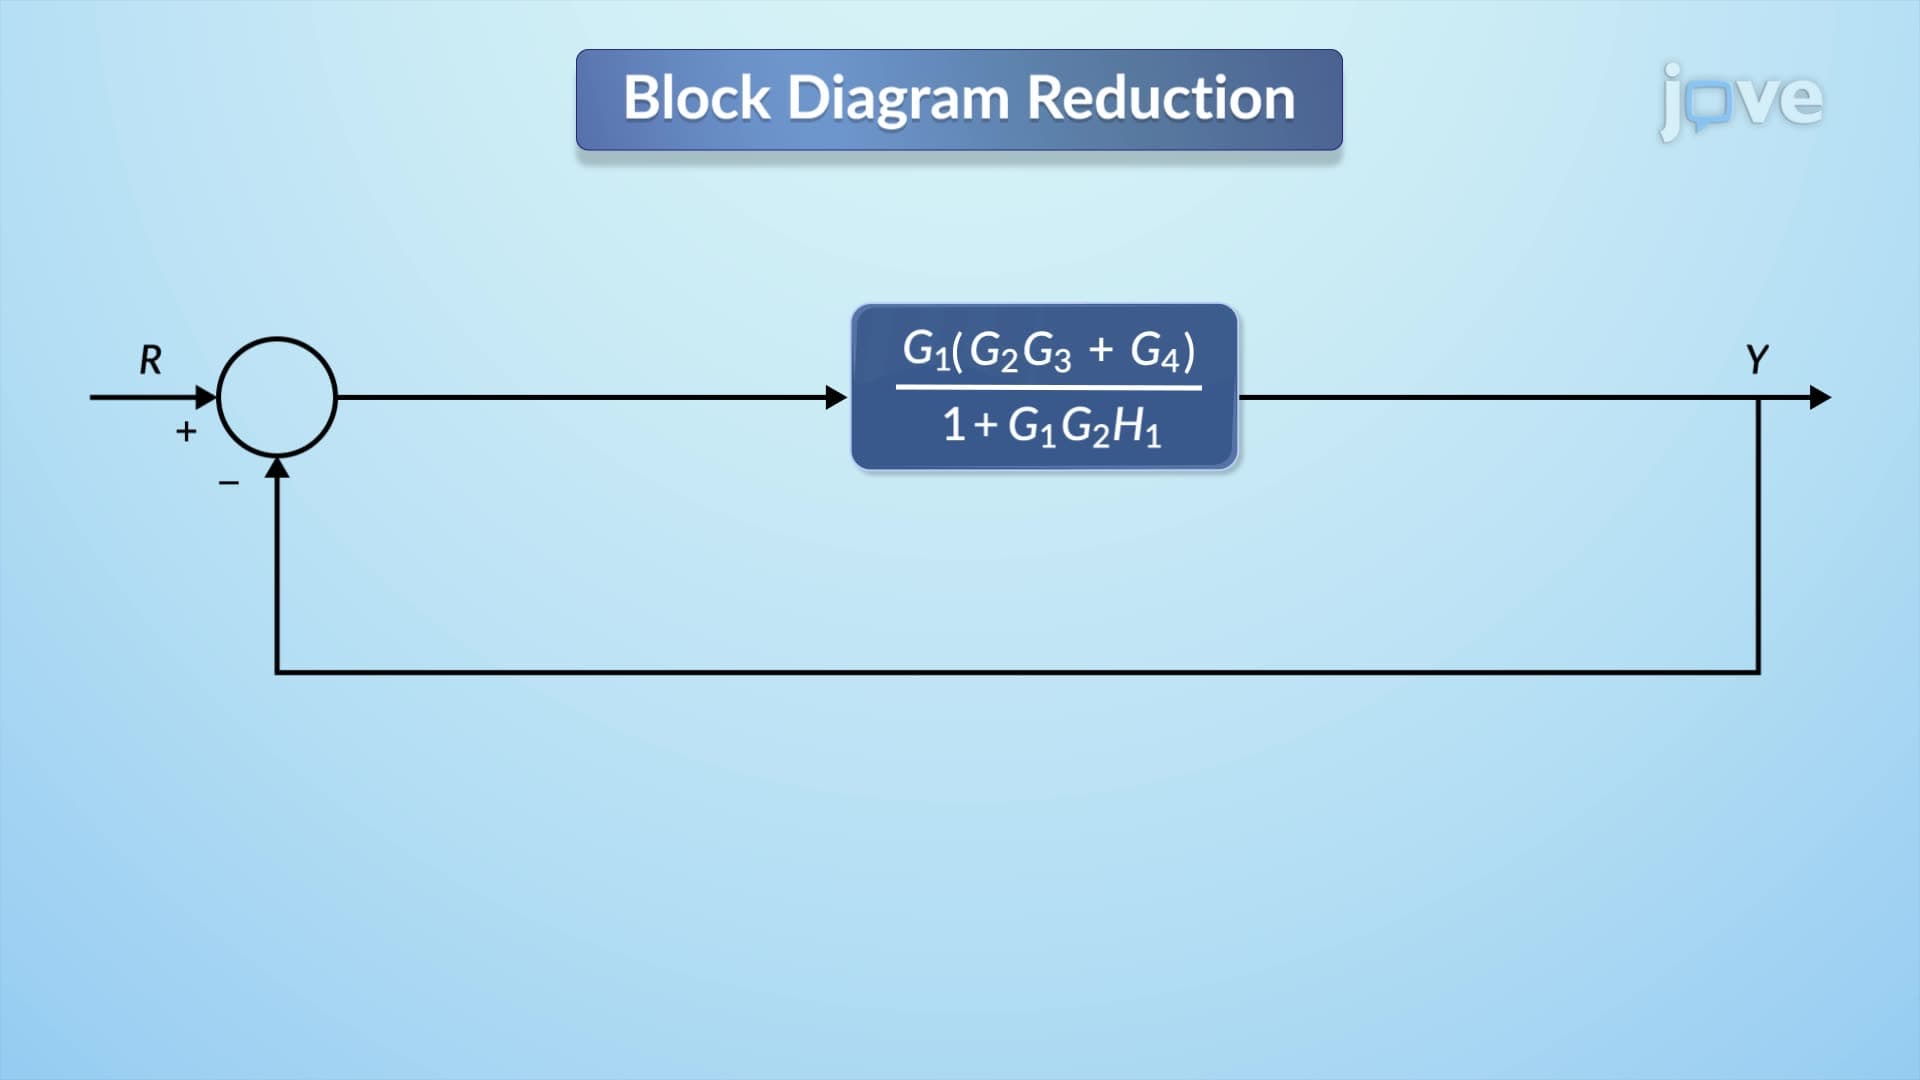
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
 01:27
State Space Representation
Consider an RLC circuit, a...