Related Experiment Video
Updated: Jun 12, 2025
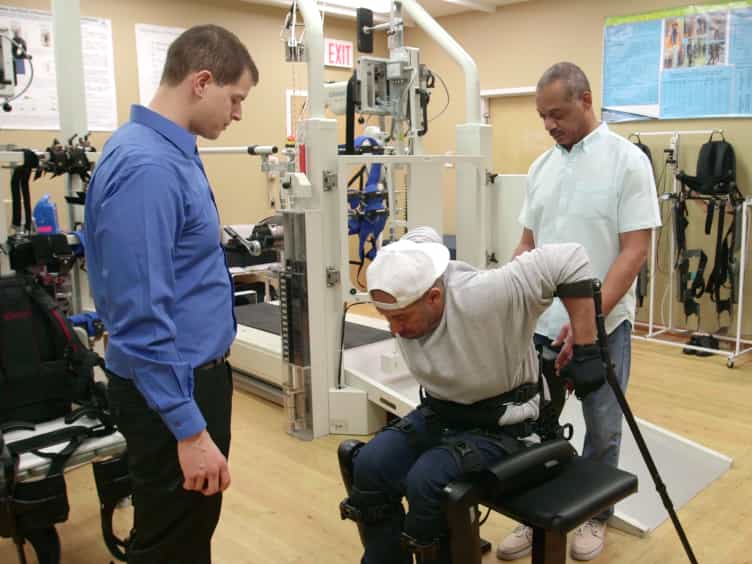
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Parallel Elastic Self-Alignment Mechanism Enhances Energy Efficiency and Reduces Misalignment in a Powered Knee

Objective:
This paper aims to enhance exoskeleton compliance during locomotion assistance by reducing misalignment and to improve energy efficiency by overcoming the limitations posed by the bulky structure of powered rigid exoskeletons.
Methods:
A novel compliant knee exoskeleton, featuring a parallel elastic self-alignment mechanism, has been developed and structurally optimized. The exoskeleton uses adaptive oscillators to determine the wearer's gait phase and provides real-time assistance to the knee joint.
Results:
Bench tests demonstrate that the parallel elastic mechanism significantly reduces the driving torque of the knee exoskeleton. Performance evaluations reveal that, compared to a commercial orthosis, the root-mean-square of knee angle error, joint misalignment, and unexpected interaction forces are reduced by 16.5 11.3%, 23.3 4.9%, and 17.7 1.3%, respectively. Gait intervention experiments show reductions in average and maximum muscle activity of the knee joint by 7.6 4.9% and 23.2 5.7%, respectively. Additionally, the exoskeleton decreases negative work performed by the knee joint and the total lower limb by 22.7% and 8.6%, respectively.
Conclusion:
The parallel elastic self-alignment mechanism effectively mitigates joint misalignment, while the parallel springs offer partial gravity compensation, thereby enhancing both the energy efficiency and locomotion assistance of the exoskeleton.
Significance:
The parallel elastic self-alignment mechanism effectively addresses both misalignment and energy efficiency challenges in powered exoskeletons, providing valuable insights for future design improvements.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 07:30
The Muscle Cuff Regenerative Peripheral Nerve Interface for the Amplification of Intact Peripheral Nerve Signals
Published on: January 13, 2022
Related Concept Videos
 01:14
Stability of structures
 00:57
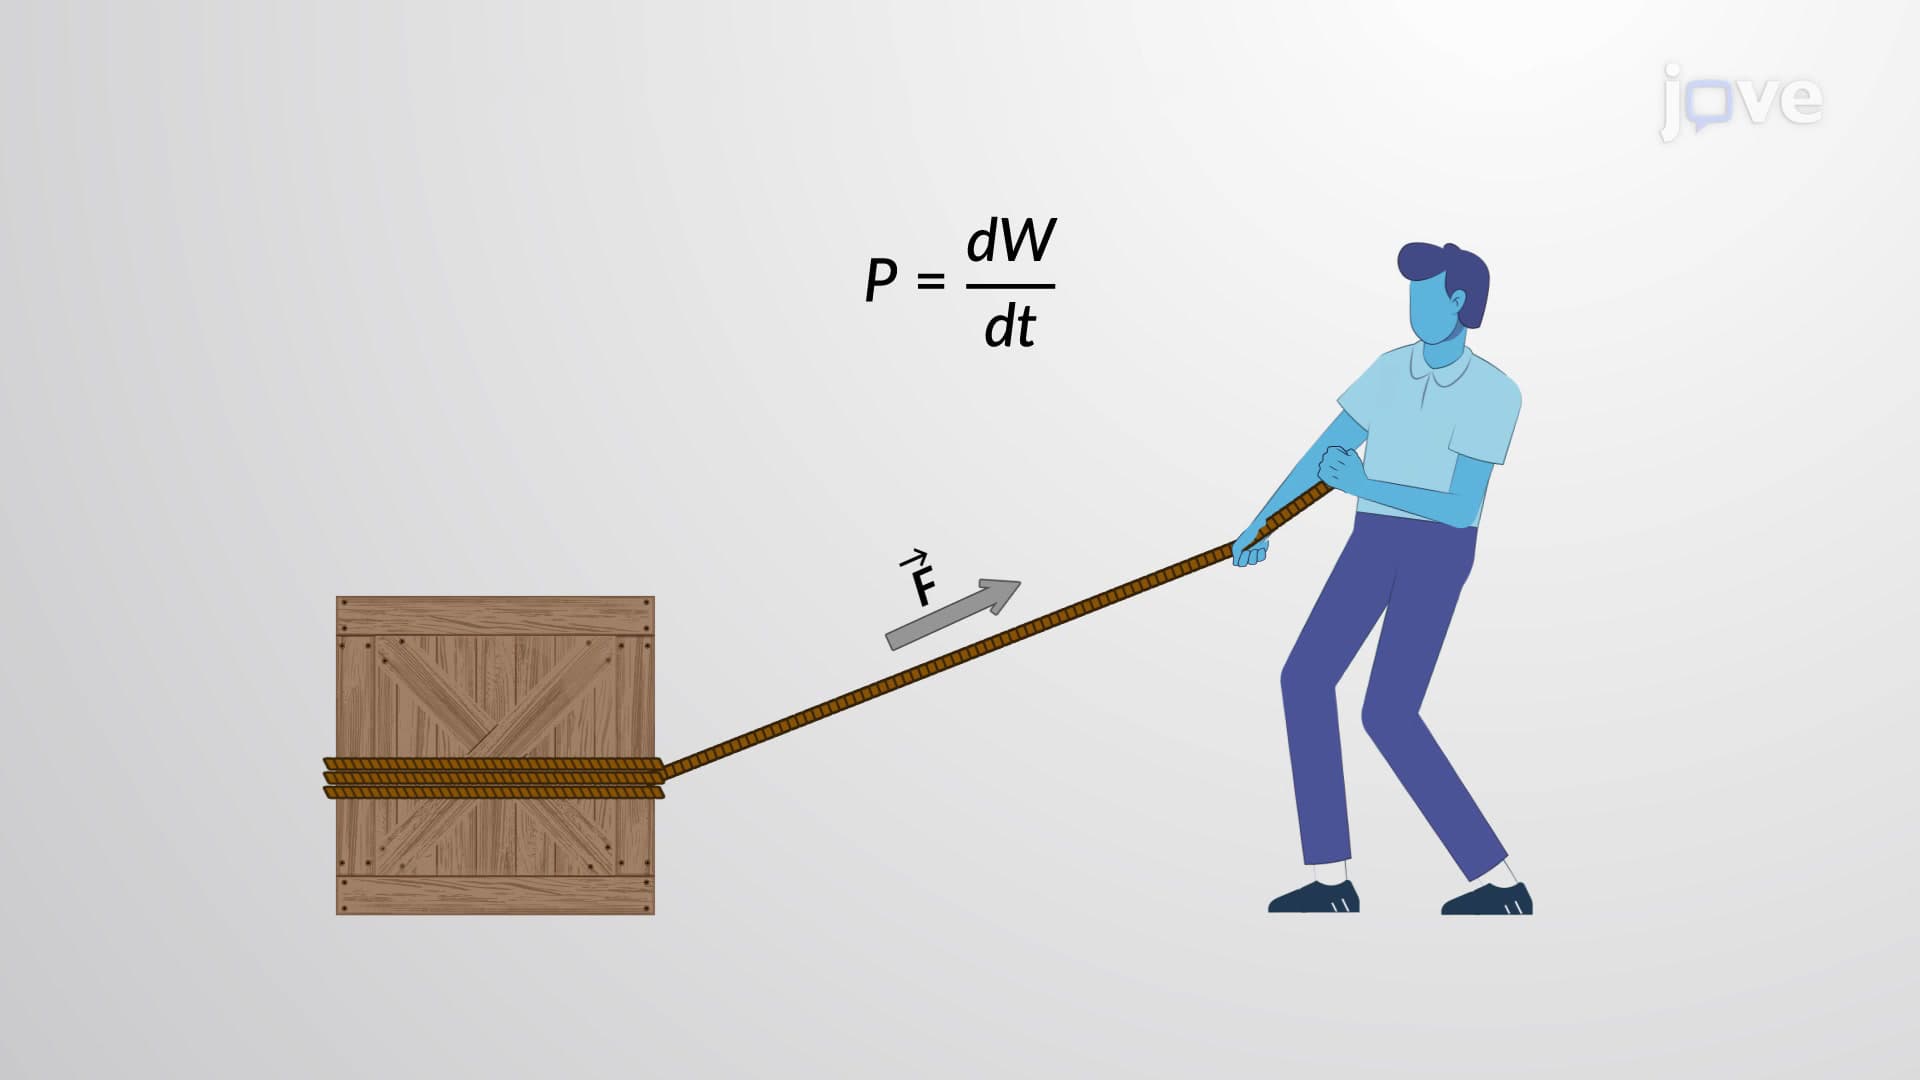
Power Expended by a Constant Force
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...