Robust Prescribed Performance Control of Nonlinear Systems With Unknown Odd Powers


Abstract:
This article is concerned with the problem of reference tracking for the lower-triangular nonlinear systems with a chain of odd powers. Contrary to most of the related studies, this work is focused on the case where neither the odd powers nor their bounds are known. This renders the majority of the existing methods for stability analysis and control design for the odd-power systems infeasible. To surmount this challenge, a robust prescribed performance control strategy together with a constraint analysis by contradiction is put forward. Instead of the well-established adding one power integrator technique, a group of barrier functions are employed to combat the tracking error and the intermediate errors. In lieu of the Lyapunov stability theory, a constraint analysis by contradiction is carried out, which discloses the inherent robustness of the control system against the nonparametric uncertainties, the unmatched disturbances and the unknown odd powers. It is guaranteed that the tracking error enters into a preassigned neighborhood of zero after a given time, with a predefined bound on the overshoot. In addition, the proposed control exhibits a striking simplicity. Despite the severe model uncertainties and the recursive control design, no effort needs to be paid for parameter identification, function approximation, disturbance estimation, or derivative calculation. The above theoretical findings are substantiated by the comparative simulation results.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:17
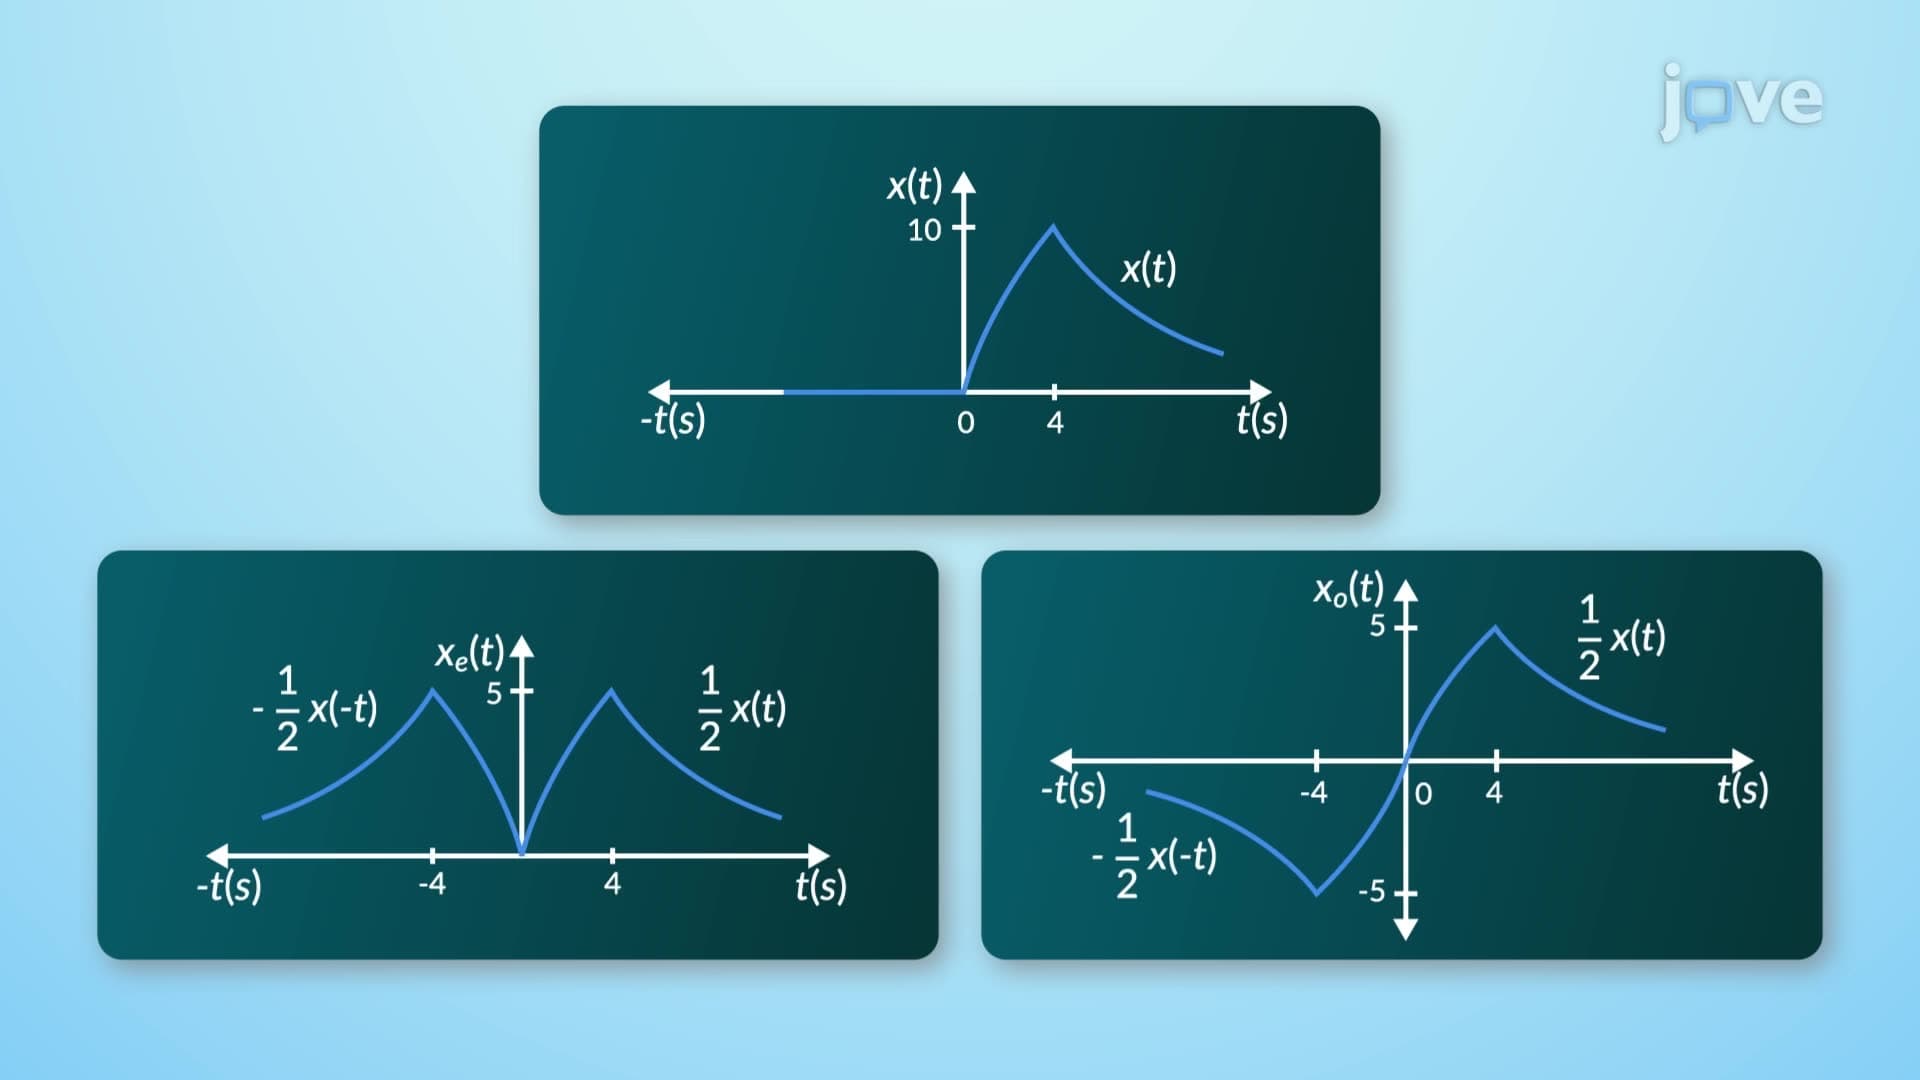
Even and Odd Signals
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...