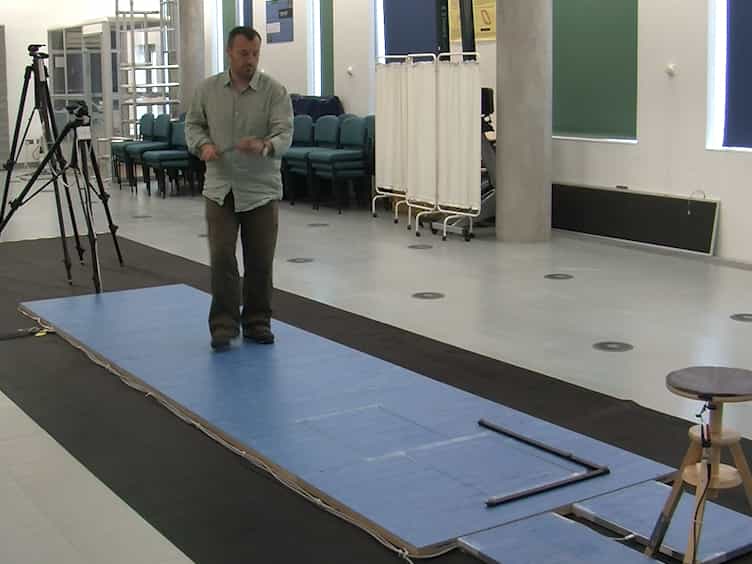
Related Experiment Video
Updated: Jun 11, 2025
Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
Strategies for unplanned gait termination at comfortable and fast walking speeds in children with cerebral palsy
Minoru Kimoto1, Kyoji Okada2, Kazutaka Mitobe3
1Department of Physical Therapy, Akita University Graduate School of Health Sciences, Akita, Japan; Department of Medicine, Akita Prefectural Center on Development and Disability, Akita, Japan.

Insights
Children with cerebral palsy (CP) exhibit distinct gait termination strategies compared to typically developing (TD) peers, particularly at faster speeds. Understanding these differences in braking forces and balance is crucial for developing effective collision avoidance interventions.
Area of Science:
- Biomechanics
- Neuroscience
- Pediatrics
Background:
- Safe walking requires effective collision avoidance, with increased speed raising risk.
- Gait termination strategies in children with cerebral palsy (CP) at varying speeds are not well understood.
- Faster walking speeds necessitate rapid adjustments to prevent collisions.
Purpose of the Study:
- To analyze and compare gait termination strategies in children with CP versus typically developing (TD) children at comfortable and faster walking speeds.
- To investigate the effects of increased walking speed on spatial, force, and temporal gait parameters in both groups.
- To identify kinematic and kinetic differences during gait termination between children with CP and TD children.
Main Methods:
- 10 children with CP and 10 TD children participated.
- Participants walked at 100% (WS1) and 125% (WS2) of their comfortable speed.
- Spatial, force, and temporal gait parameters were assessed during a gait termination task.
Main Results:
- TD children showed stronger initial braking forces, while CP children applied more force after the second step (anterior-posterior direction).
- Increased walking speed led to greater center of mass (COM)-center of pressure (COP) divergence in the AP direction for the CP group.
- Mediolateral (ML) COM-COP divergence decreased at faster speeds in the CP group.
- Kinetic characteristics in the CP group were significantly influenced by the increase in walking speed.
Conclusions:
- Children with CP demonstrate unique gait termination adaptations, including distinct braking force patterns and altered COM-COP dynamics.
- These findings highlight the need for tailored gait interventions for children with CP.
- Interventions should focus on dynamic balancing strategies and address the specific forces involved in collision avoidance for this population.
Abstract:
Collision avoidance while walking is necessary for safe living, and faster walking speeds tend to increase collision risk. However, gait termination strategies for patients with cerebral palsy (CP), from comfortable to faster speed, remain unexplored. This study aimed to analyze these strategies in children with CP compared to typically developing (TD) children at two different speeds. Study participants included 10 children with CP (mean age, 12.5; five females; mean height, 147.8 cm; mean weight, 41.7 kg) and 10 TD children (mean age, 11.4; nine females; mean height, 142.0 cm; mean weight, 38.1 kg). Effects of walking speed on spatial, force, and temporal parameters were assessed at 100 % (WS1) and 125 % (WS2) speeds of comfortable walking. The TD group exerted a more pronounced braking force at the first step after the stop line appeared on the floor until the contralateral step at both WS1 (P = 0.006) and WS2 (P = 0.019); however, the CP group exerted a more potent force after the second step (WS1: P = 0.026, WS2: P = 0.023) in the anterior-posterior (AP) direction. Additionally, an increase in the center of mass (COM)-center of pressure (COP) divergence in the AP direction (P = 0.032), which decreased in the mediolateral (ML) direction (P = 0.036) at faster walking speeds, influenced the kinetic characteristics of the CP group from WS1 to WS2. The complex adaptations, such as unique braking forces and changes in the COM-COP divergence, suggest that gait interventions should consider the distinctive forces and adopt dynamic balancing strategies to avoid collisions during walking.