Related Experiment Video
Updated: Jun 10, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Quantifying perceived risk in driving: A Monte Carlo approach for obstacle avoidance
Zhen Yang1, Zhe Gong1, Yimei Qin1
1The Key Laboratory of Road and Traffic Engineering, Ministry of Education, Tongji University, Shanghai, China.

Objective:
This study aims to develop a model for quantifying perceived risk in obstacle avoidance, emphasizing how drivers' perceived risk characteristics influence their driving decisions. The research addresses the lack of attention given to modeling risk from the perspective of drivers' risk perceptions.
Methods:
Monte Carlo methods are employed to account for the uncertainties and complexities of driving behavior, restoring the probabilistic nature of risk. The proposed method quantifies perceived risk by incorporating drivers' fuzzy perceptions, enabling a quantitative evaluation during obstacle avoidance. A logit model is used to link perceived risk with driving decisions, identifying key factors influencing driver behavior in obstacle avoidance scenarios.
Results:
Experimental data revealed significant variations in vehicle trajectories and speed distributions due to differences in drivers' experience and proficiency. The perceived risk indicator (PRI) values for leftward bypasses were higher compared to rightward bypasses, and the receiver operating characteristic (ROC) curve confirmed the PRI's strong predictive ability with an area under the curve (AUC) of 0.820. The logit model showed that both PRI and speed significantly influenced the probability of choosing a rightward bypass, achieving 90% accuracy. Building on the model, the study predicted and visualized the probability of vehicles turning right to avoid obstacles at different positions and speeds within 200 m of the obstacle.
Conclusions:
The research offers a framework for traffic professionals to understand driver-perceived risk and decision-making mechanisms. This understanding is beneficial for improving traffic safety and highlights the importance of considering drivers' risk perceptions in modeling driving behavior.
More Related Videos
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:09
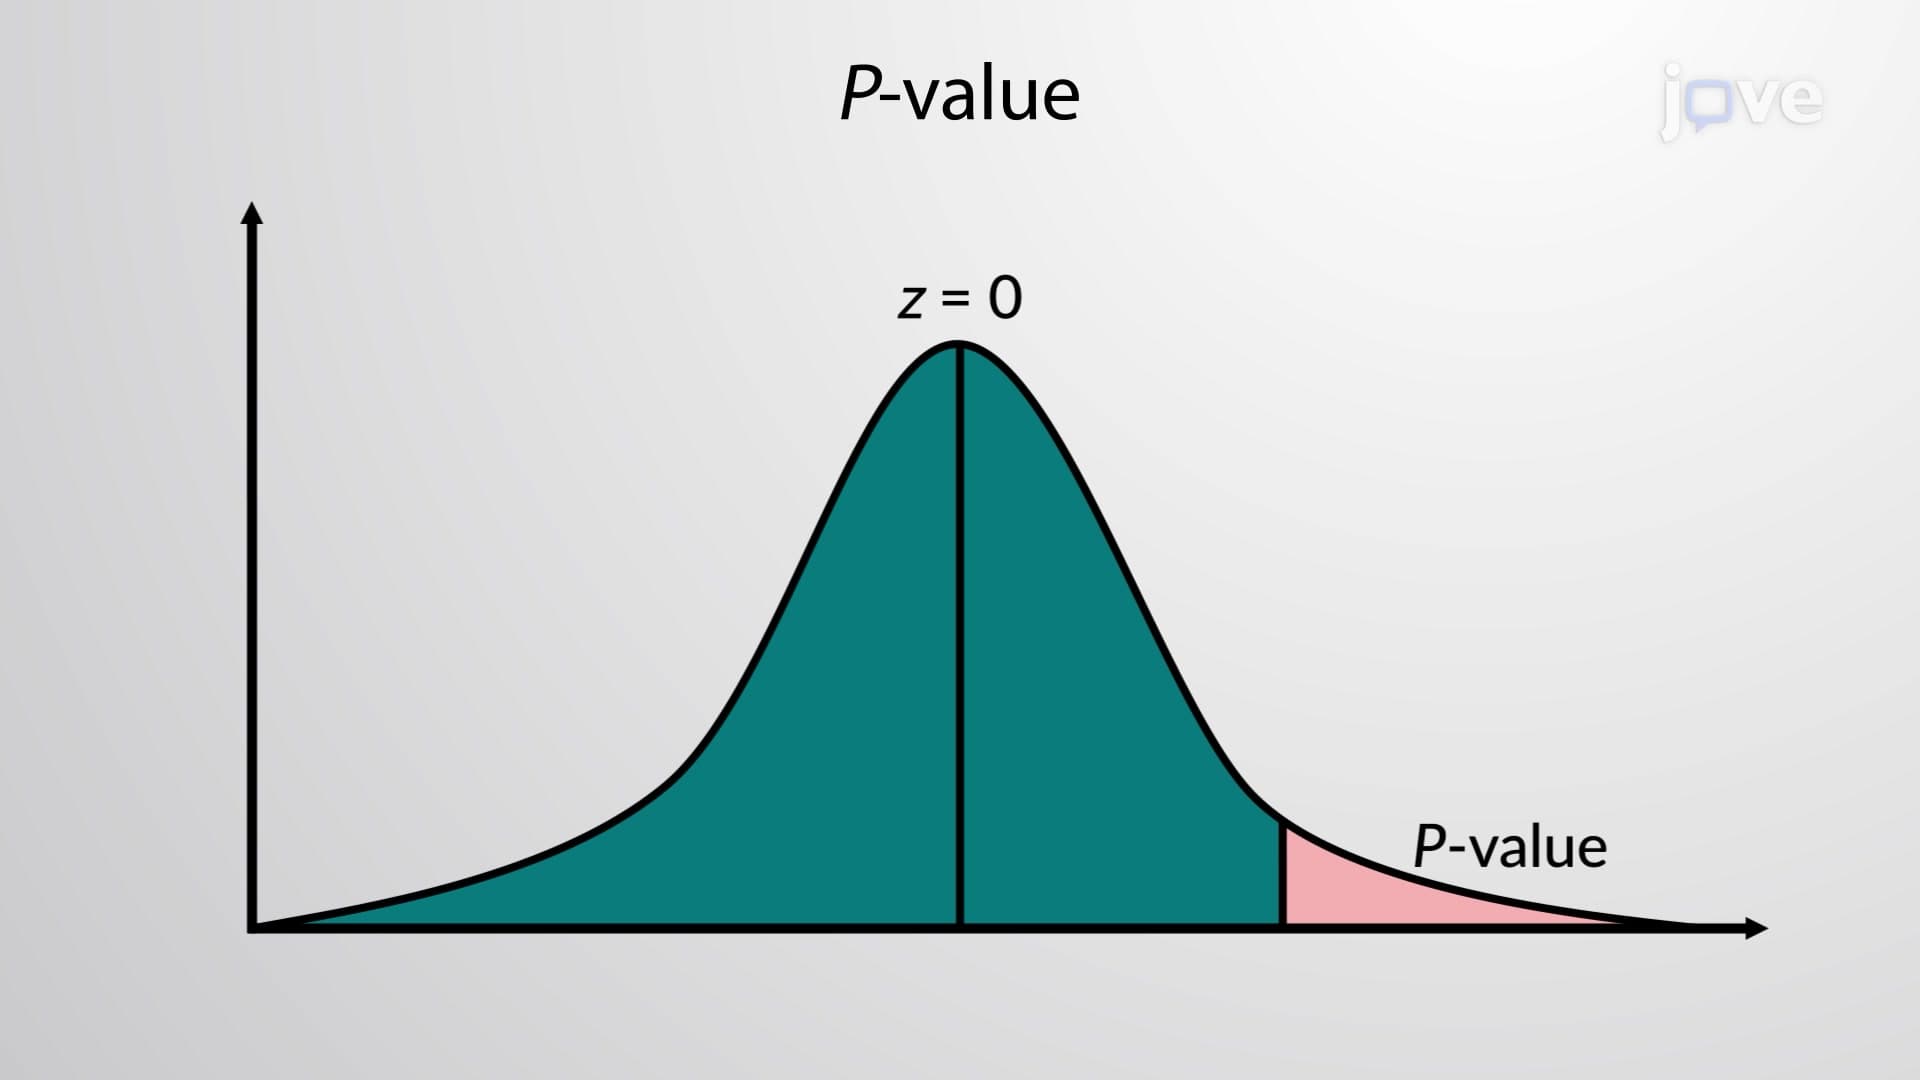
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:16
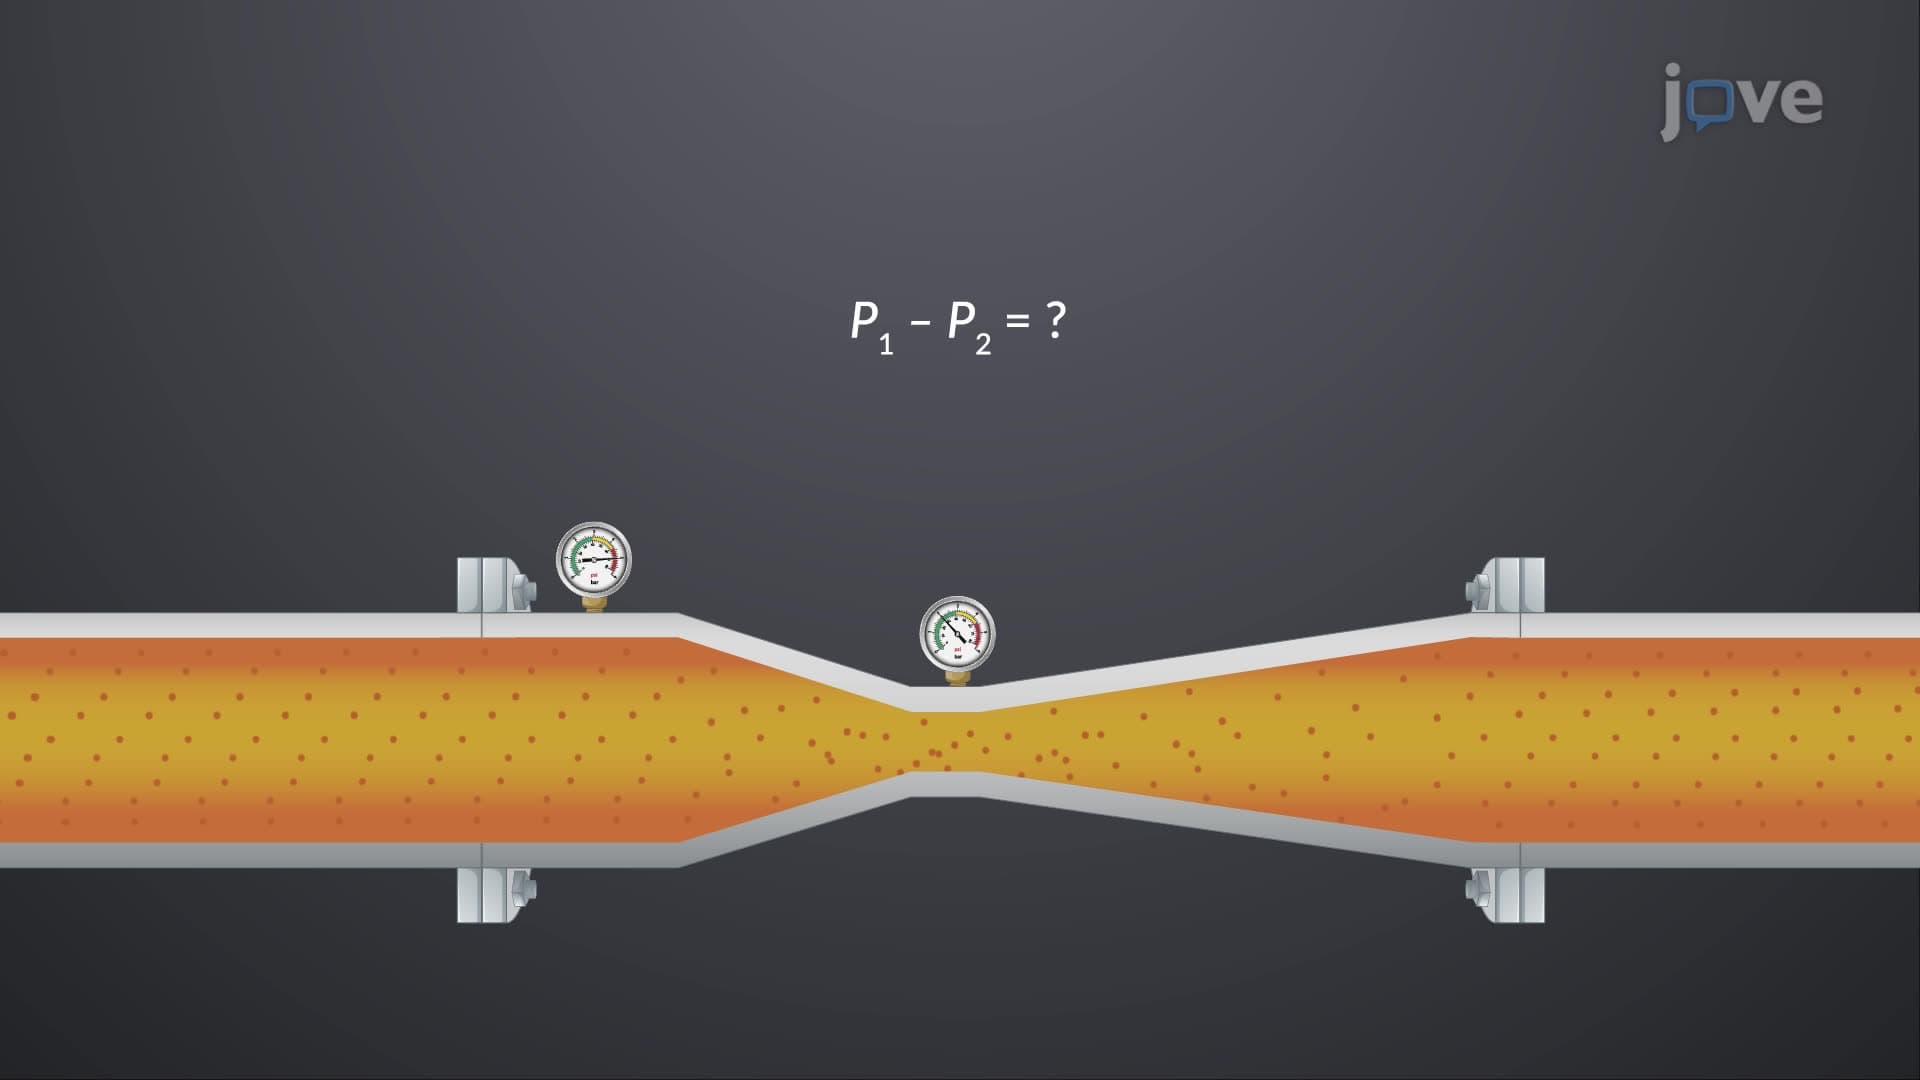
Bernoulli's Equation: Problem Solving
The first step is to compute the cross-sectional areas of the pipe and the Venturi throat to analyze the pressure difference indicated by the pressure gauge. Next, the continuity...
 01:23
Types of Biopharmaceutical Studies: Controlled and Non-Controlled Approaches
Non-controlled studies, commonly employed for initial exploration, lack a control group, rendering them susceptible to biases and external influences. In contrast,...
 01:25
The Anchoring-and-Adjustment Heuristic