Related Experiment Video
Updated: Apr 12, 2026
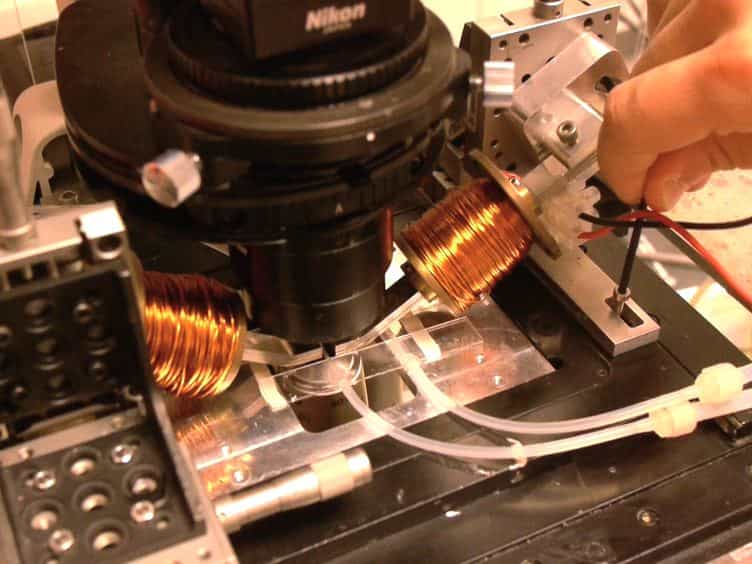

Remote Magnetic Actuation of Micrometric Probes for in situ 3D Mapping of Bacterial Biofilm Physical Properties
Published on: May 2, 2014
Magnetic Microrobots as a Platform for Cell Clean Up
Fatma Ceren Kirmizitas1,2, David Rivas1, Sudipta Mallick1
1Department of Mechanical Engineering, University of Delaware, Newark, DE 19716.

Abstract:
Mobile magnetic microrobots have been extensively used in a wide range of biomedical applications due to their numerous advantages. Magnetic microrobots in particular have been developed and shown great potential over the past two decades for the manipulation and migration of both single cells and cell aggregates. The efficient clearance of cell aggregates is crucial to prevent uncontrolled cell proliferation, tissue damage, and invasive surgeries, especially for those related to the vascular system. In this work, we showed cellular manipulation and mobility to achieve cellular clean up on Human Liver Cancer (HepG2) cells by using two types of untethered magnetic microrobots that are different in type and size. We performed the cellular clean up in the microchannel, which can demonstrate the closed working environment, and also on a glass slide to present an air-liquid interface. We showed that the microrobots could be able to move a cluster of cells in both conditions which could make them useful for sorting and separation applications. Furthermore, cell viability was assessed by using a trypan blue staining assay on HepG2 cells right after and 24 hours after microrobot actuation.
More Related Videos
 10:27
Microfluidic Buffer Exchange for Interference-free Micro/Nanoparticle Cell Engineering
Published on: July 10, 2016
 09:58
Computer Numerical Control Micromilling of a Microfluidic Acrylic Device with a Staggered Restriction for Magnetic Nanoparticle-Based Immunoassays
Published on: June 23, 2022
