Related Experiment Video
Updated: Jun 9, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Stair-Climbing Wheeled Robot Based on Rotating Locomotion of Curved-Spoke Legs
1Department of Mechanical Engineering, Inha University, Incheon 22212, Republic of Korea.

Abstract:
This study proposes a new wheel-leg mechanism concept and formulations for the kinematics and dynamics of a stair-climbing robot utilizing the rotating leg locomotion of curved spokes and rolling tires. The system consists of four motor-driven tires and four curved-spoke legs. The curved-spoke leg is semicircle-like and is used to climb stairs. Once the spoke leg rolls on the surface, it lifts and pulls the mating wheel toward the surface, owing to the kinematic constraint between the spoke and the wheel. Single-wheel climbing is a necessary condition for the stair climbing of whole robots equipped with front and rear axles. This study proposes the design requirements of a spoke leg for the success of single-wheel climbing in terms of kinematic inequality equations according to the scenario of single-wheel climbing. For a design configuration that enables single-wheel climbing, the required minimum friction coefficient for the static analysis of the stair-climbing wheeled robots is demon-strated. Thereafter, the stair-climbing ability is validated through the dynamic equations that enable the frictional slip of the tires, as well as the curved-spoke legs. Lastly, the results revealed that the rotating locomotion of the well-designed curved-spoke legs effectively enables the stair climbing of the whole robot.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...
 01:09
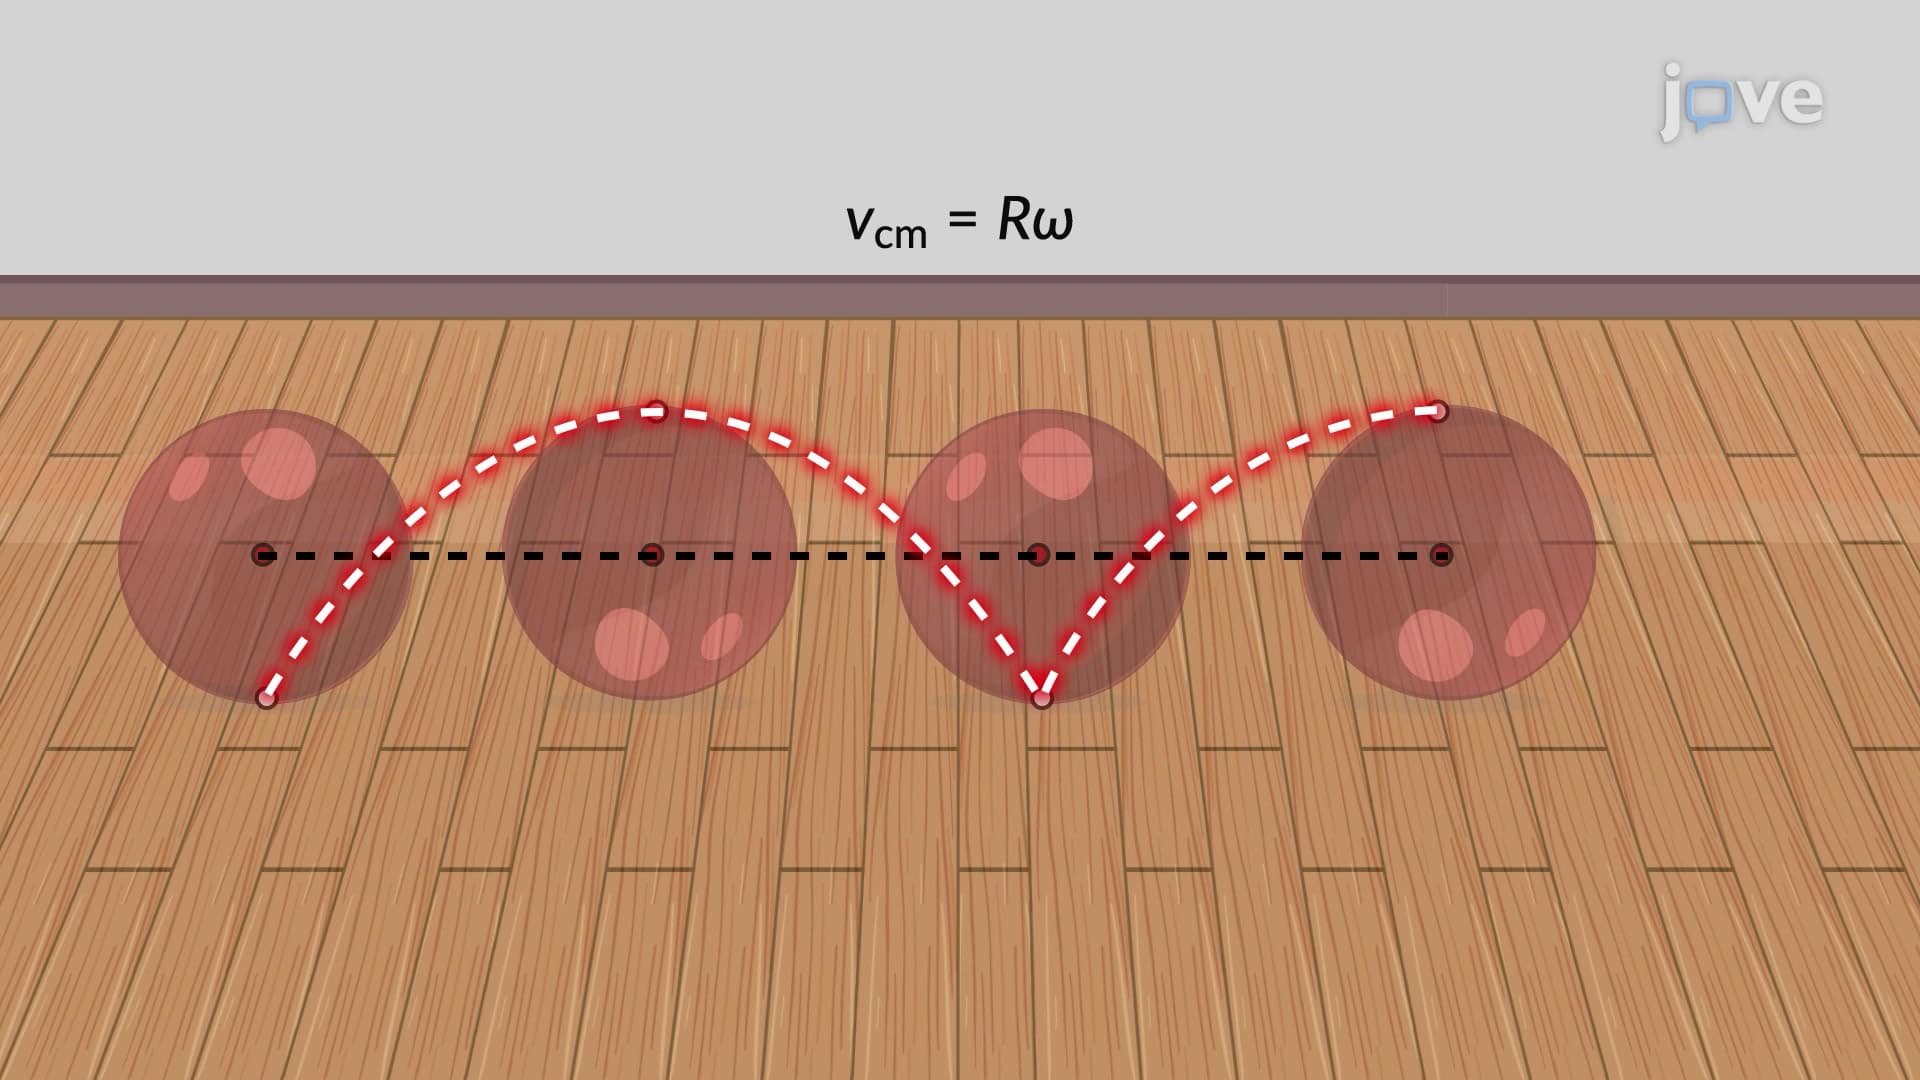
Rolling Without Slipping
 01:24
Bearings: Problem Solving
 01:26
Rotational Motion about a Fixed Axis
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...