Related Experiment Video
Updated: Jun 9, 2025

Experimental Methods for Spin- and Angle-Resolved Photoemission Spectroscopy Combined with Polarization-Variable Laser
Published on: June 28, 2018
Polynomial Regression on Lie Groups and Application to SE(3)
Johan Aubray1, Florence Nicol1
1Ecole Nationale de l'Aviation Civile, Université de Toulouse, 7, Avenue Edouard Belin, 31400 Toulouse, France.

Abstract:
In this paper, we address the problem of estimating the position of a mobile such as a drone from noisy position measurements using the framework of Lie groups. To model the motion of a rigid body, the relevant Lie group happens to be the Special Euclidean group SE(n), with n=2 or 3. Our work was carried out using a previously used parametric framework which derived equations for geodesic regression and polynomial regression on Riemannian manifolds. Based on this approach, our goal was to implement this technique in the Lie group SE(3) context. Given a set of noisy points in SE(3) representing measurements on the trajectory of a mobile, one wants to find the geodesic that best fits those points in a Riemannian least squares sense. Finally, applications to simulated data are proposed to illustrate this work. The limitations of such a method and future perspectives are discussed.
Related Concept Videos
 01:29
Three-Dimensional Analysis of Strain
 01:27
Gauss's Law: Planar Symmetry
 01:19
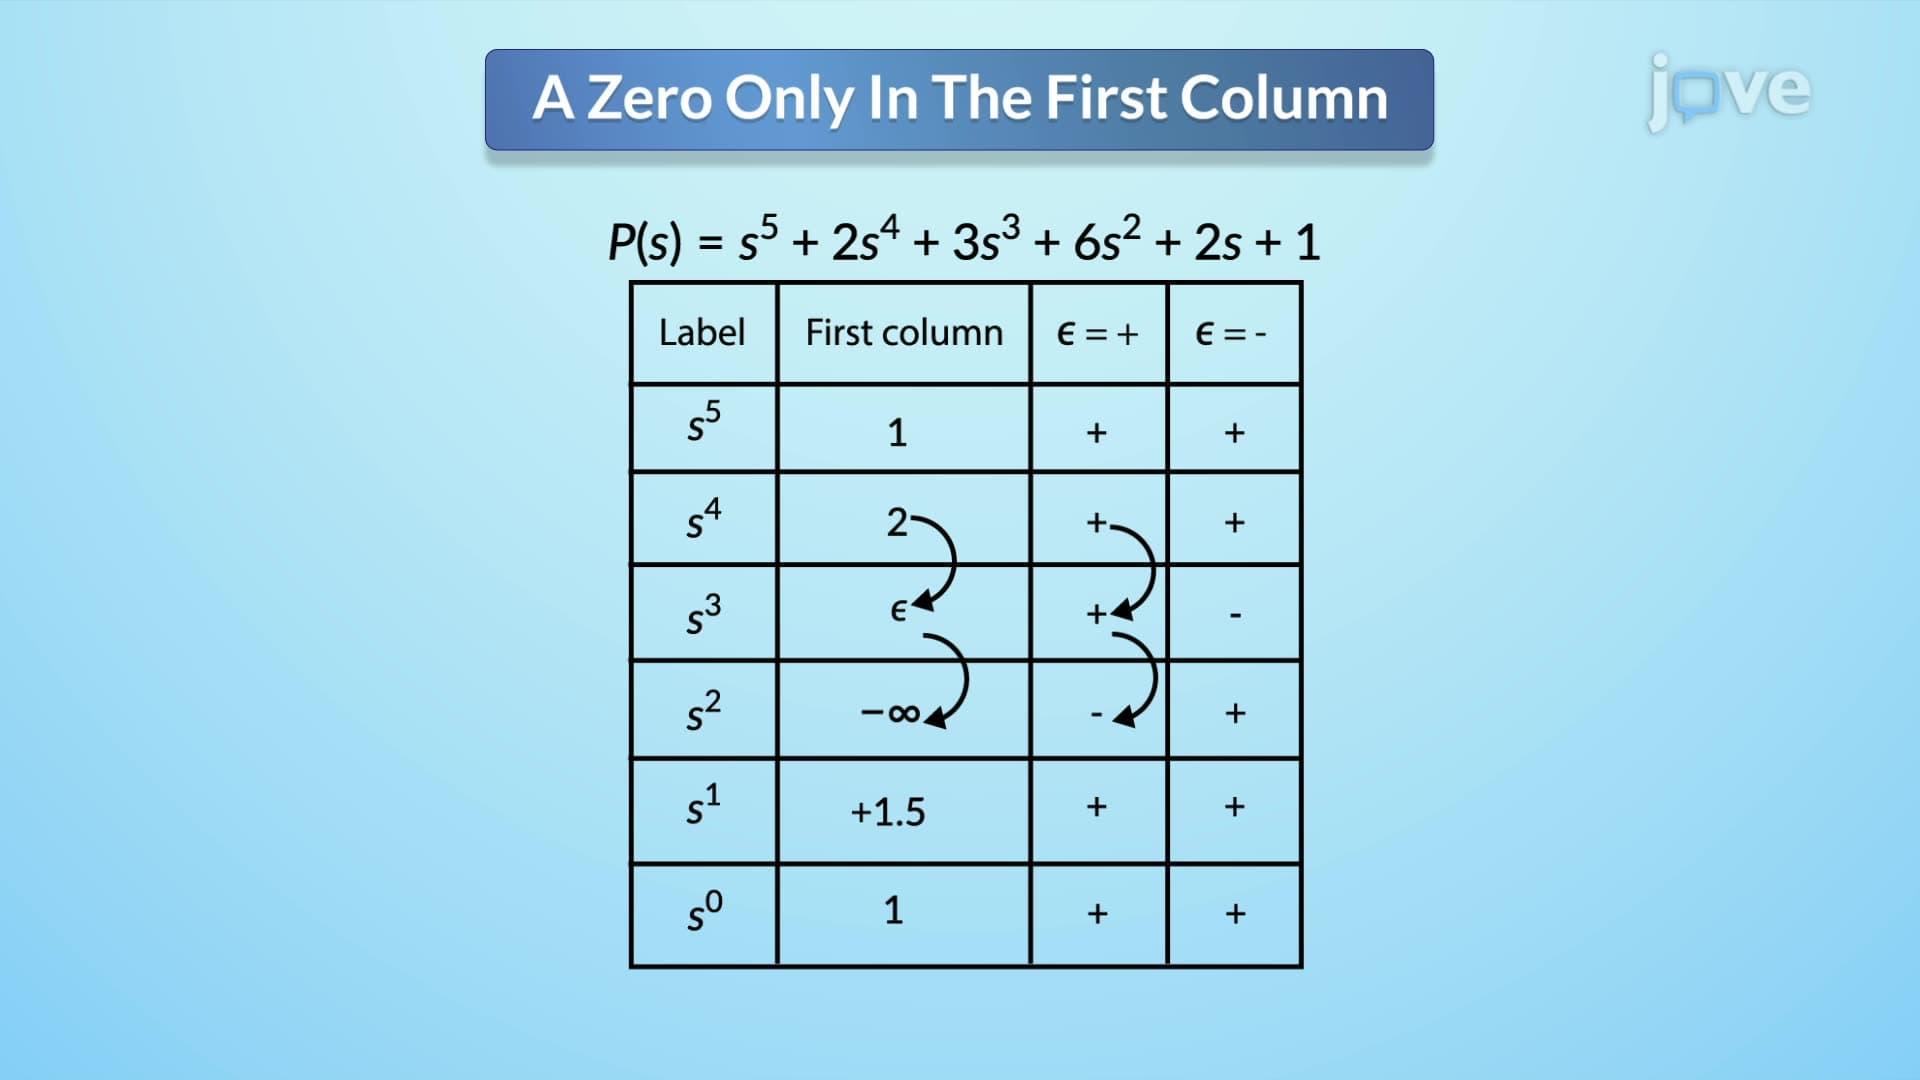
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 02:52
VSEPR Theory and the Basic Shapes
 02:27
Predicting Molecular Geometry
 01:16
SFG Algebra
Each node in an SFG corresponds to a variable, and the interactions between nodes are represented by branches with associated gains. When multiple branches lead into a node, the value at that node is the sum of the...