Related Experiment Video
Updated: Jun 29, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Energy-Saving Multi-Agent Deep Reinforcement Learning Algorithm for Drone Routing Problem
Xiulan Shu1, Anping Lin2, Xupeng Wen3
1School of Intelligent Manufacturing Engineering, Zhanjiang University of Science and Technology, Zhanjiang 524000, China.

Abstract:
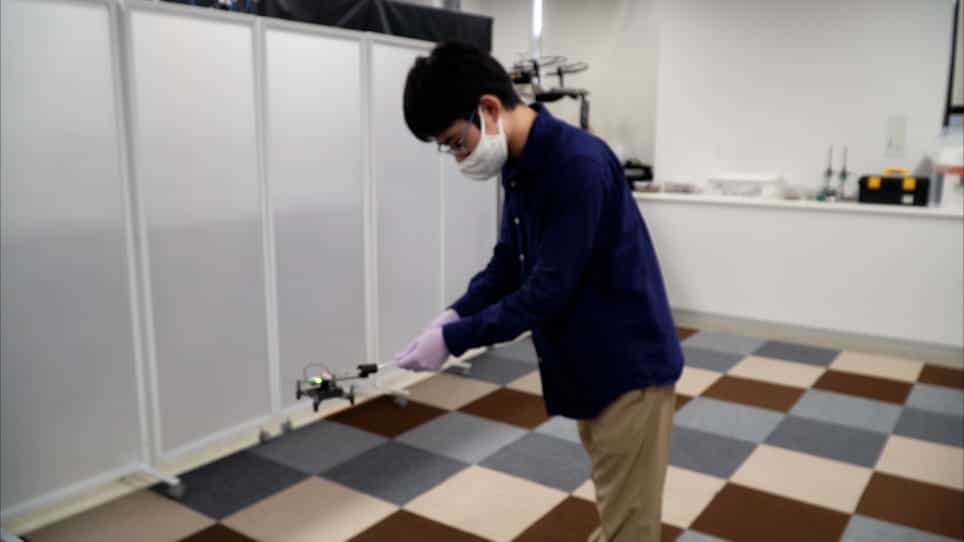
With the rapid advancement of drone technology, the efficient distribution of drones has garnered significant attention. Central to this discourse is the energy consumption of drones, a critical metric for assessing energy-efficient distribution strategies. Accordingly, this study delves into the energy consumption factors affecting drone distribution. A primary challenge in drone distribution lies in devising optimal, energy-efficient routes for drones. However, traditional routing algorithms, predominantly heuristic-based, exhibit certain limitations. These algorithms often rely on heuristic rules and expert knowledge, which can constrain their ability to escape local optima. Motivated by these shortcomings, we propose a novel multi-agent deep reinforcement learning algorithm that integrates a drone energy consumption model, namely EMADRL. The EMADRL algorithm first formulates the drone routing problem within a multi-agent reinforcement learning framework. It subsequently designs a strategy network model comprising multiple agent networks, tailored to address the node adjacency and masking complexities typical of multi-depot vehicle routing problem. Training utilizes strategy gradient algorithms and attention mechanisms. Furthermore, local and sampling search strategies are introduced to enhance solution quality. Extensive experimentation demonstrates that EMADRL consistently achieves high-quality solutions swiftly. A comparative analysis against contemporary algorithms reveals EMADRL's superior energy efficiency, with average energy savings of 5.96% and maximum savings reaching 12.45%. Thus, this approach offers a promising new avenue for optimizing energy consumption in last-mile distribution scenarios.
Related Concept Videos
 01:21
Distributed Loads: Problem Solving
 01:17
Rolling Resistance: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:30
Vector Functions and Motion: Problem Solving
 01:30
Lagrange Multipliers: Problem Solving