Ti3C2T MXene Based Electro-Ionic Soft Actuator with Potential for Wearable Finger Straps
Related Experiment Video
Updated: Oct 19, 2026
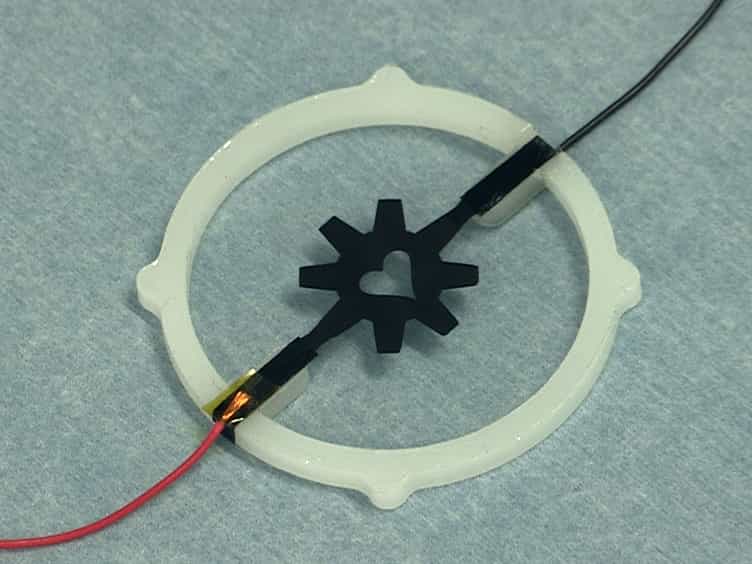
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
1School of Mechanical Engineering, Southeast University, Nanjing 211189, People's Republic of China.

Abstract:
Soft electro-ionic actuators have received extensive research and attention due to their advantages such as low voltage response and adjustable deformation. However, they have not been able to enter the actual industry application like traditional rigid actuators; one of the reasons may be that the kinematic properties of actuators have been less studied. The electro-ionic actuator based on Ti3C2T MXene-CNT/PPy electrode prepared in this paper shows good bending displacement (18.8 mm) and strain (0.63%) under 4 V voltage. In this article, the overlapping nature and exponential function relationship of the actuator end-point trajectories are preliminarily discussed, and the morphology change and cubic polynomial function relationship of the actuator body are considered. Moreover, in application, a novel proof-of-concept model of smart wearable finger straps is proposed. This study is a unique attempt and is hoped to provide a new research perspective in the field of soft electro-ionic actuators.
Related Concept Videos
 01:17
Electrodes: Overview
There are two main types of electrodes in electrochemical cells. The first type, known as the working or indicator electrode, has a potential that is sensitive to the analyte's concentration and reacts to changes in the...
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...