Related Experiment Video
Updated: May 5, 2026
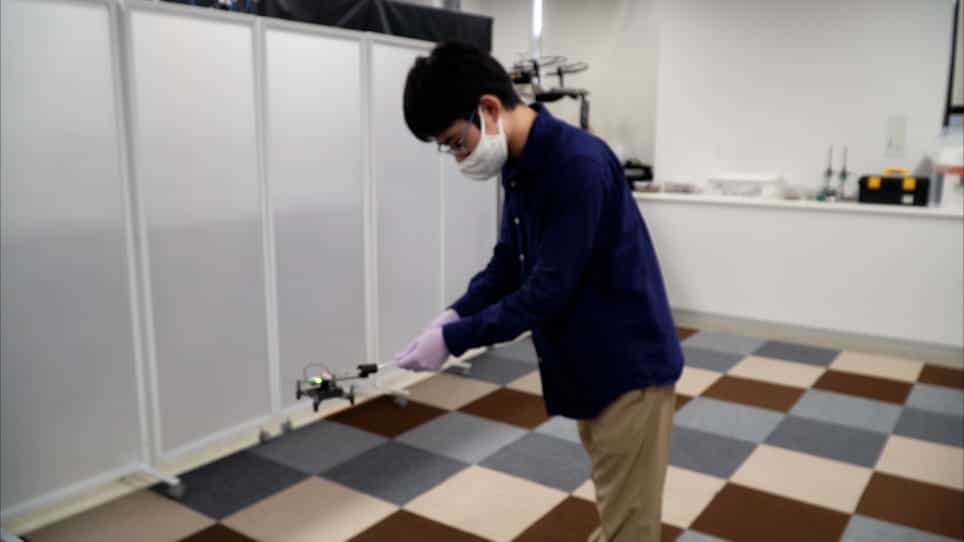

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
A bio-inspired looming detection for stable landing in unmanned aerial vehicles
Yupeng Xie1, Zhiteng Li1, Linkun Song1
1Guangxi Key Laboratory of Intelligent Control and Maintenance of Power Equipment, School of Electrical Engineering, Guangxi University, Nanning 530004, People's Republic of China.

Abstract:
Flying insects, such as flies and bees, have evolved the capability to rely solely on visual cues for smooth and secure landings on various surfaces. In the process of carrying out tasks, micro unmanned aerial vehicles (UAVs) may encounter various emergencies, and it is necessary to land safely in complex and unpredictable ground environments, especially when altitude information is not accurately obtained, which undoubtedly poses a significant challenge. Our study draws on the remarkable response mechanism of the Lobula Giant Movement Detector to looming scenarios to develop a novel UAV landing strategy. The proposed strategy does not require distance estimation, making it particularly suitable for payload-constrained micro aerial vehicles. Through a series of experiments, this strategy has proven to effectively achieve stable and high-performance landings in unknown and complex environments using only a monocular camera. Furthermore, a novel mechanism to trigger the final landing phase has been introduced, further ensuring the safe and stable touchdown of the drone.
More Related Videos

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:29
Application of Linearization and Approximation