Related Experiment Video
Updated: Jun 8, 2025
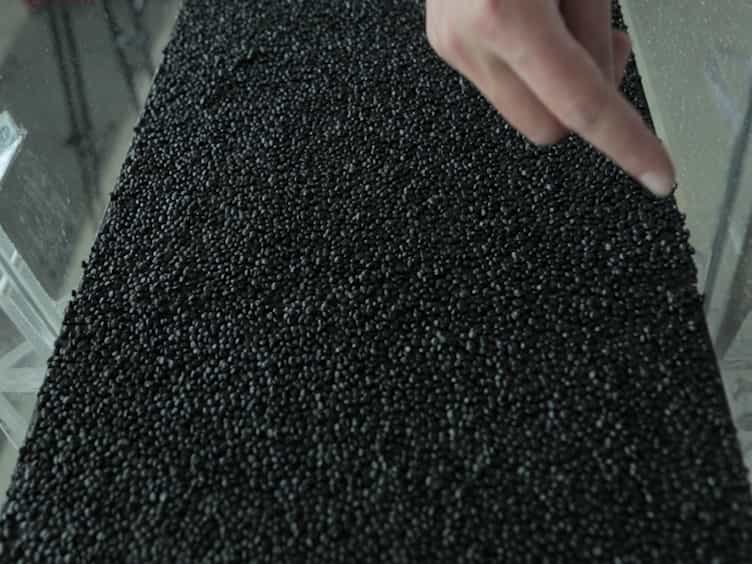

Image-based Lagrangian Particle Tracking in Bed-load Experiments
Published on: July 20, 2017
Lagrangian gradient regression for the detection of coherent structures from sparse trajectory data
Tanner D Harms1, Steven L Brunton2, Beverley J McKeon3
1Graduate Aerospace Laboratories, California Institute of Technology, Pasadena, CA 91106, USA.

Abstract:
Complex flows are often characterized using the theory of Lagrangian coherent structures (LCS), which leverages the motion of flow-embedded tracers to highlight features of interest. LCS are commonly employed to study fluid mechanical systems where flow tracers are readily observed, but they are broadly applicable to dynamical systems in general. A prevailing class of LCS analyses depends on reliable computation of flow gradients. The finite-time Lyapunov exponent (FTLE), for example, is derived from the Jacobian of the flow map, and the Lagrangian-averaged vorticity deviation (LAVD) relies on velocity gradients. Observational tracer data, however, are typically sparse (e.g. drifters in the ocean), making accurate computation of gradients difficult. While a variety of methods have been developed to address tracer sparsity, they do not provide the same information about the flow as gradient-based approaches. This work proposes a purely Lagrangian method, based on the data-driven machinery of regression, for computing instantaneous and finite-time flow gradients from sparse trajectories. The tool is demonstrated on a common analytical benchmark to provide intuition and demonstrate performance. The method is seen to effectively estimate gradients using data with sparsity representative of observable systems.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...