Related Experiment Video
Updated: Jun 8, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Safe Transfer-Reinforcement-Learning-Based Optimal Control of Nonlinear Systems

Abstract:
Traditional reinforcement learning (RL) methods for optimal control of nonlinear processes often face challenges, such as high computational demands, long training times, and difficulties in ensuring the safety of closed-loop systems during training. To address these issues, this work proposes a safe transfer RL (TRL) framework. The TRL algorithm leverages knowledge from pretrained source tasks to accelerate learning in a new, related target task, significantly reducing both learning time and computational resources required for optimizing control policies. To ensure safety during knowledge transfer and training, data collection and optimization of the control policy are performed within a control invariant set (CIS) throughout the learning process. Furthermore, we theoretically analyze the errors between the approximate and optimal control policies by accounting for the differences between source and target tasks. Finally, the proposed TRL method is applied to the case studies of chemical processes to demonstrate its effectiveness in solving the optimal control problem with improved computational efficiency and guaranteed safety.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
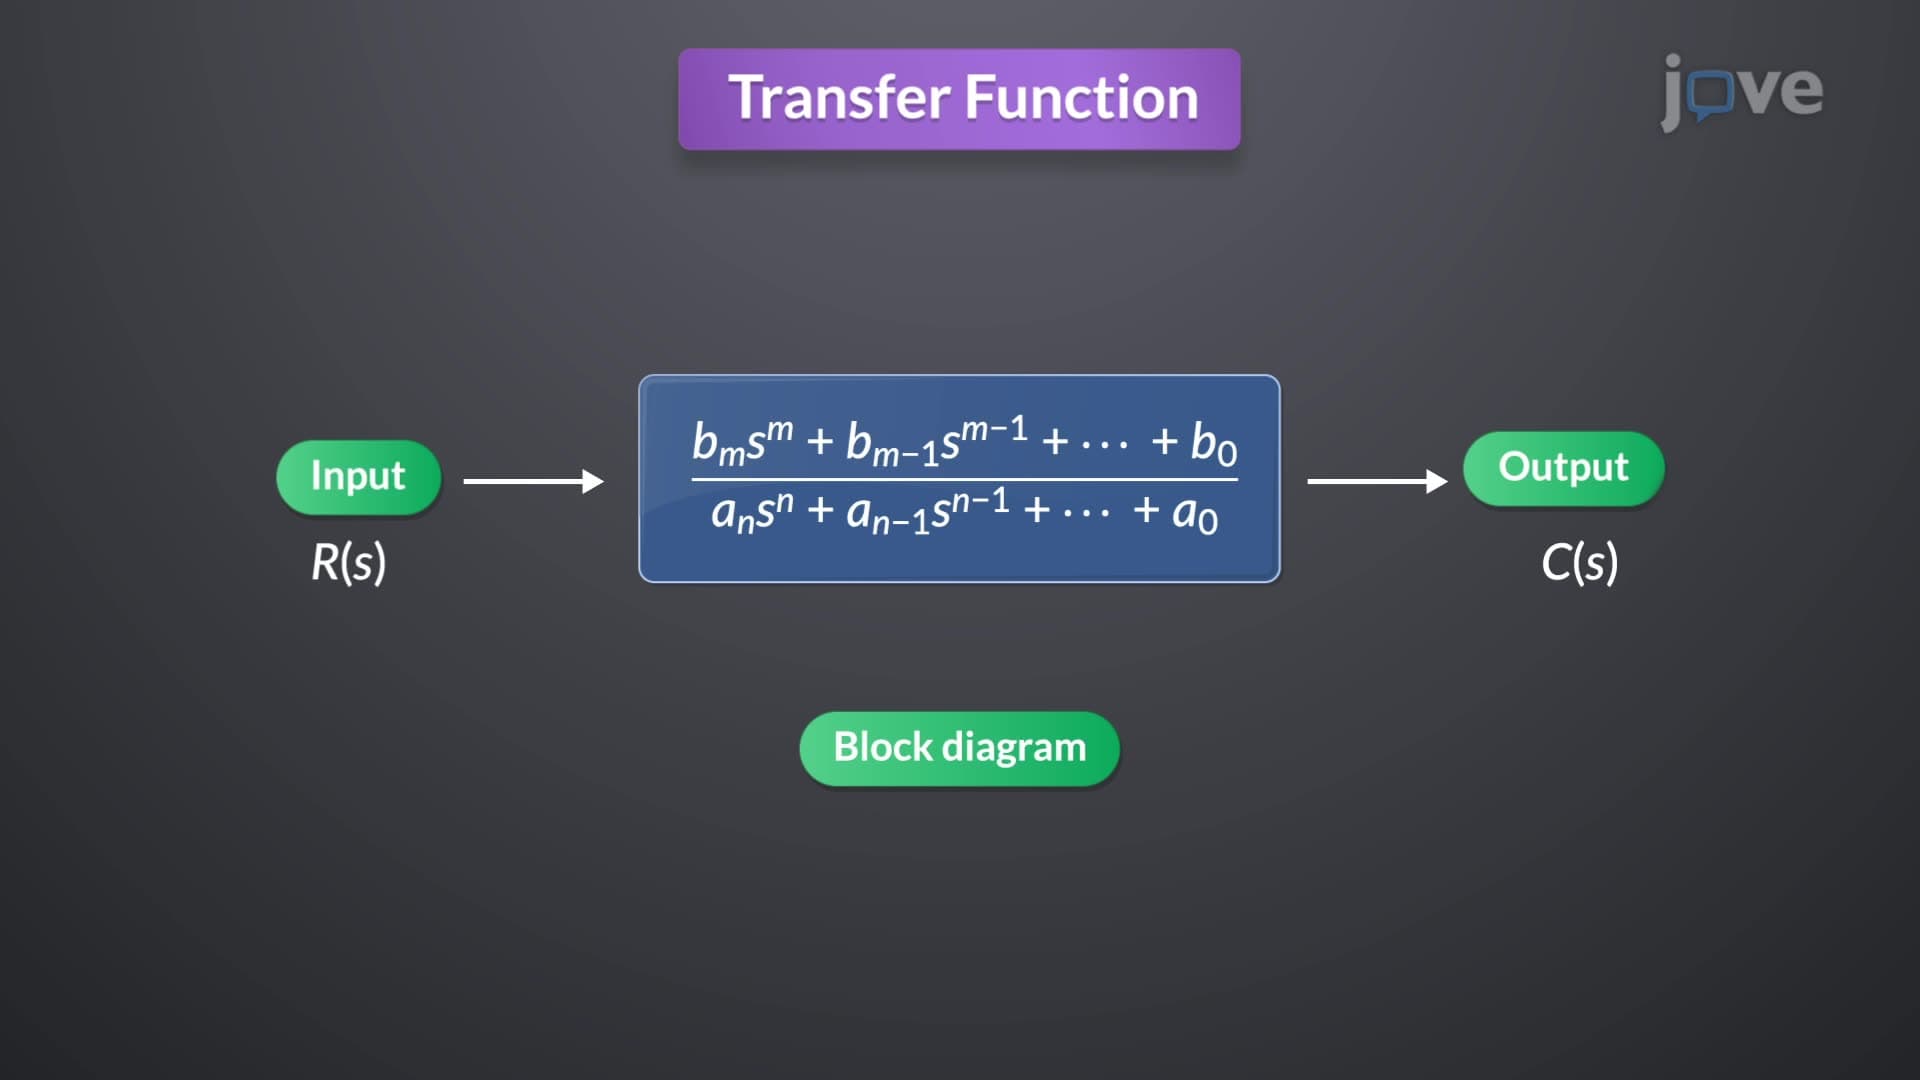
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:10
Control Systems
At the heart...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...