Related Experiment Video
Updated: Jun 8, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Toward a Generic Framework for Mission Planning and Execution with a Heterogeneous Multi-Robot System
Mohsen Denguir1, Ameur Touir2, Achraf Gazdar1
1Department of Software Engineering, College of Computer and Information Sciences, King Saud University, Riyadh 11543, Saudi Arabia.

Abstract:
This paper presents a comprehensive framework for mission planning and execution with a heterogeneous multi-robot system, specifically designed to coordinate unmanned ground vehicles (UGVs) and unmanned aerial vehicles (UAVs) in dynamic and unstructured environments. The proposed architecture evaluates the mission requirements, allocates tasks, and optimizes resource usage based on the capabilities of the available robots. It then executes the mission utilizing a decentralized control strategy that enables the robots to adapt to environmental changes and maintain formation stability in both 2D and 3D spaces. The framework's architecture supports loose coupling between its components, enhancing system scalability and maintainability. Key features include a robust task allocation algorithm, and a dynamic formation control mechanism, using a ROS 2 communication protocol that ensures reliable information exchange among robots. The effectiveness of this framework is demonstrated through a case study involving coordinated exploration and data collection tasks, showcasing its ability to manage missions while optimizing robot collaboration. This work advances the field of heterogeneous robotic systems by providing a scalable and adaptable solution for multi-robot coordination in challenging environments.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
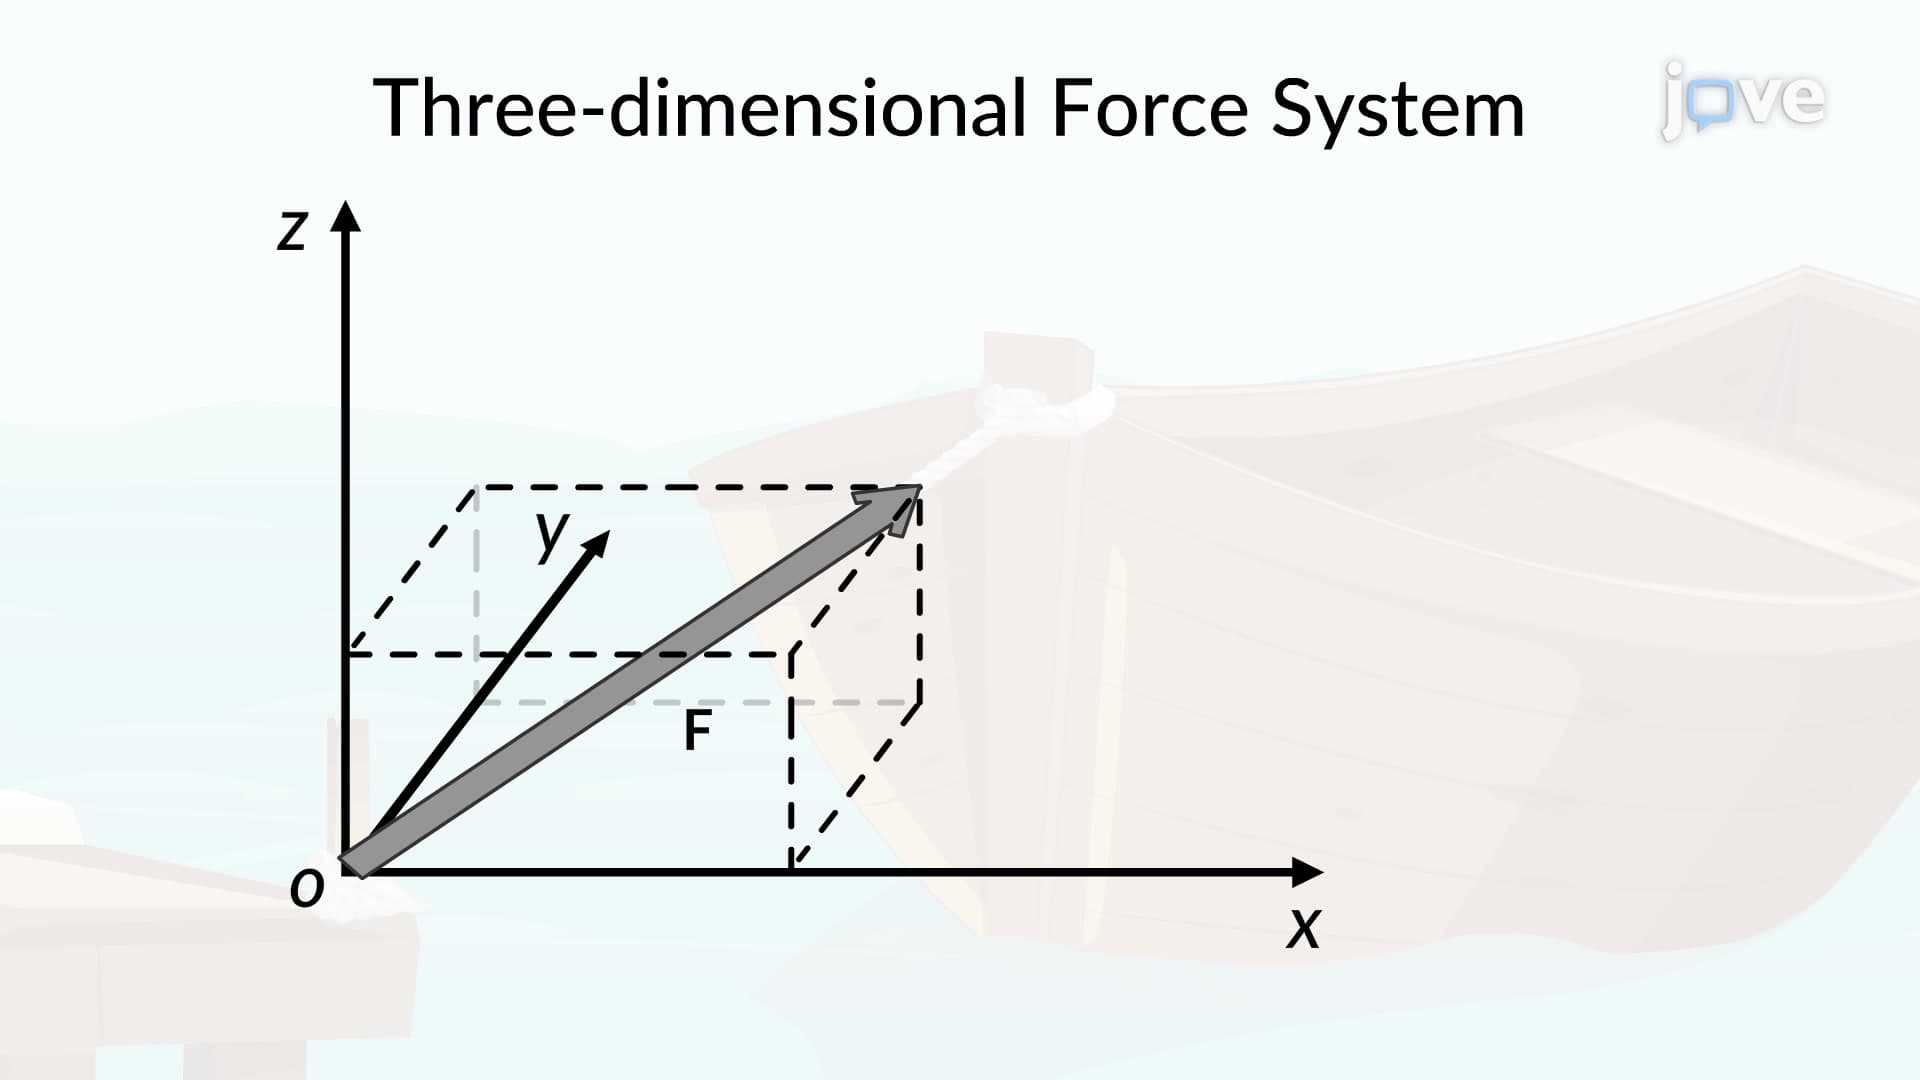 01:30
Three-Dimensional Force System
 01:22
Mechanical Systems
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...