Related Experiment Video
Updated: Jun 6, 2025

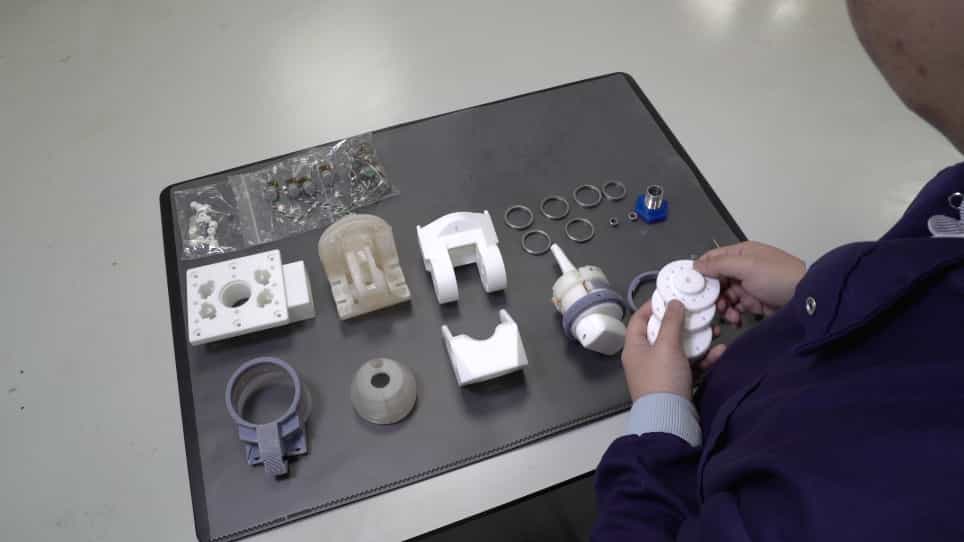
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Robust Control Strategy of Acoustic Micro Robots Based on Fuzzy System
1School of Mechanical Engineering, Beijing Institute of Technology, Beijing 100081, China.

Abstract:
This study presents a robust control strategy for acoustic micro robots utilizing a novel interval type-three fuzzy system. Micro robots driven by acoustic forces face significant challenges in fluid environments due to complex nonlinearities, uncertainties, and disturbances. To address these issues, we propose a control framework that combines fuzzy logic and sliding mode control to enhance the stability and trajectory tracking performance of micro robots under varying fluid conditions. The interval type-3 fuzzy logic system provides increased robustness by better handling external disturbances and uncertainties compared to the robustness of the traditional methods. The experimental results from one-dimensional, two-dimensional, and three-dimensional fluid cavities demonstrate that the proposed control method significantly improves tracking accuracy, reducing the errors in complex environments. This control framework offers promising potential for the precise manipulation of micro robots in biomedical applications and other microfluidic systems. The minimum trajectory tracking control mean square error is 12.82 μm.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...