Related Experiment Video
Updated: Jun 14, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Development of a Variable-Pitch Flexible-Screw-Driven Continuum Robot (FSDCR) with Motion Decoupling Capability
Yuhao Xu1, Dezhi Song1, Ketao Zhang2
1Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, School of Mechanical Engineering, Tianjin University, Tianjin, China.

Abstract:
Tendon-driven continuum robots suffer from crosstalk of driving forces between sections, typically resulting in motion coupling between sections, which affects their motion accuracy and complicates the control strategies. To address these issues, this article proposes a mechanically designed variable-pitch flexible-screw-driven continuum robot (FSDCR) that enables motion decoupling between sections. The continuum section of the FSDCR comprises a series of orthogonally arranged vertebrae and is driven by customized variable-pitch flexible screws. The variable-pitch flexible screws apply driving forces and constraints to several threaded vertebrae in the continuum section, improving positioning accuracy and loading capacity. The flexible screws effectively balance the driving force and torque within one section through antagonistic torsional actuation, thereby achieving motion decoupling between sections. Characterization experiments have been conducted to compare the motion accuracy and load capacity of the variable-pitch FSDCR with those of the constant-pitch FSDCR. The results demonstrate that the variable-pitch FSDCR exhibits improved positioning accuracy, minimizing an average error of 0.79 mm (0.60% relative to its total length), which is 82.09% lower than that of the constant-pitch FSDCR. The load capacity of the variable-pitch FSDCR is enhanced by up to 129.09% compared with the constant-pitch FSDCR. Experiments on the motion decoupling performance of the FSDCR show that the maximum motion coupling error is 0.32 mm (0.24% relative to the section length). Additionally, the motion coupling error is minimally influenced by the rotational speed of the screw. Finally, a three-section FSDCR is constructed, and its load capacity and motion flexibility are demonstrated.


Related Concept Videos
 01:22
Mechanical Systems
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:20
Plastic Deformation in Circular Shafts
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:15
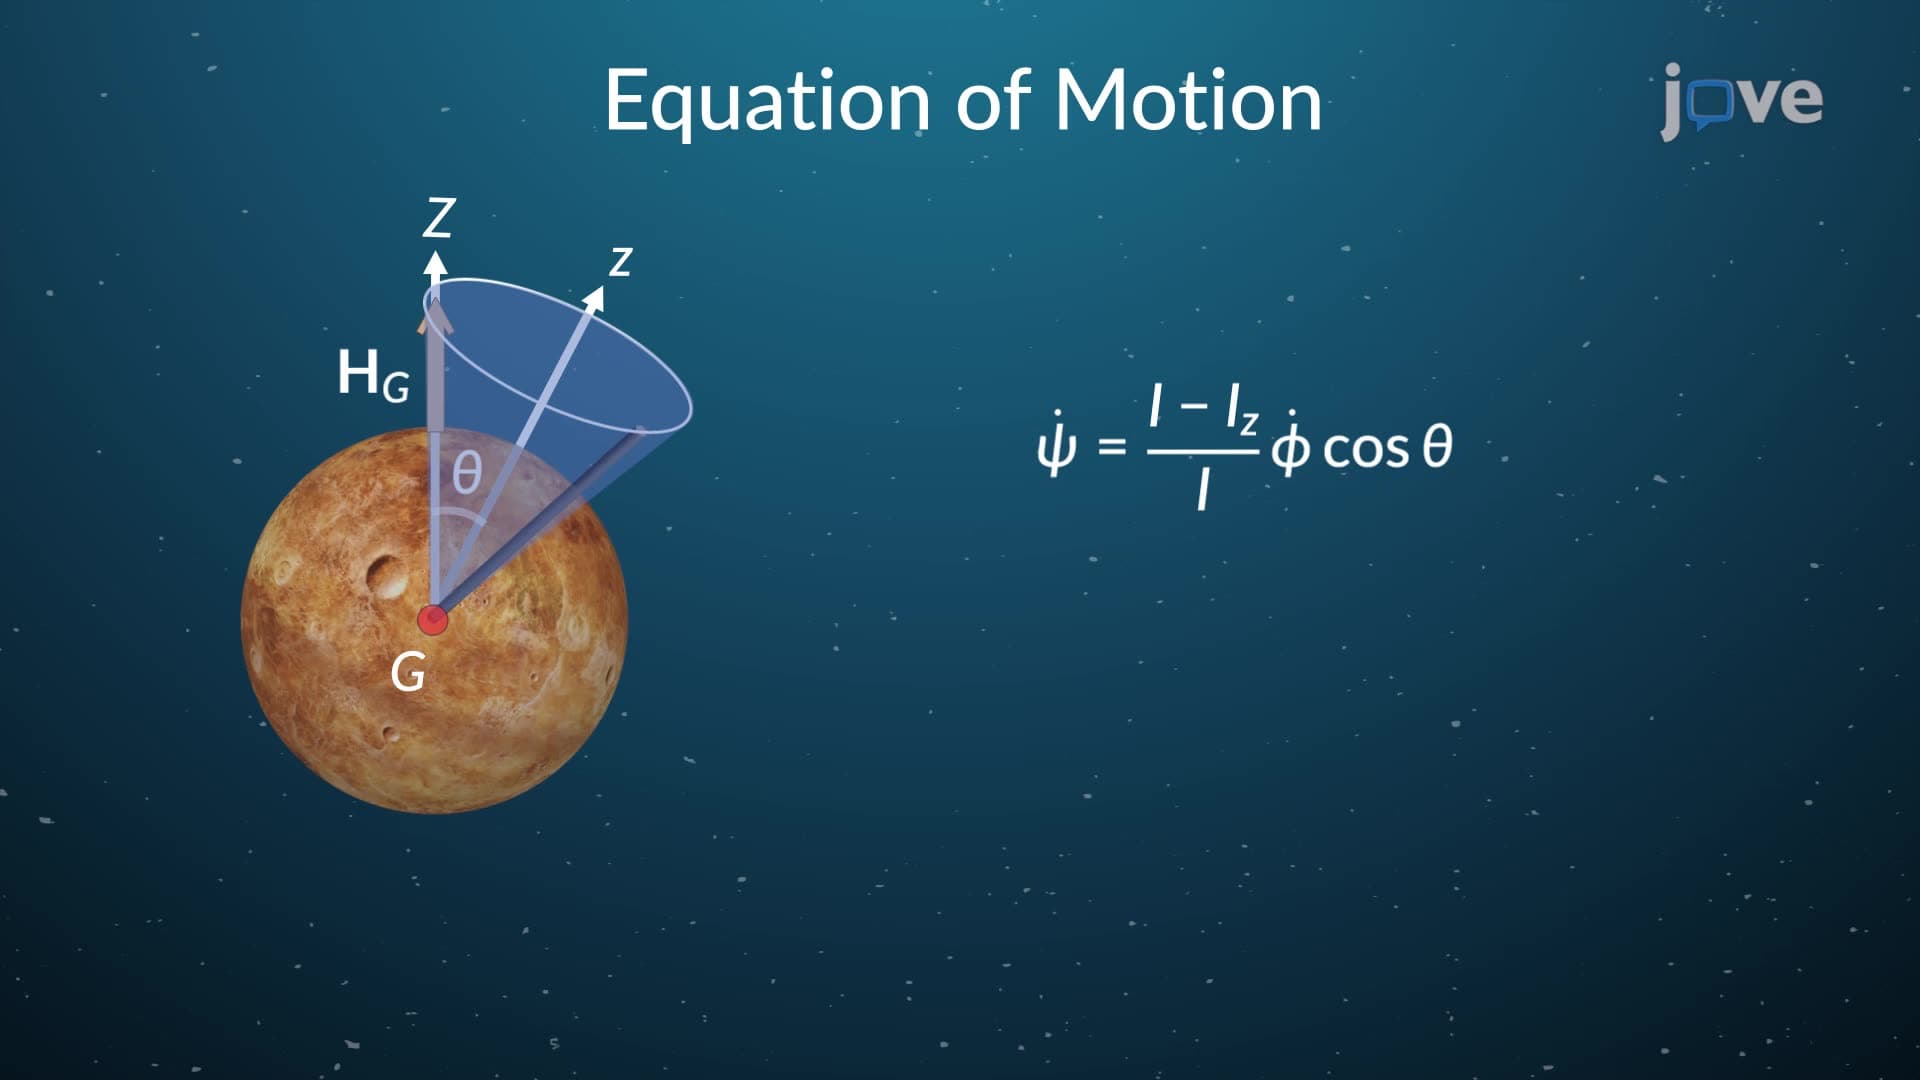
Torque Free Motion
 01:10
Deformation in a Circular Shaft