Related Experiment Video
Updated: Jun 5, 2025
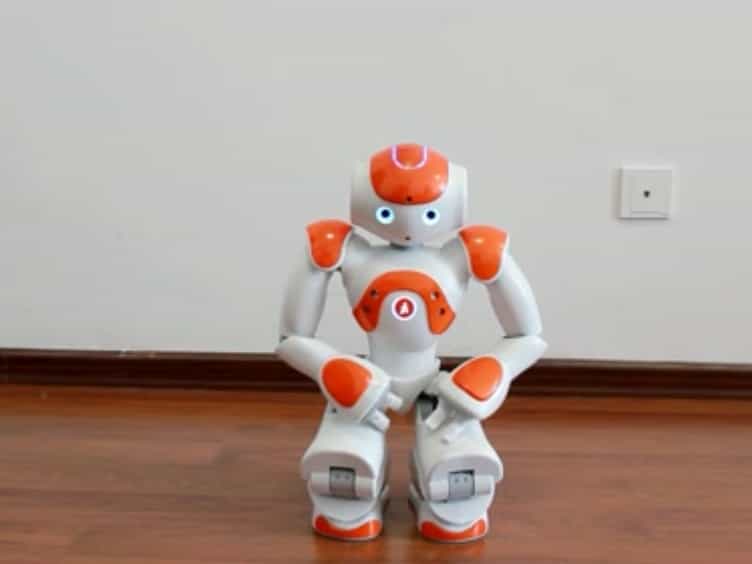

SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Robocup 2023-2024 ROSbag Dataset
Irene González Fernández1, Juan Diego Peña Narváez1, José Miguel Guerrero Hernández1
1Department of Signal Theory and Communications and Telematic Systems and Computation, Universidad Rey Juan Carlos, Campus Fuenlabrada, Camino del Molino, 5, Fuenlabrada, Madrid 28942, Spain.

Abstract:
This dataset was collected during the 2023 and 2024 RoboCup competitions using the TIAGo robot equipped with an RGB-D camera, a Hokuyo laser, and a RODE microphone. The dataset includes ROSbag files that capture the robot's sensory data and planning task behavior, as well as video recordings that provide third-person perspectives of task execution. These data provide information about the performance of autonomous robots in social tasks and navigation in dynamic environments with human interaction.

