Related Experiment Video
Updated: Jun 5, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Developing inverse motion planning technique for autonomous vehicles using integral nonlinear constraints
1Department of Civil Engineering, Toronto Metropolitan University, 350 Victoria Street, Toronto, ON M5B2K3, Canada.

Abstract:
The study considers issues of elaborating and validating a technique of autonomous vehicle motion planning based on sequential trajectory and speed optimization. This method includes components such as representing sought-for functions by finite elements (FE), vehicle kinematic model, sequential quadratic programming for nonlinear constrained optimization, and Gaussian N-point quadrature integration. The primary novelty consists of using the inverse approach for obtaining vehicle trajectory and speed. The curvature and speed are represented by integrated polynomials to reduce the number of unknowns. For this, piecewise functions with two and three degrees of freedom (DOF) are implemented through FE nodal parameters. The technique ensures higher differentiability compared to the needed in the geometric and kinematic equations. Thus, the generated reference curves are characterized by simple and unambiguous forms. The latter fits best the control accuracy and efficiency during the motion tracking phase. Another advantage is replacing the nodal linear equality constraints with integral nonlinear ones. This ensures the non-violation of boundary limits within each FE and not only in nodes. The optimization technique implies that the spatial and time variables must be found separately and staged. The trajectory search is accomplished in the restricted allowable zone composed by superposing an area inside the external and internal boundaries, based on keeping safe distances, excluding areas for moving obstacles. Thus, this study compares two models that use two and three nodal DOF on optimization quality, stability, and rapidity in real-time applications. The simulation example shows numerous graph results of geometric and kinematic parameters with smoothed curves up to the highest derivatives. Finally, the conclusions are made on the efficiency and quality of prognosis, outlining the similarities and differences between the two applied models.
More Related Videos

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
PI Controller: Design
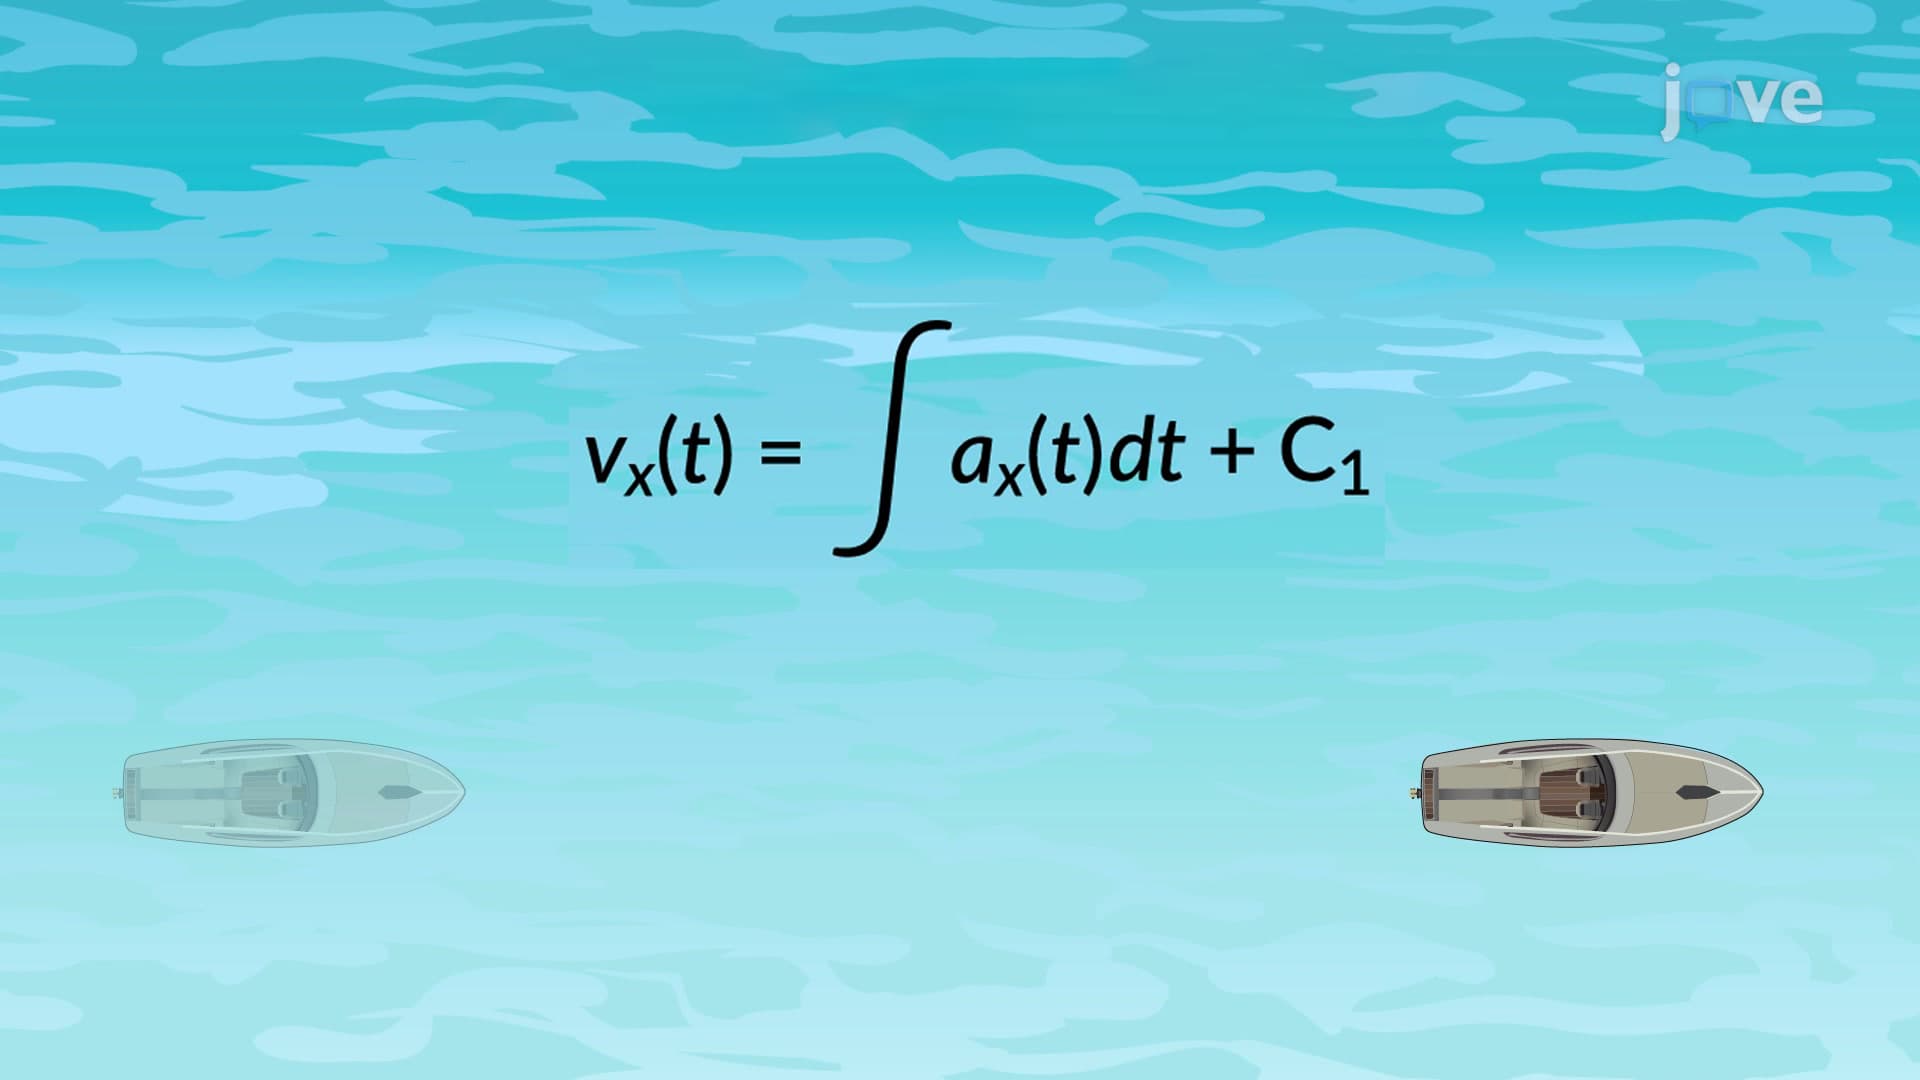 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:15
Kinematic Equations: Problem Solving
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...