Related Experiment Video
Updated: Jun 5, 2025
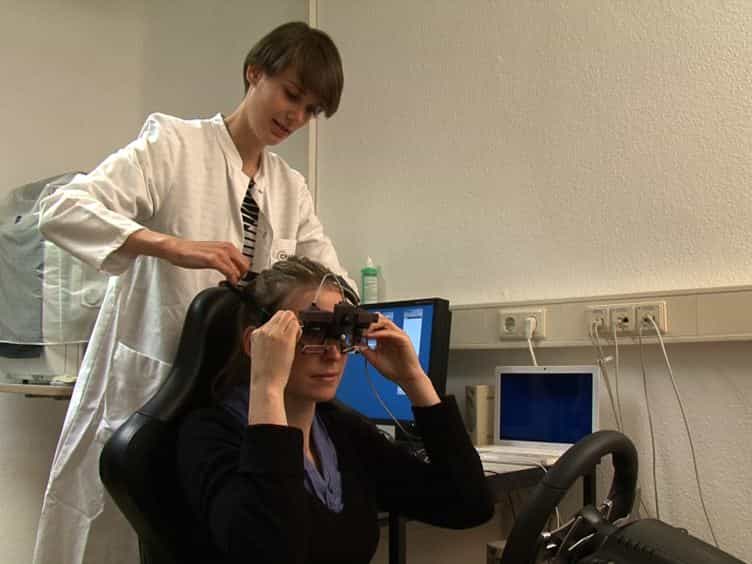

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
How do drivers perceive collision risk? A quantitative exploration in generalized two-dimensional scenarios
Jinghua Wang1, Guangquan Lu2, Wenmin Long1
1School of Transportation Science and Engineering, Beihang University, Beijing 100191, China.

Abstract:
Driving behavior is crucial in shaping traffic dynamics and serves as the foundation for safe and efficient autonomous driving. Despite the widespread interest in driving behavior modeling, existing models often focus on specific behaviors and cannot describe all types of vehicle movements, while vehicle status and driving scenarios are dynamic and infinite. That means comprehending and modeling generalized driving behavior mechanisms is essential. Risk Homeostasis Theory (RHT) emerges as a compelling conceptual framework to explain human risk behaviors comprehensively. The critical problem in modeling behavior using RHT is quantifying the subject risk precepted by humans. RHT has been applied in car-following behavior modeling based on the one-dimensional risk indicator Safety Margin (SM), simplifying the specific behavior along its direction. While the generalized perceived risk indicator on the two-dimensional surface still lacks. Considering the collision avoidance capacity from the driver's perspective, this paper proposes the two-dimensional safety margin (TSM) to describe the driver's risk perception in generalized driving scenarios with two-dimensional movements. Results demonstrate that TSM could accurately describe car-following behavior compared to existing risk indicators, with a 9.1 % correlation improvement and the reasonably calibrated response time (1.07 s). And TSM could effectively capture the discrepant risk perceptions of different drivers involved in the same conflict, underscoring the alignment of TSM with drivers' subjective risk perceptions. Besides, TSM reflects the risk homeostasis of driving behaviors, as both typical scenarios have the normally distributed and concentrated target levels. Further, TSM also achieves a generalized, scenario-independent risk quantification with a mean target level of 0.85. As a good representation of driver's risk perception in two-dimensional scenarios, TSM serves as a crucial basis in areas such as driving behavior modeling, and decision-making and testing of autonomous driving.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:05
Collisions in Multiple Dimensions: Introduction
 01:42
Schemas
 01:15
Elastic Collisions: Case Study
 01:19
Types of Collisions - II
 01:29
Sight Distance in a Vertical Curve