Related Experiment Video
Updated: May 6, 2026
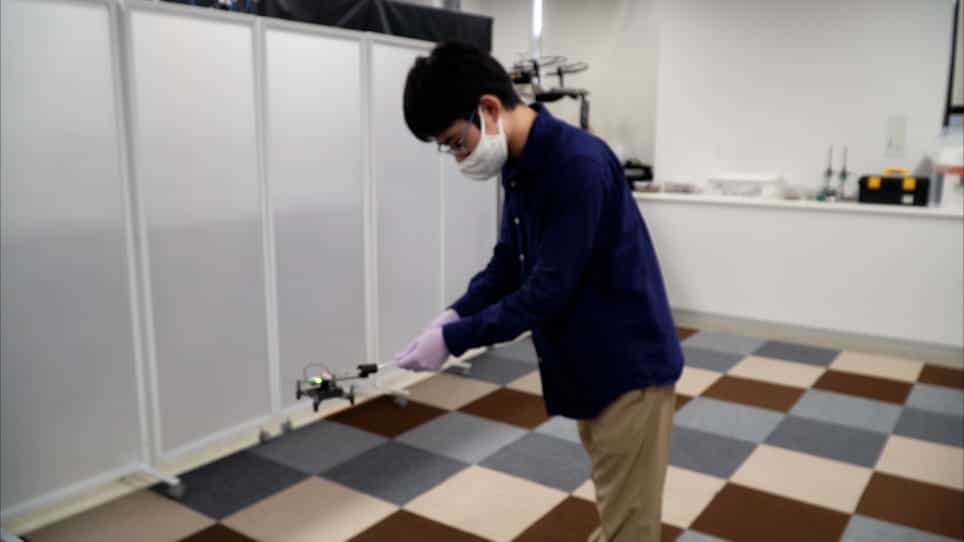

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
A Novel Dataset and Detection Method for Unmanned Aerial Vehicles Using an Improved YOLOv9 Algorithm
Depeng Gao1, Jianlin Tang2, Hongqi Li2
1School of Yonyou Digital and Intelligence, Nantong Institute of Technology, Nantong 226001, China.

Abstract:
With the growing popularity of unmanned aerial vehicles (UAVs), their improper use is significantly disrupting society. Individuals and organizations have been continuously researching methods for detecting UAVs. However, most existing detection methods fail to account for the impact of similar flying objects, leading to weak anti-interference capabilities. In other words, when such objects appear in the image, the detector may mistakenly identify them as UAVs. Therefore, this study aims to enhance the anti-interference ability of UAV detectors by constructing an anti-interference dataset comprising 5062 images. In addition to UAVs, this dataset also contains three other types of flying objects that are visually similar to the UAV targets: planes, helicopters, and birds. This dataset can be used in model training to help detectors distinguish UAVs from these nontarget objects and thereby improve their anti-interference capabilities. Furthermore, we propose an anti-interference UAV detection method based on YOLOv9-C in which the dot distance is used as an evaluation index to assign positive and negative samples. This results in an increased number of positive samples, improving detector performance in the case of small targets. The comparison of experimental results shows that the developed method has better anti-interference performance than other algorithms. The detection method and dataset used to test the anti-interference capabilities in this study are expected to assist in the development and validation of related research methods.

Related Concept Videos
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:28
Methods of Classification and Identification