Related Experiment Video
Updated: Jun 4, 2025
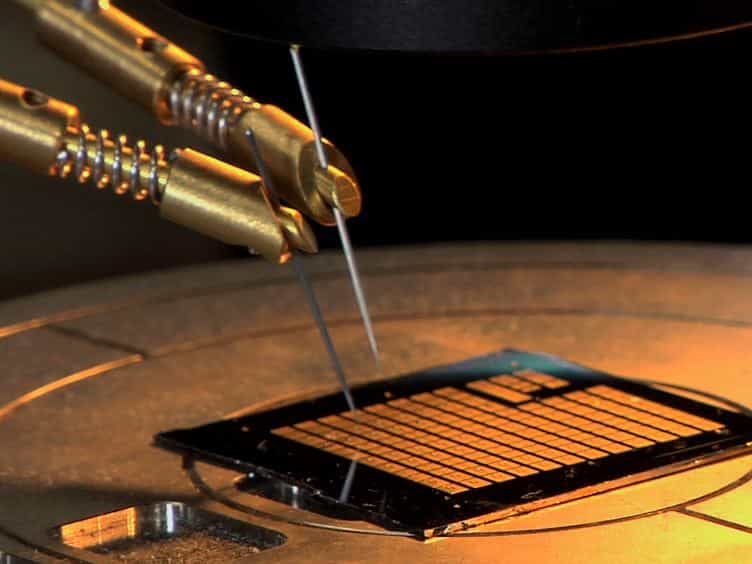

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Event-based sliding mode control for singularly perturbed systems with switching parameters
1School of Data Science and Information Engineering, Guizhou Minzu University, Guizhou 550025, China.

Abstract:
This paper addresses the event-based sliding mode control problem for singularly perturbed systems with switching parameters. Unlike traditional Markovian switching systems, singularly perturbed S-MSSs allow more flexible state transitions, which can be described by a general distribution rather than the exponential distribution assumed in Markovian switching systems. To enhance the performance of such systems, a novel memory-based dynamic event-triggered protocol (DETP) is proposed, incorporating a memory term for the auxiliary offset variable. This approach reduces the frequency of communication packets, leading to more efficient transmission scheduling. The proposed memory-based DETP distinguishes itself by utilizing both the memory term and the singular perturbation parameter, effectively mitigating communication overhead while maintaining control performance. In addition, an innovative integral-type sliding surface is constructed, and a hidden semi-Markovian switching model is employed to address mode mismatches between the original system and the sliding mode control law. Using parameter-dependent Lyapunov theory, several sufficient conditions are derived to guarantee the exponential mode stability under bounded disturbances (EMSUB) behavior of the sliding mode dynamics. Finally, the effectiveness of the proposed control strategy is demonstrated through two simulation examples.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Multi-input and Multi-variable systems
In the absence...