Related Experiment Video
Updated: Jun 3, 2025

Visually Based Characterization of the Incipient Particle Motion in Regular Substrates: From Laminar to Turbulent Conditions
Published on: February 22, 2018
The topology of a chaotic attractor in the Kuramoto-Sivashinsky equation
Marie Abadie1, Pierre Beck2, Jeremy P Parker3
1Department of Mathematics, University of Luxembourg, 6, Av. de la Fonte, 4364 Esch-sur-Alzette, Luxembourg.

Abstract:
The Birman-Williams theorem gives a connection between the collection of unstable periodic orbits (UPOs) contained within a chaotic attractor and the topology of that attractor, for three-dimensional systems. In certain cases, the fractal dimension of a chaotic attractor in a partial differential equation (PDE) is less than three, even though that attractor is embedded within an infinite-dimensional space. Here, we study the Kuramoto-Sivashinsky PDE at the onset of chaos. We use two different dimensionality-reduction techniques-proper orthogonal decomposition and an autoencoder neural network-to find two different mappings of the chaotic attractor into three dimensions. By finding the image of the attractor's UPOs in these reduced spaces and examining their linking numbers, we construct templates for the branched manifold, which encodes the topological properties of the attractor. The templates obtained using two different dimensionality reduction methods are equivalent. The organization of the periodic orbits is identical and consistent symbolic sequences for low-period UPOs are derived. While this is not a formal mathematical proof, this agreement is strong evidence that the dimensional reduction is robust, in this case, and that an accurate topological characterization of the chaotic attractor of the chaotic PDE has been achieved.
Related Concept Videos
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:28
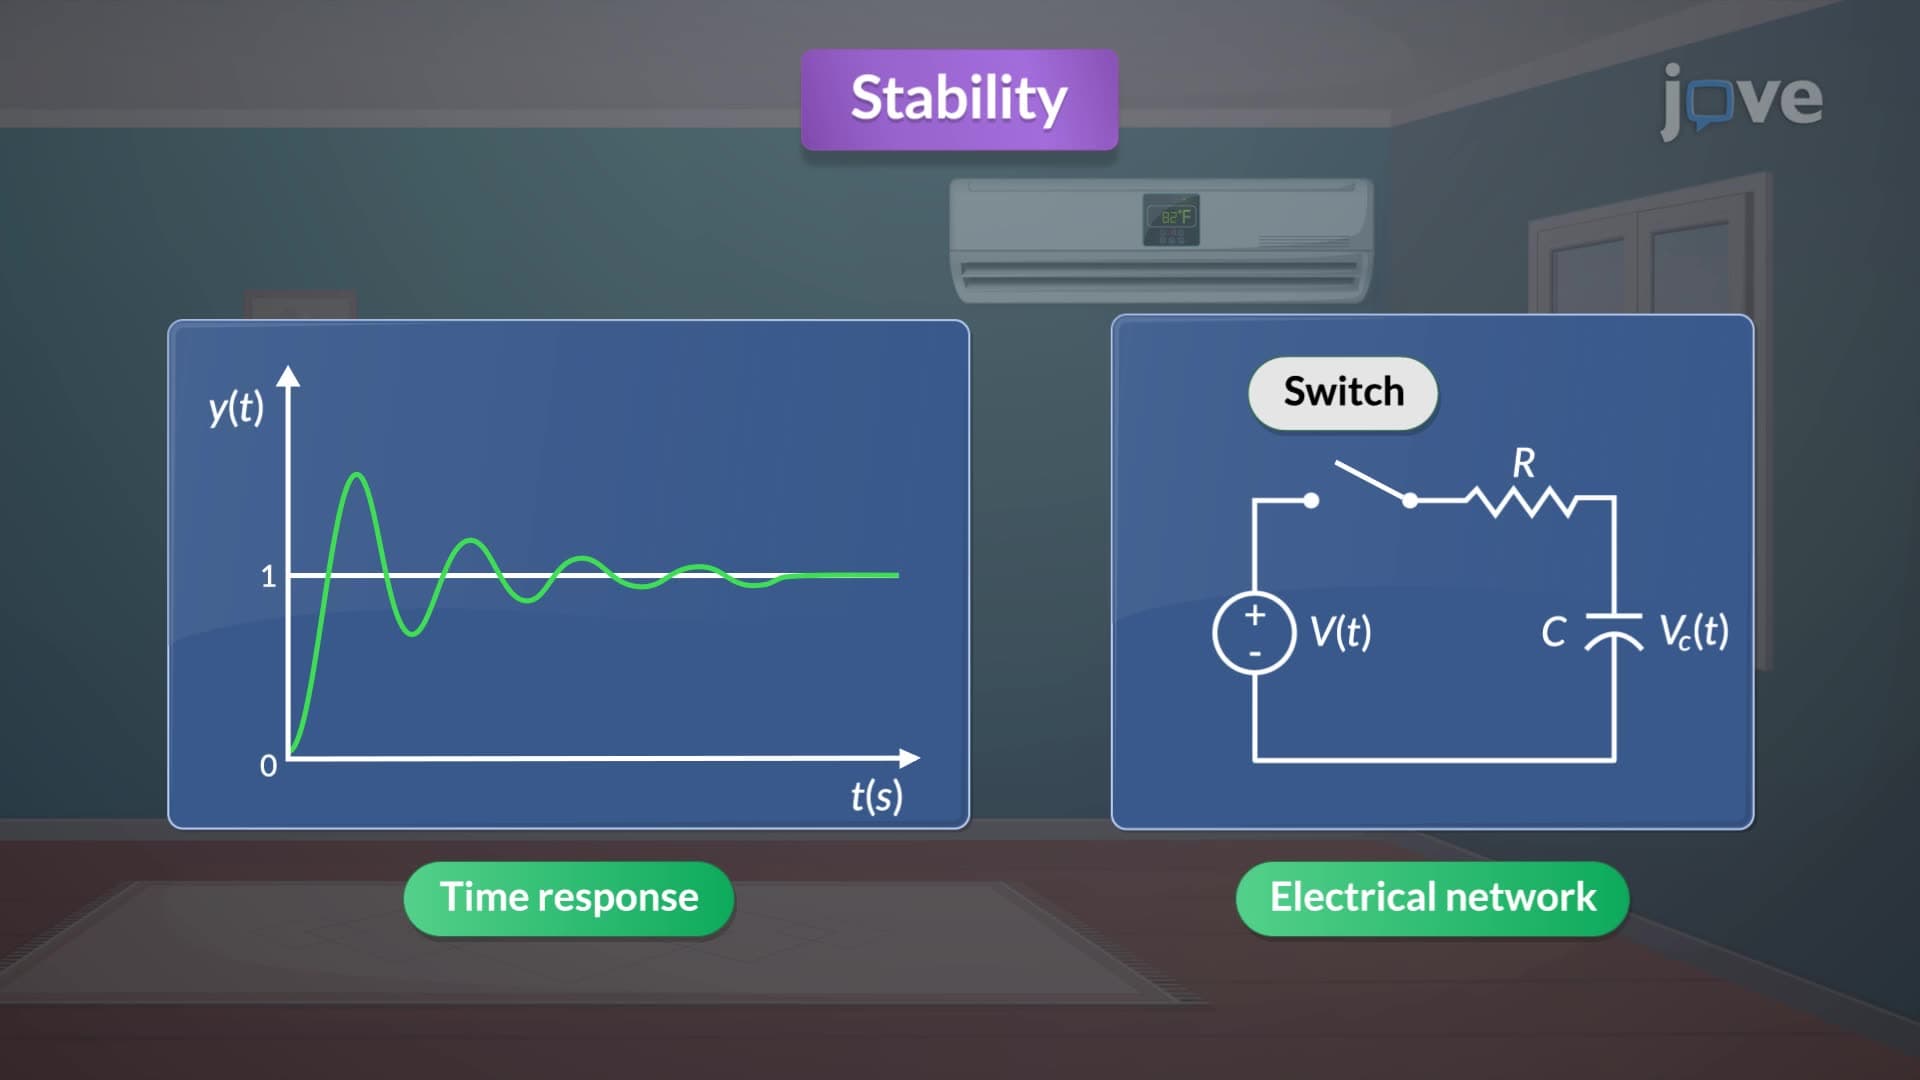
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:19
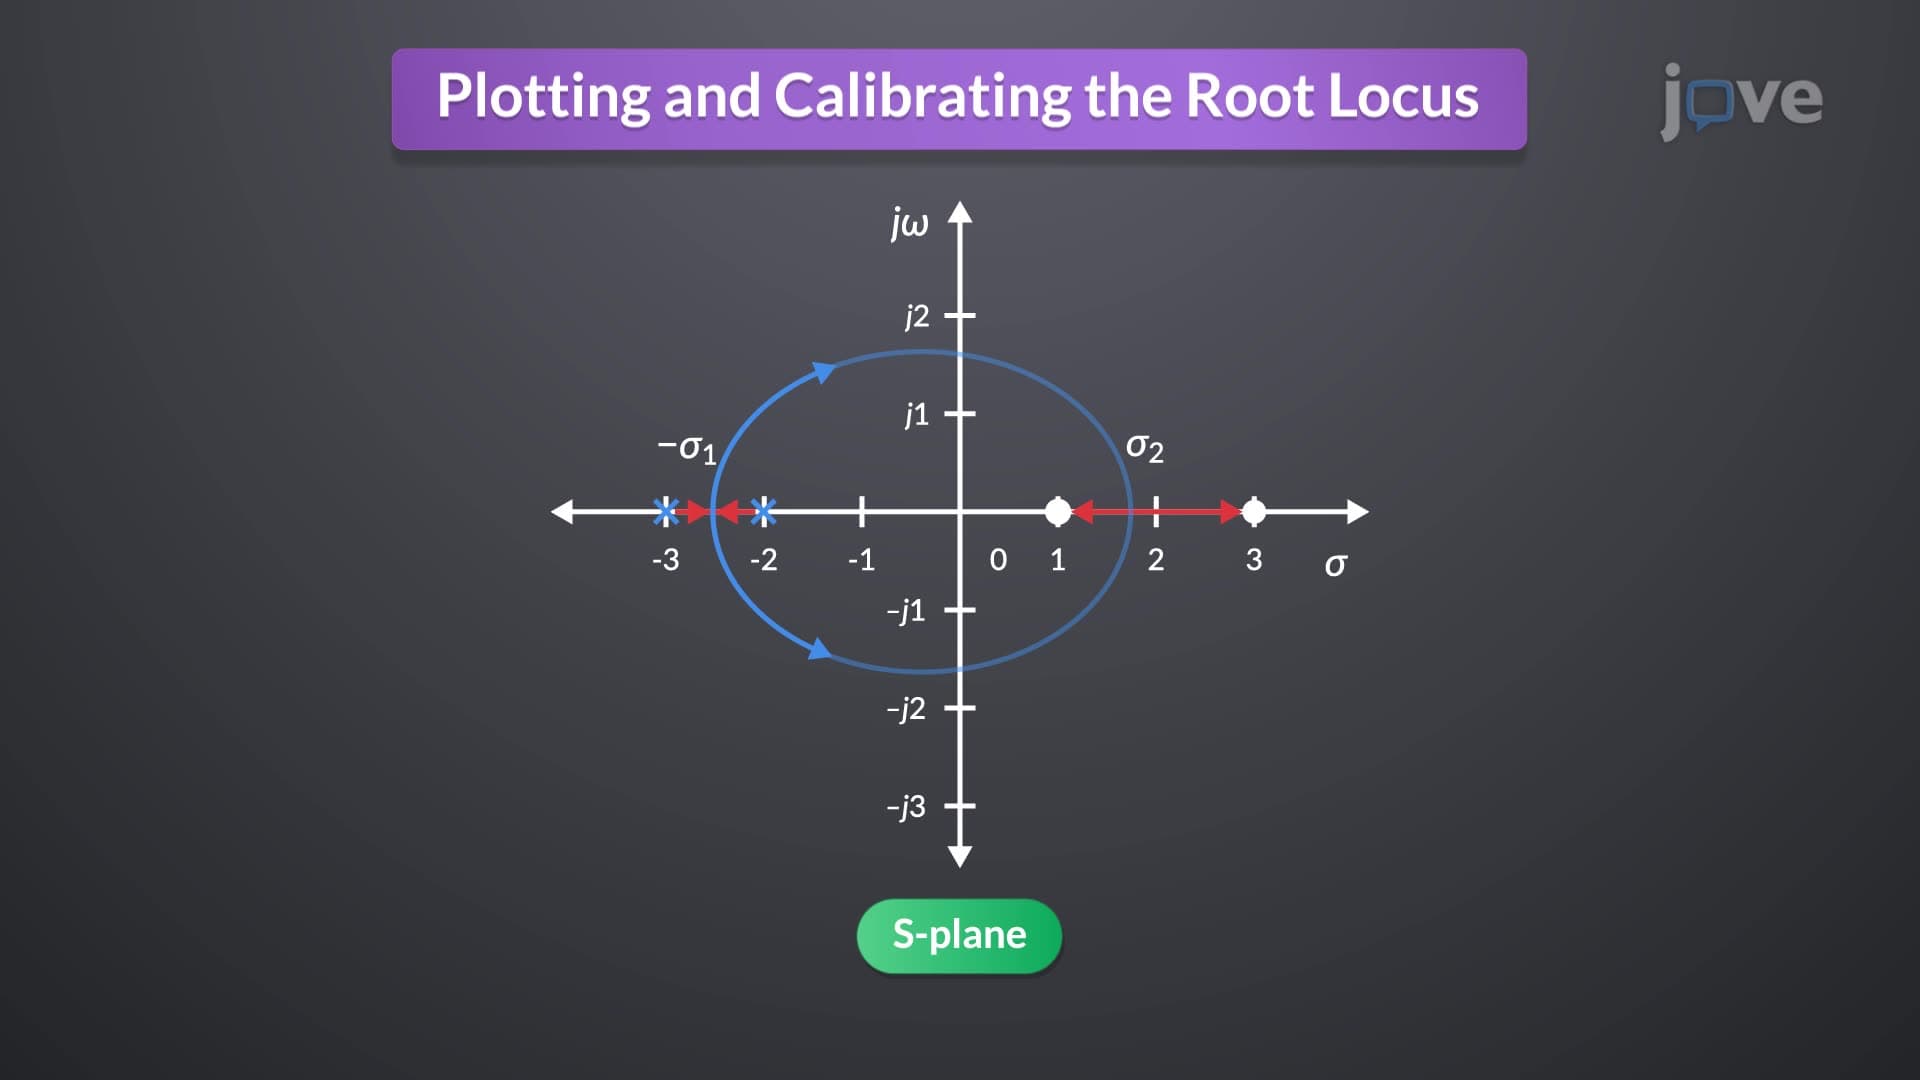
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....