Related Experiment Video
Updated: Jun 2, 2025
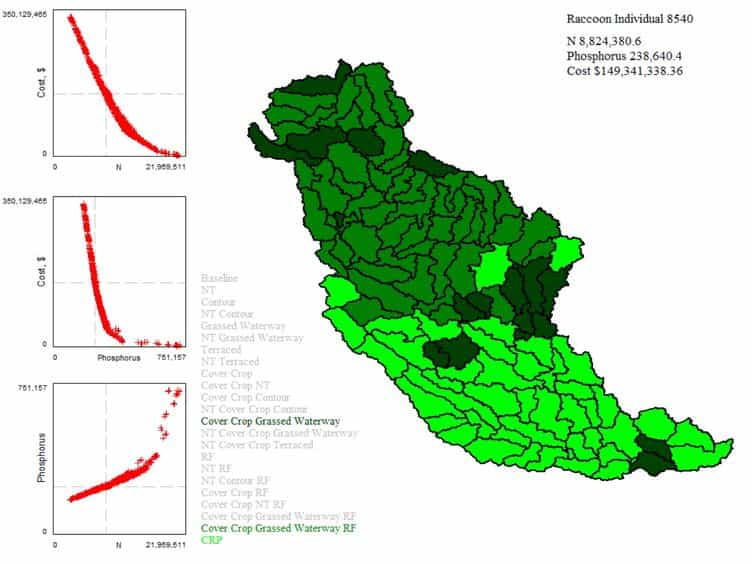

Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
A spherical vector-based adaptive evolutionary particle swarm optimization for UAV path planning under threat
Yanfei Liu1, Hao Zhang2, Hao Zheng1
1Department of Basic Courses, Xi'an Research Institute of Hi-Tech, Xi'an, 710025, China.

Abstract:
Unmanned aerial vehicle (UAV) path planning is a constrained multi-objective optimization problem. With the increasing scale of UAV applications, finding an efficient and safe path in complex real-world environments is crucial. However, existing particle swarm optimization (PSO) algorithms struggle with these problems as they fail to consider UAV dynamics, resulting in many infeasible solutions and poor convergence to optimal solutions. To address these challenges, we propose a spherical vector-based adaptive evolutionary particle swarm optimization (SAEPSO) algorithm. This algorithm, based on spherical vectors, directly incorporates UAV dynamic constraints and introduces improved tent map and reverse learning to enhance the diversity and distribution of initial solutions. Additionally, dynamic nonlinear and adaptive factors are integrated to balance exploration and exploitation capabilities. To avoid local optima in highly complex environments, we propose an adaptive acceleration strategy for poor particles, and an evolutionary programming strategy is incorporated to further improve the optimization capability. Finally, we conducted comparative studies and in six benchmark scenarios with varying threat levels, and the results demonstrated that the proposed algorithm outperforms others in the initial solution effectiveness, the final solution accuracy, convergence stability, and scalability.
More Related Videos

Related Concept Videos
 01:16
Circular Orbits and Critical Velocity for Satellites
Nicolaus Copernicus (1473-1543) first suggested that the Earth and all other planets orbit the Sun in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...