Related Experiment Video
Updated: Jun 2, 2025
Origami Inspired Self-assembly of Patterned and Reconfigurable Particles
Published on: February 4, 2013
Tri-Prism Origami Enabled Soft Modular Actuator for Reconfigurable Robots
Shuang Gao1, Jun Zhang2, Rong Zhang3
1Shanghai Key Laboratory of Intelligent Manufacturing and Robotics, School of Mechatronic Engineering and Automation, Shanghai University, Shanghai, China.

Abstract:
Soft actuators hold great potential for applications in surgical operations, robotic manipulation, and prosthetic devices. However, they are limited by their structures, materials, and actuation methods, resulting in disadvantages in output force and dynamic response. This article introduces a soft pneumatic actuator capable of bending based on triangular prism origami. The origami creases are crafted by utilizing fabrics to gain swift response and fatigue-resistant properties. By connecting two actuators in series, combined motions including extension and diversified compound bending can be achieved, facilitating control in complex scenarios. After modularizing the soft actuator via mortise and tenon structures, several actuators can be programmed to execute a variety of intricate tasks by adjusting the timing sequences of their contraction and expansion. We showcase its applications in reconfigurable robots, and the results confirm that such a design is adequate for flexibly performing tasks such as soft gripping, navigational movement, and obstacle avoidance. These findings highlight the significance of our actuator in developing soft robots for versatile tasks.

Related Concept Videos
 01:30
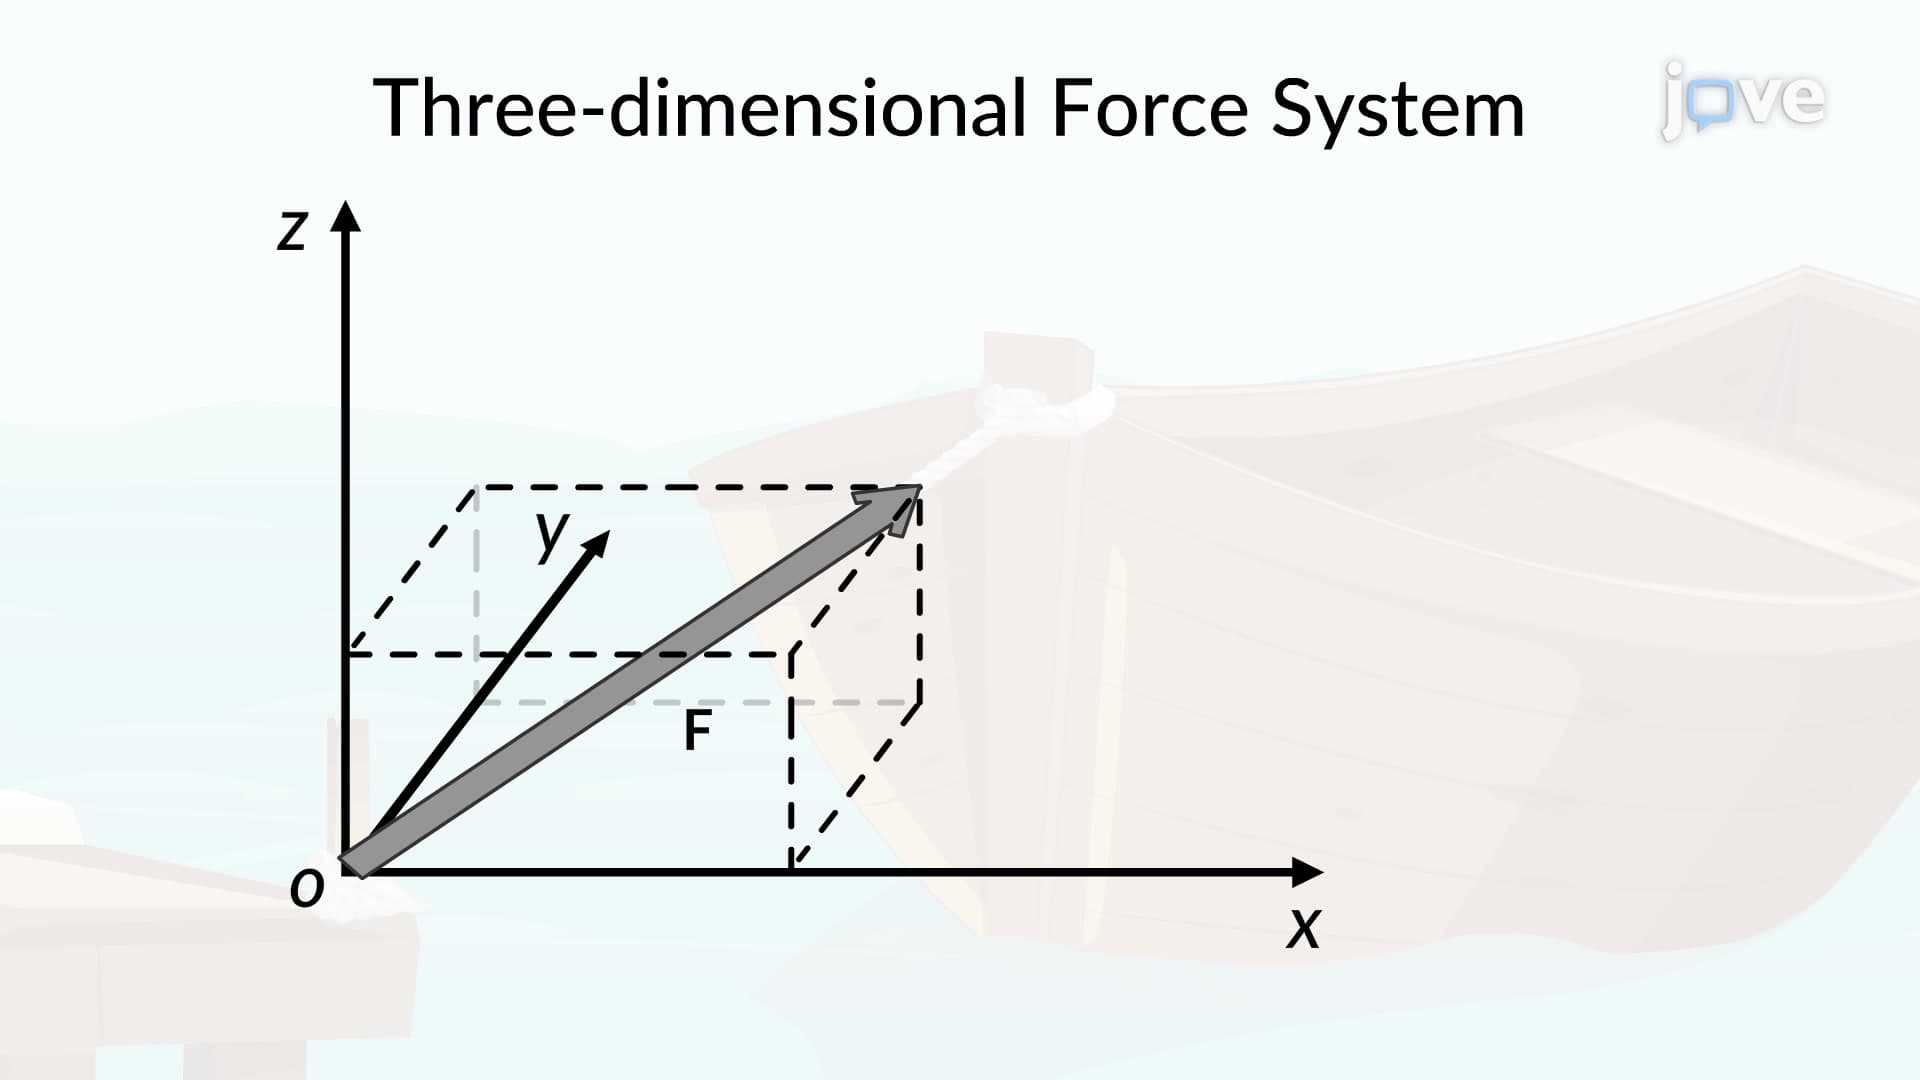
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:22
Mechanical Systems
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:15
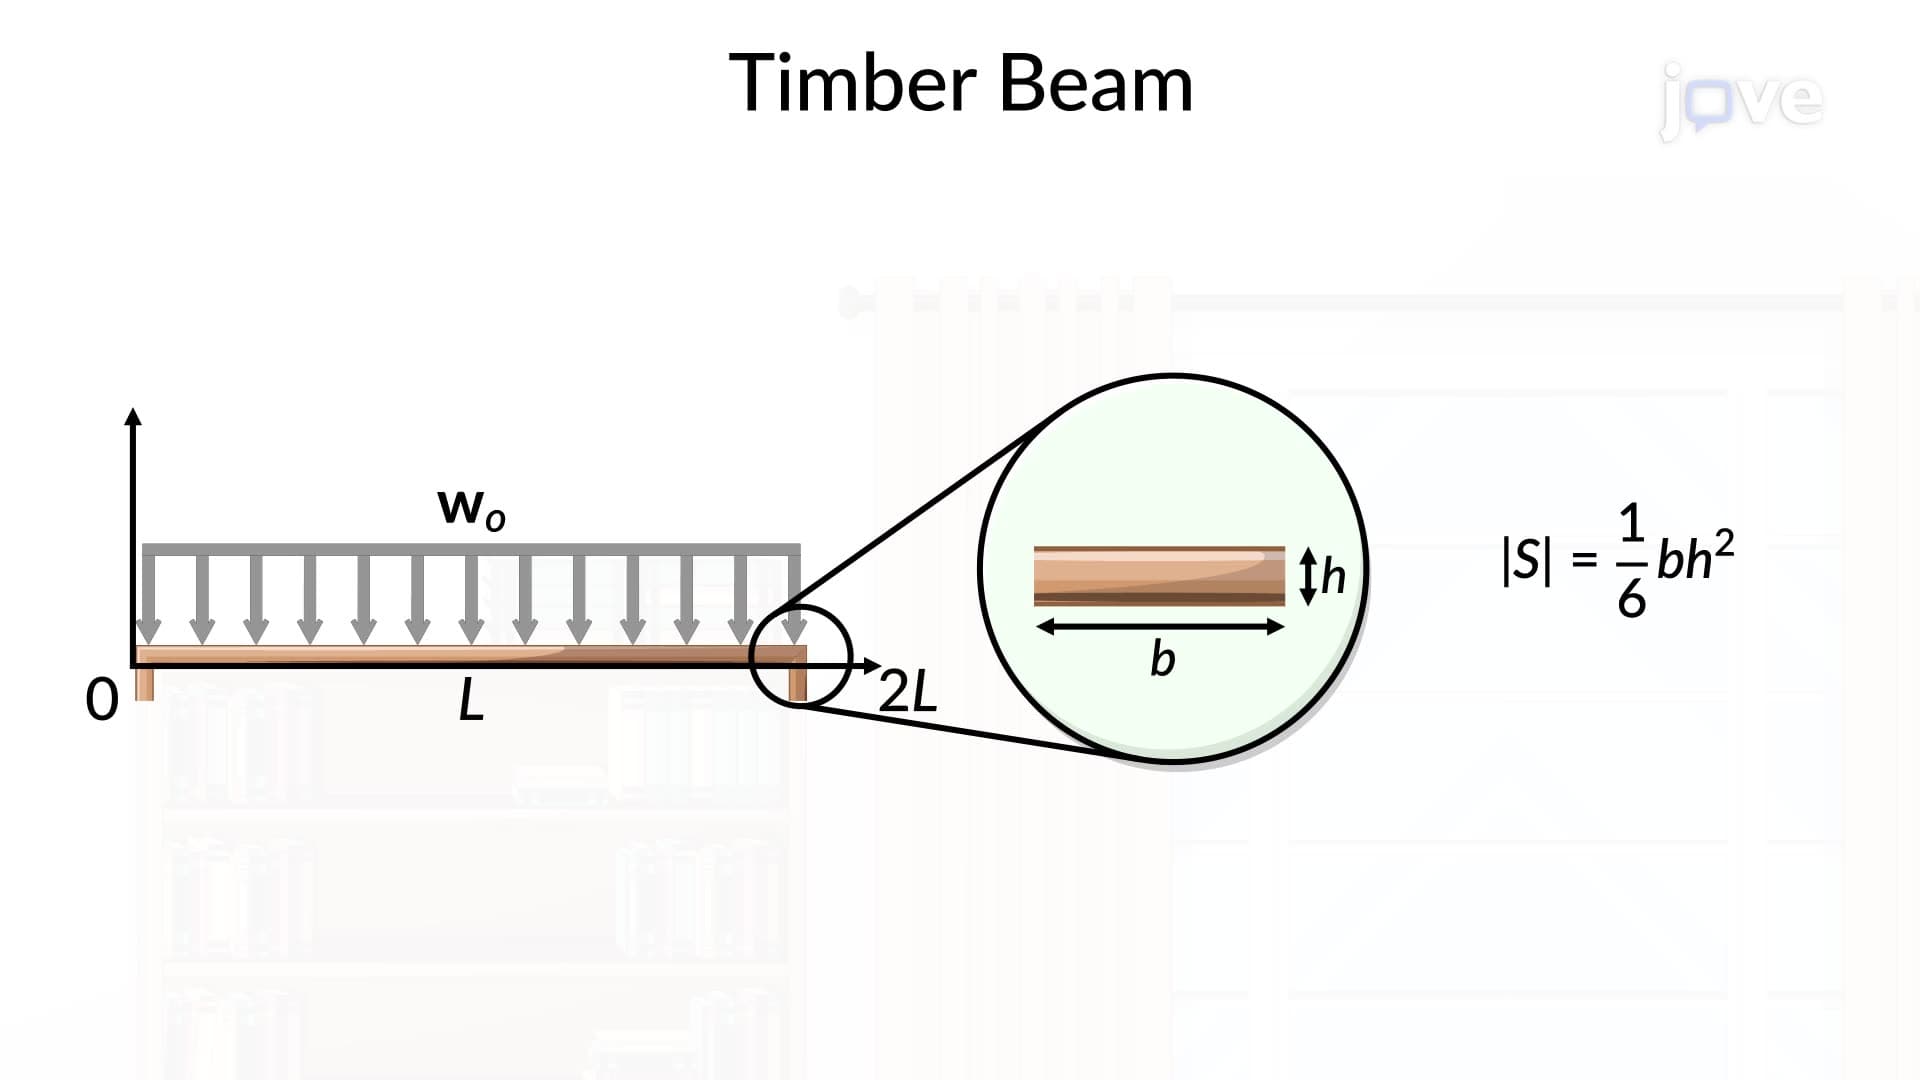
Prismatic Beams: Problem Solving
The design begins with analyzing the beam as a free body to identify moments and force balances, thereby determining support reactions. Next, the...
 01:23
Design of Prismatic Beams for Bending