Related Experiment Video
Updated: Jun 1, 2025
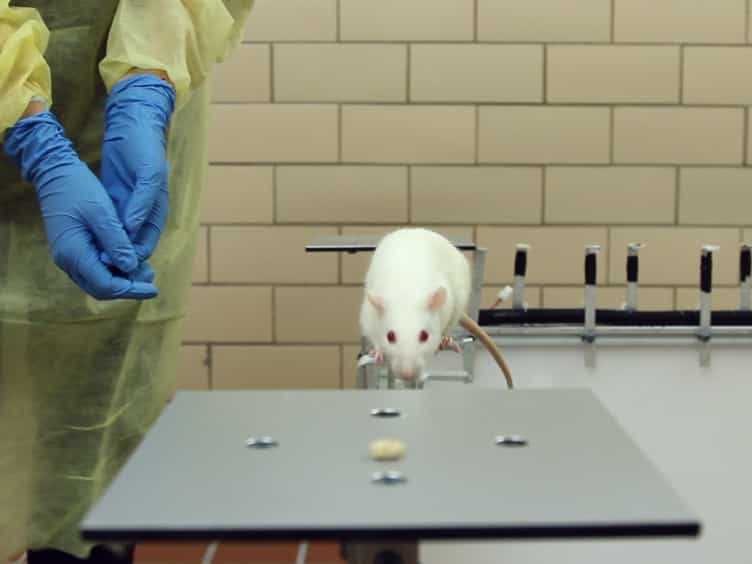
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Bicycle-inspired simple balance control method for quadruped robots in high-speed running
Shoei Hattori1,2,3,4, Shura Suzuki2, Akira Fukuhara2
1Division for Interdisciplinary Advanced Research and Education, Tohoku University, Sendai, Japan.

Abstract:
This paper explores the applicability of bicycle-inspired balance control in a quadruped robot model. Bicycles maintain stability and change direction by intuitively steering the handle, which induces yaw motion in the body frame and generates an inertial effect to support balance. Inspired by this balancing strategy, we implemented a similar mechanism in a quadruped robot model, introducing a yaw trunk joint analogous to a bicycle's steering handle. Simulation results demonstrate that the proposed model achieves stable high-speed locomotion with robustness against external disturbances and maneuverability that allows directional changes with only slight speed reduction. These findings suggest that utilizing centrifugal force plays a critical role in agile locomotion, aligning with the movement strategies of cursorial animals. This study underscores the potential of bicycle balance control as an effective and straightforward control approach for enhancing the agility and stability of quadruped robots as well as potentially offering insights into animal motor control mechanisms for agile locomotion.
More Related Videos
 07:51
An Innovative Running Wheel-based Mechanism for Improved Rat Training Performance
Published on: September 19, 2016
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
