Related Experiment Video
Updated: May 31, 2025


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Coordinated human-exoskeleton locomotion emerges from regulating virtual energy
Rezvan Nasiri1, Hannah Dinovitzer1, Nirosh Manohara1
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, Waterloo, ON, Canada.

Abstract:
Lower-limb exoskeletons have demonstrated great potential for gait rehabilitation in individuals with motor impairments; however, maintaining human-exoskeleton coordination remains a challenge. The coordination problem, referred to as any mismatch or asynchrony between the user's intended trajectories and exoskeleton desired trajectories, leads to sub-optimal gait performance, particularly for individuals with residual motor ability. Here, we investigate the virtual energy regulator (VER)'s ability to generate coordinated locomotion in lower limb exoskeleton. Contribution: (1) In this paper, we experimented VER on a group of nine healthy individuals at different speeds (0.6m/s - 0.85m/s) to study the resultant gait coordination and naturalness on a large group of users. (2) The resultant assisted gait is compared to the natural and passive (zero-torque exoskeleton) walking conditions in terms of muscle activities, kinematic, spatiotemporal and kinetic measures, and questionnaires. (3) Moreover, we presented the VER's convergence proof considering the user contribution to the gait and introduced a metric to measure the user's contribution to gait. (4) We also compared VER performance with the phase-based path controller in terms of muscle effort reduction and joint kinematics using three able-bodied individuals. Results: (1) The results from the VER demonstrate the emergence of natural, coordinated locomotion, resulting in an average muscle effort reduction ranging from 13.1% to 17.7% at different speeds compared to passive walking. (2) The results from VER revealed improvements in all indicators towards natural gait when compared to walking with a zero-torque exoskeleton, for instance, an enhancement in average knee extension ranging from 3.9 to 4.1 degrees. All indicators suggest that the VER preserves natural gait variability and user engagement in locomotion control. (3) Using VER also yields in 13.9%, 15.1%, and 7.0% average muscle effort reduction when compared to the phase-based path controller. (4) Finally, using our proposed metric, we demonstrated that the resultant locomotion limit cycle is a linear combination of human-intended limit cycle and the VER's limit cycle. These findings may have implications for understanding how the central nervous system controls our locomotion.
More Related Videos
 07:03
Author Spotlight: Bridging the Gap Between In Vivo and Ex Vivo Studies with the "Avatar" Technique to Advance Muscle Mechanics Research
Published on: August 18, 2023
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Related Concept Videos
 01:10
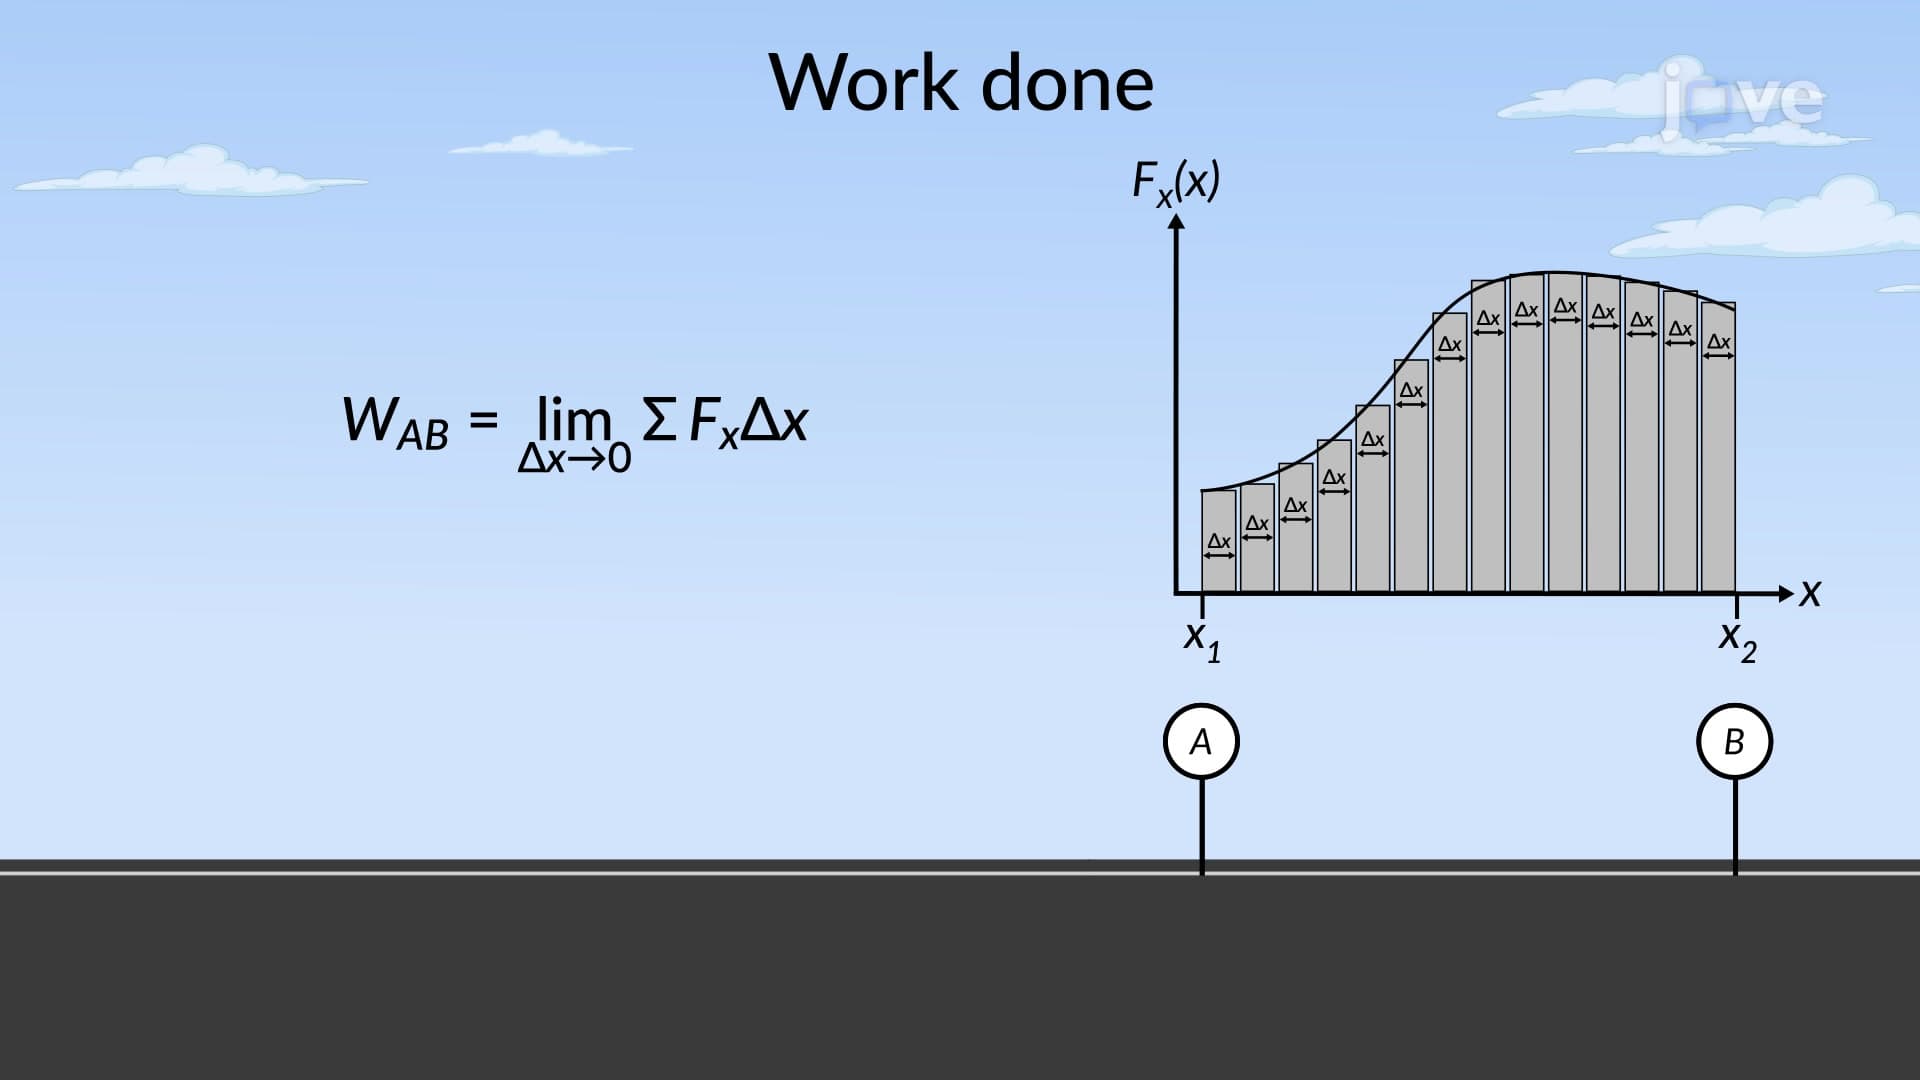
Work and Energy for Variable Forces
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:13
Kinetic Energy for a Rigid Body
 01:25
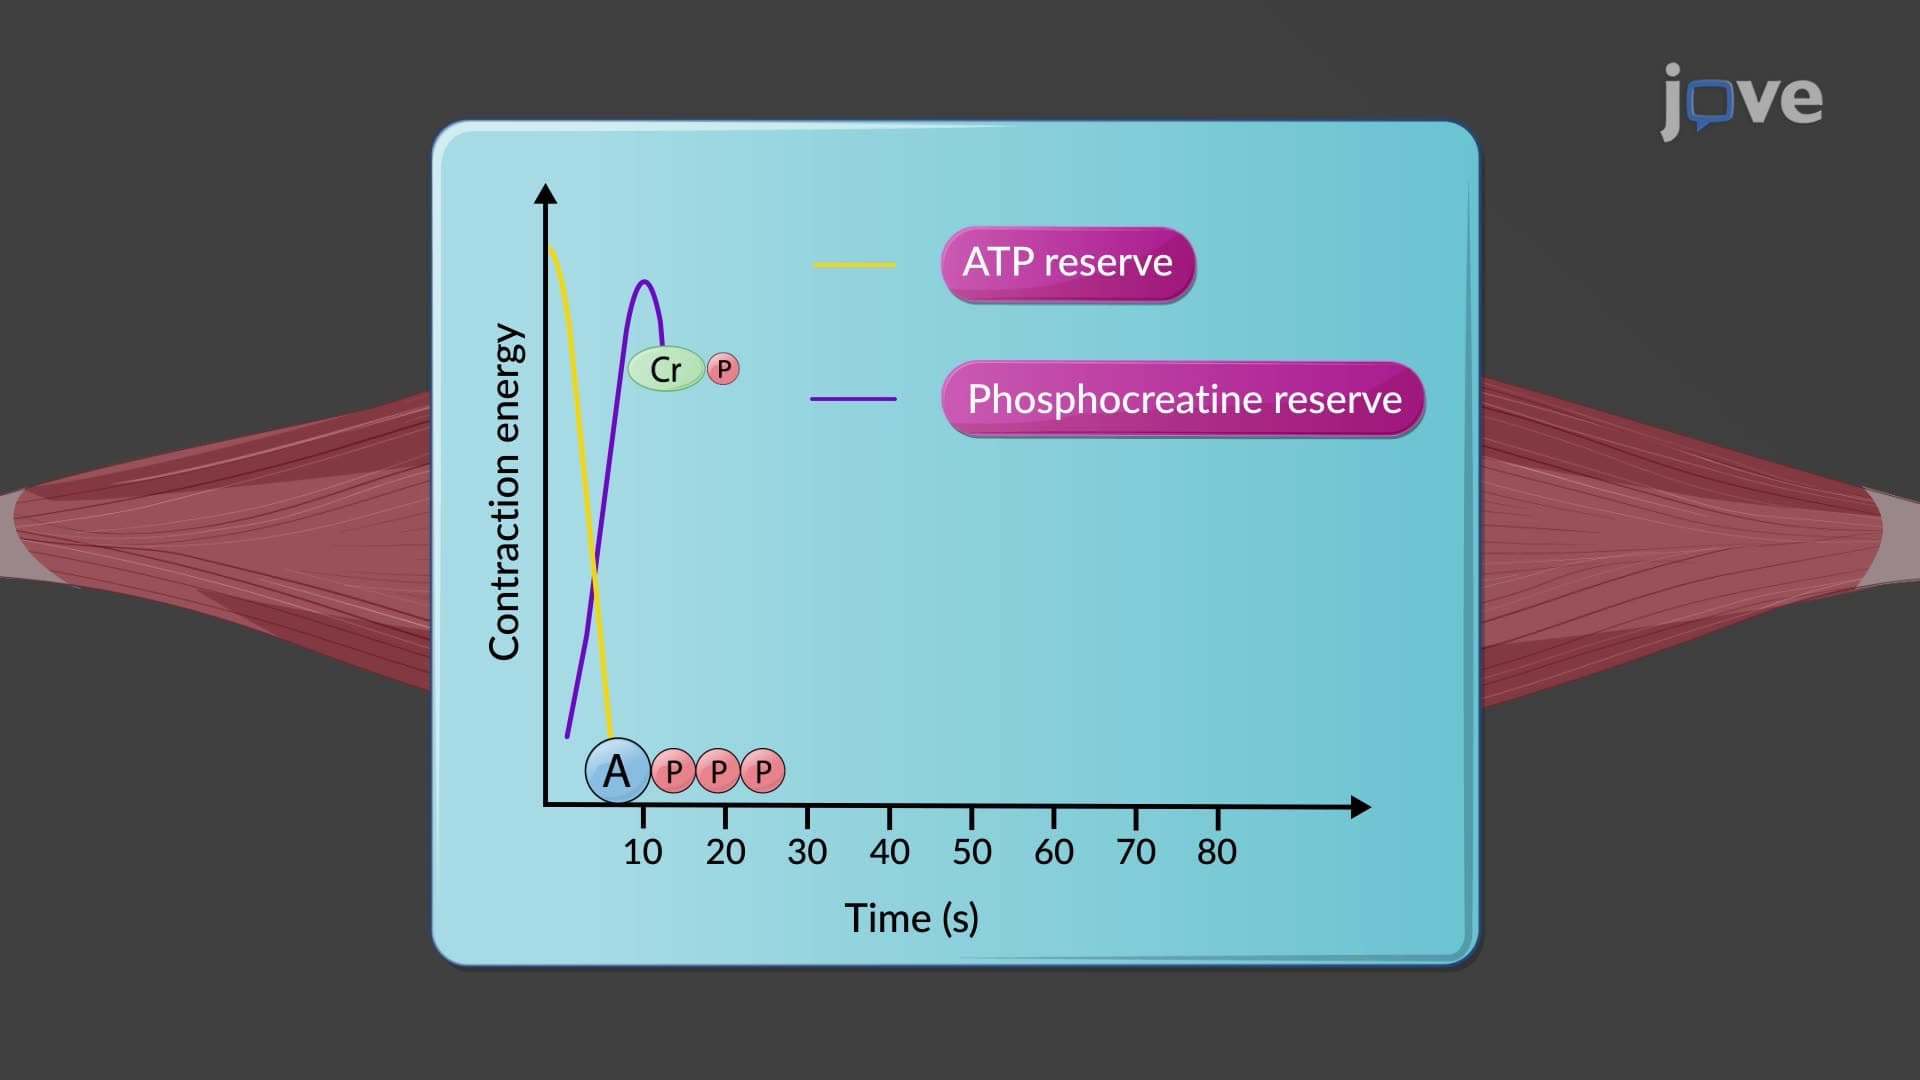
Energy Supply for Muscle Contraction
 01:37
Energy to Drive Translocation
Generally, polypeptides are unfolded by two distinct...
 00:23
Kinetic Energy