Related Experiment Video
Updated: May 28, 2025
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
External torque estimation based P+Damping control for bilateral teleoperation systems
Baorui Jing1, Jing Na1, Hao Duan1
1Faculty of Mechanical & Electrical Engineering, Kunming University of Science & Technology, Kunming, 650500, China; Yunnan Key Laboratory of Intelligent Control and Application, Kunming University of Science & Technology, Kunming, 650500, China.

Abstract:
This paper presents a P+Damping control with gravity compensation for bilateral teleoperation systems, where the effects of time delays can be effectively addressed, and the motion synchronization and the transparency can be guaranteed. To further eliminate the direct measurement of human and environmental torques to save sensor installation space and reduce the hardware cost, a constructive unknown torque estimator is also proposed by tailoring the idea of unknown system dynamics estimator (USDE). This torque estimator with low-pass filter operations eliminates the requirement of joint acceleration and has only one tuning parameter, while it enables accurate estimation of external torques of both the local and remote manipulators. Nevertheless, this USDE-based torque estimator can be incorporated into the P+Damping control to simultaneously enhance transparency during the contact motion and ensure the synchronization of both position and velocity. Rigorous theoretical analyses are carried out to prove the stability and the claimed performances. Finally, the effectiveness of the proposed methods is demonstrated through simulation and experimental results.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
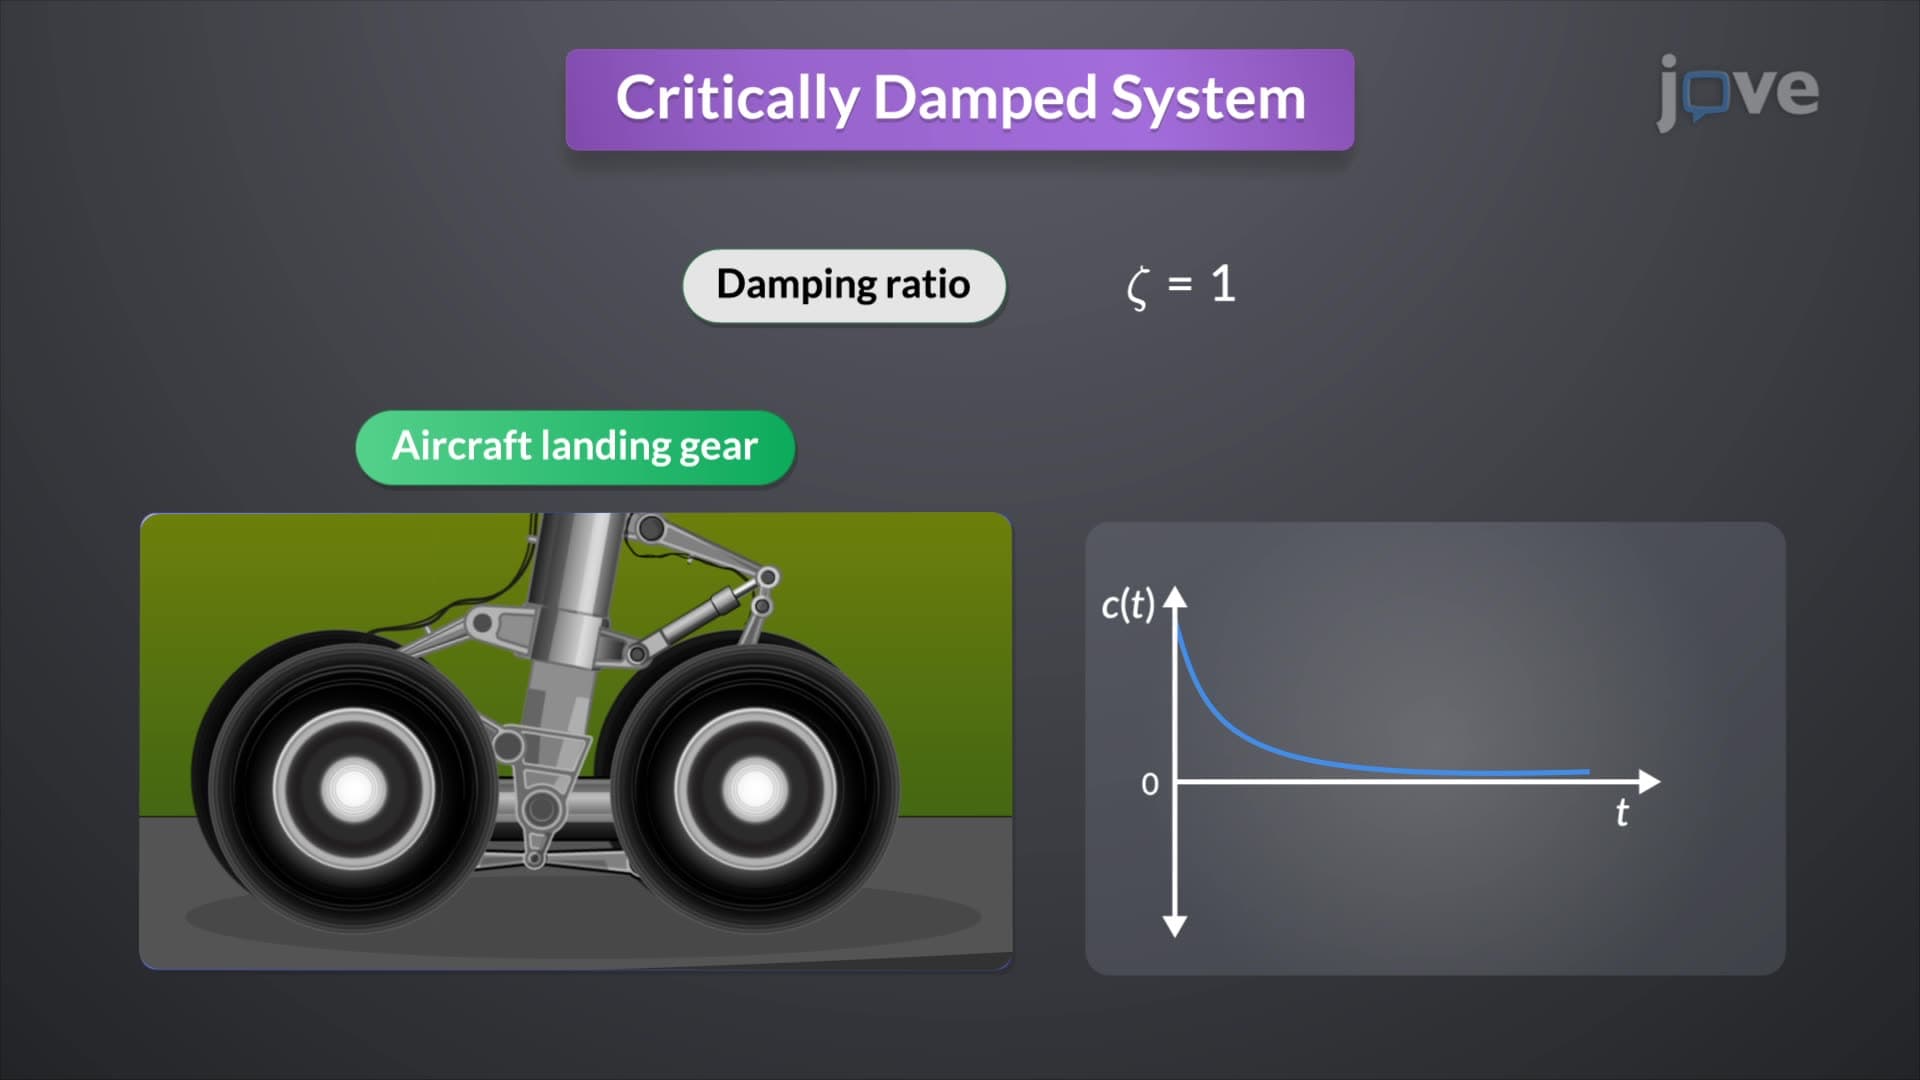 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
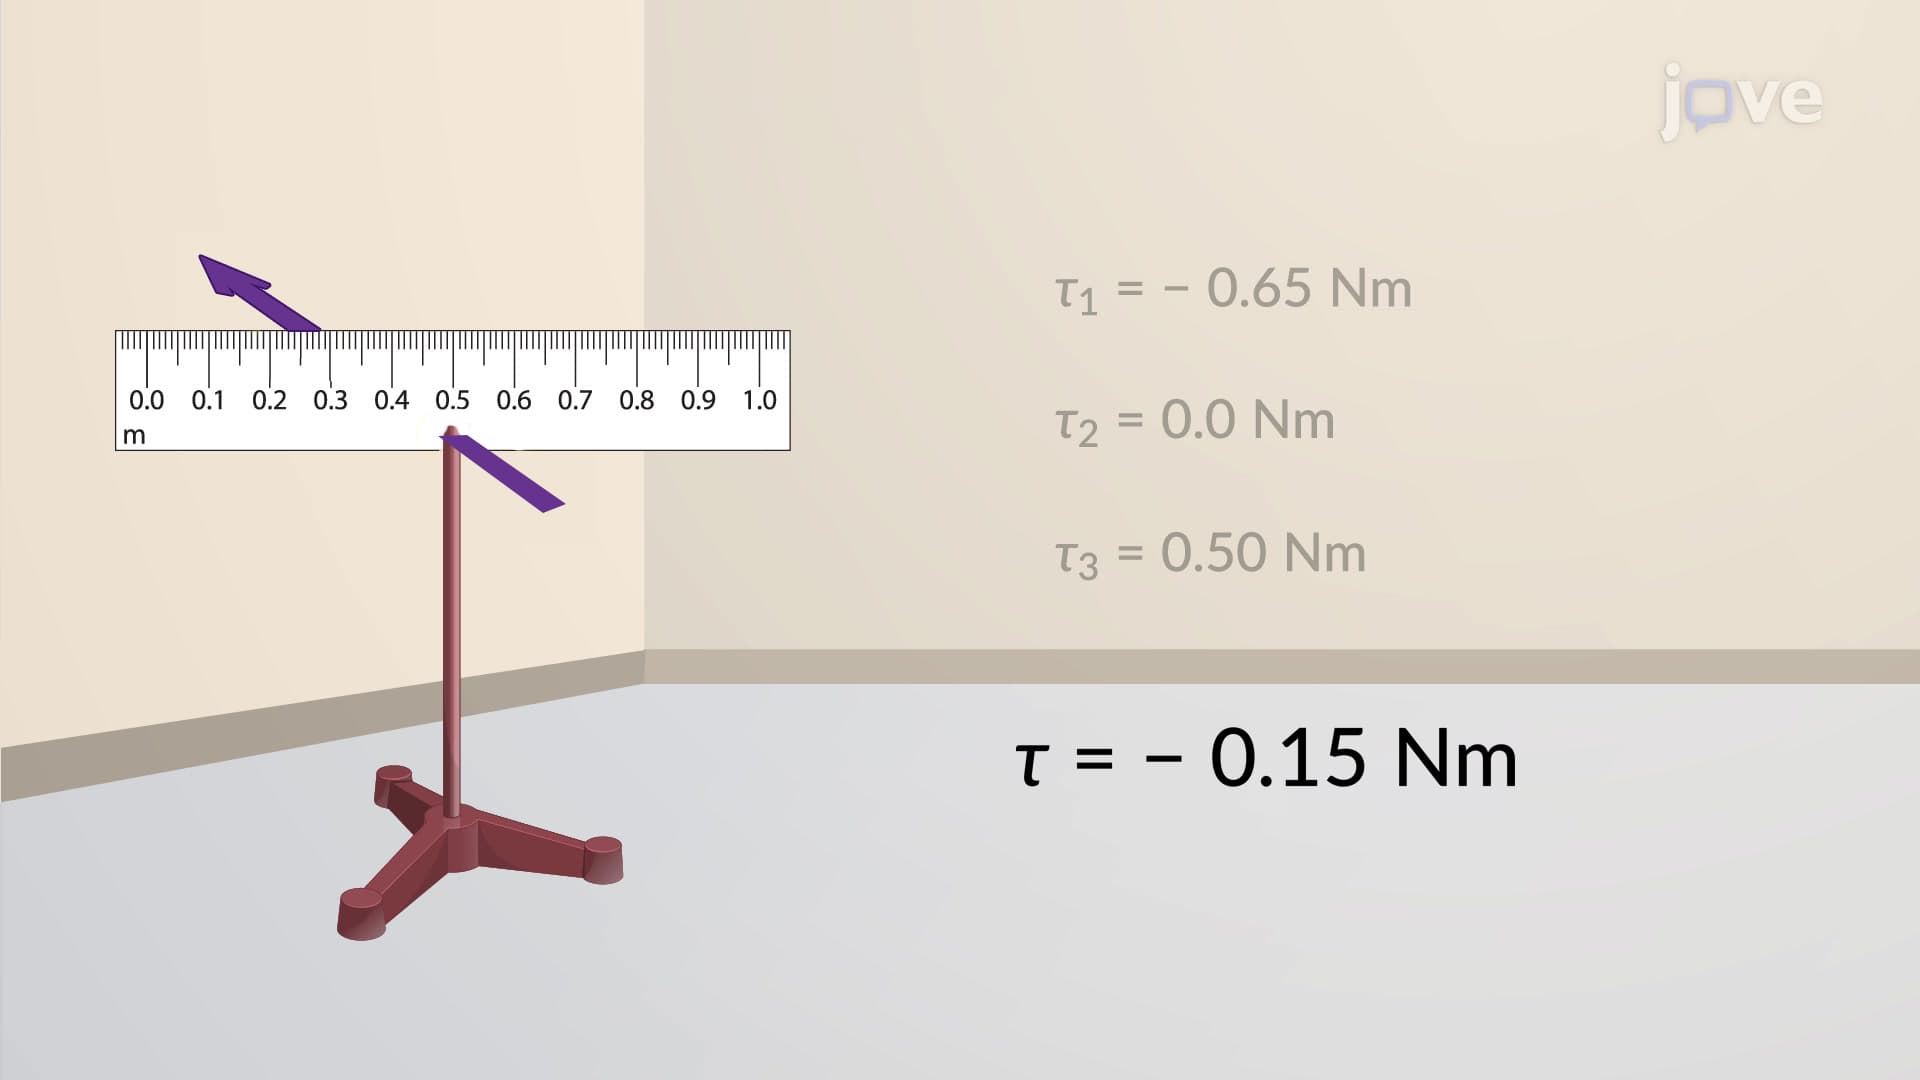 01:19
Net Torque Calculations
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...