Related Experiment Video
Updated: May 27, 2025

Continuous Measurement of Biological Noise in Escherichia Coli Using Time-lapse Microscopy
Published on: April 27, 2021
Colored stochastic multiplicative processes with additive noise unveil a third-order partial differential equation,
Marco Bianucci1, Mauro Bologna2, Riccardo Mannella3
1Istituto di Scienze Marine, Consiglio Nazionale delle Ricerche (ISMAR - CNR), 19032 Lerici (SP), Italy.

Abstract:
Research on stochastic differential equations (SDEs) involving both additive and multiplicative noise has been extensive. In cases where the primary process is driven by a multiplicative stochastic process, additive white noise typically represents an intrinsic and unavoidable fast component. This applies to phenomena such as thermal fluctuations, inherent uncertainties in measurement processes, or rapid wind forcing in ocean dynamics. In this paper, we focus on an important class of such systems, particularly those characterized by linear drift and multiplicative noise, which have been extensively explored in the literature. In many existing studies, multiplicative stochastic processes are often treated as white noise. However, when considering colored multiplicative noise, the emphasis has usually been on characterizing the far tails of the probability density function (PDF), irrespective of the spectral properties of the noise. In the absence of additive noise and with a general colored multiplicative SDE, standard perturbation approaches lead to a second-order partial differential equation (PDE) known as the Fokker-Planck equation (FPE), consistent with Fick's law. In this paper, we reveal a significant deviation from this standard behavior when additive white noise is introduced. At the leading order of the stochastic process strength, perturbation approaches yield a third-order PDE, regardless of the white noise intensity. The breakdown of the FPE further indicates the breakdown of Fick's law. Additionally, we derive the explicit solution for the equilibrium PDF corresponding to this third-order PDE master equation. Through numerical simulations, we demonstrate significant deviations from results obtained using the FPE derived from Fick's law.
Related Concept Videos
 01:18
Second Order systems II
 01:19
Second-order Op Amp Circuits
The analysis of such circuits follows a systematic approach, similar to the second-order RLC circuits. In practical scenarios, bulky inductors are rarely employed due to their size and weight. This means...
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:20
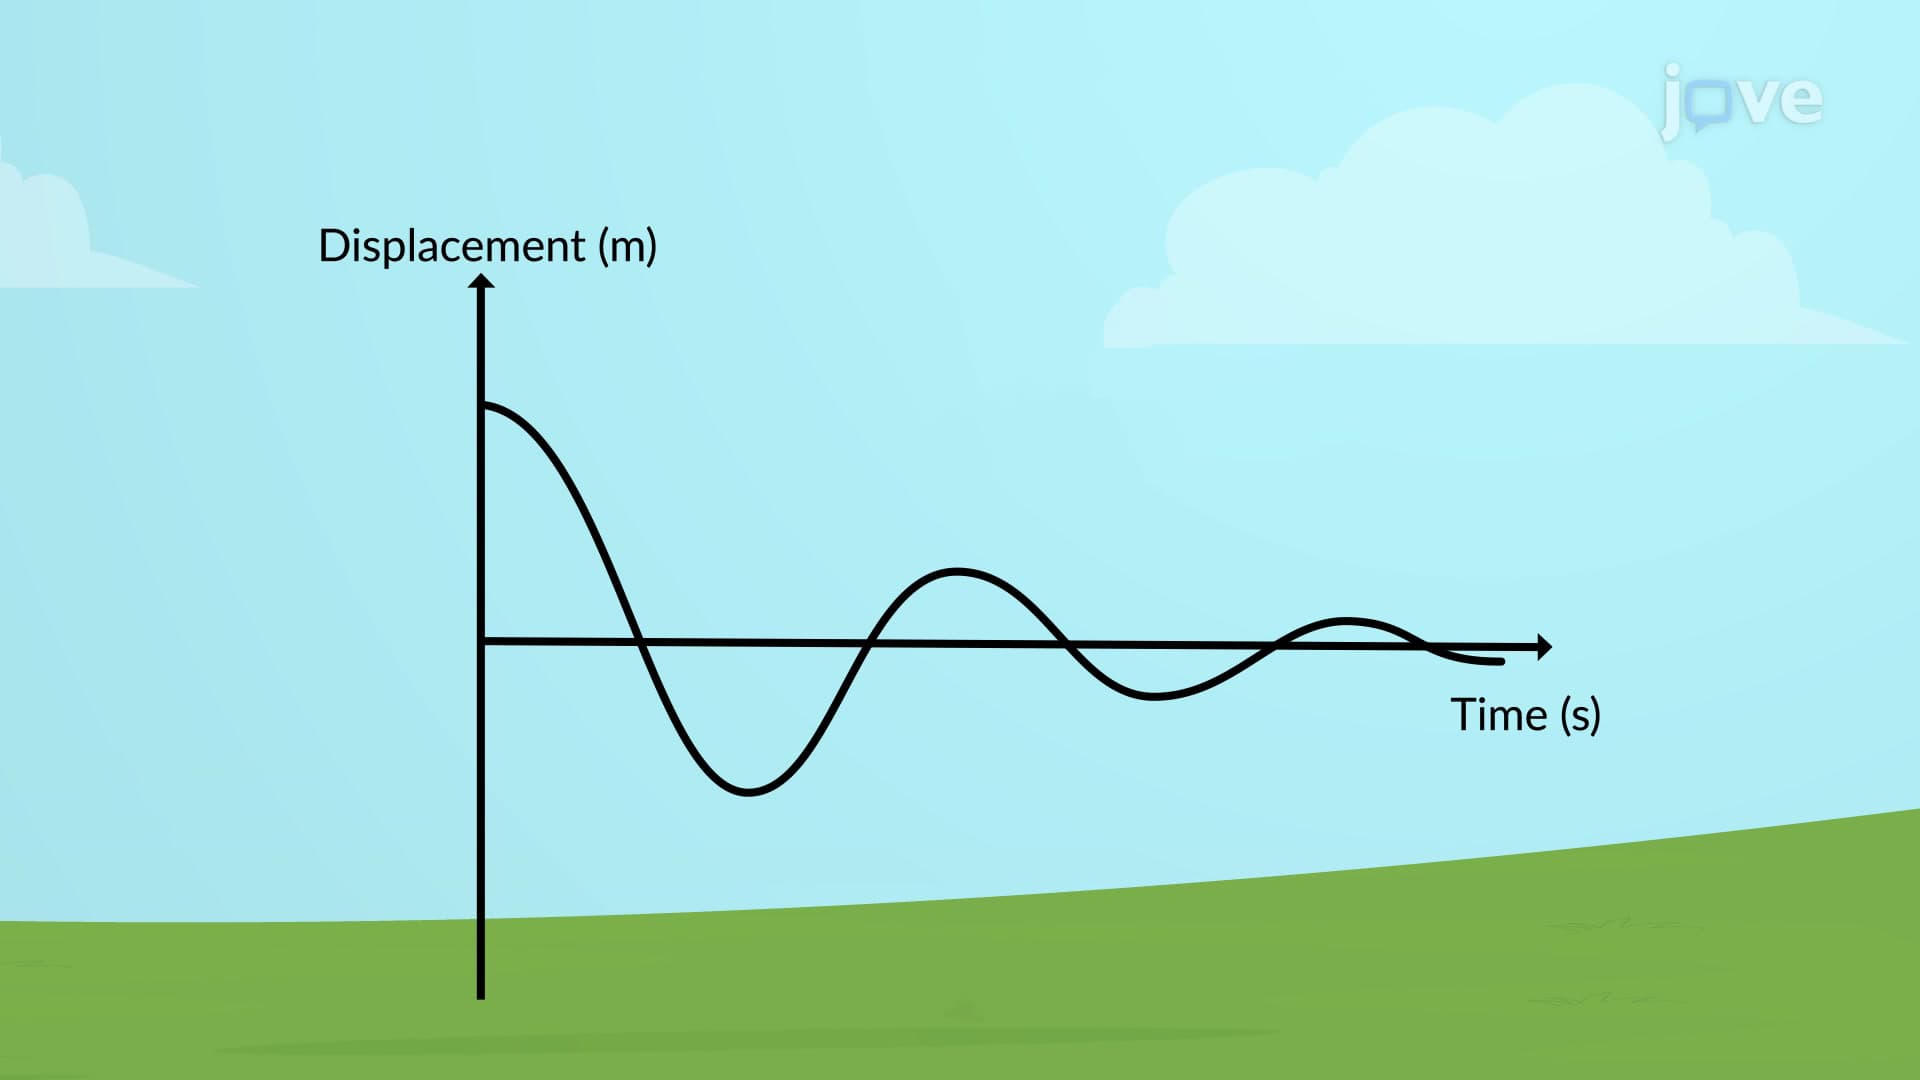
Types of Damping
 01:20
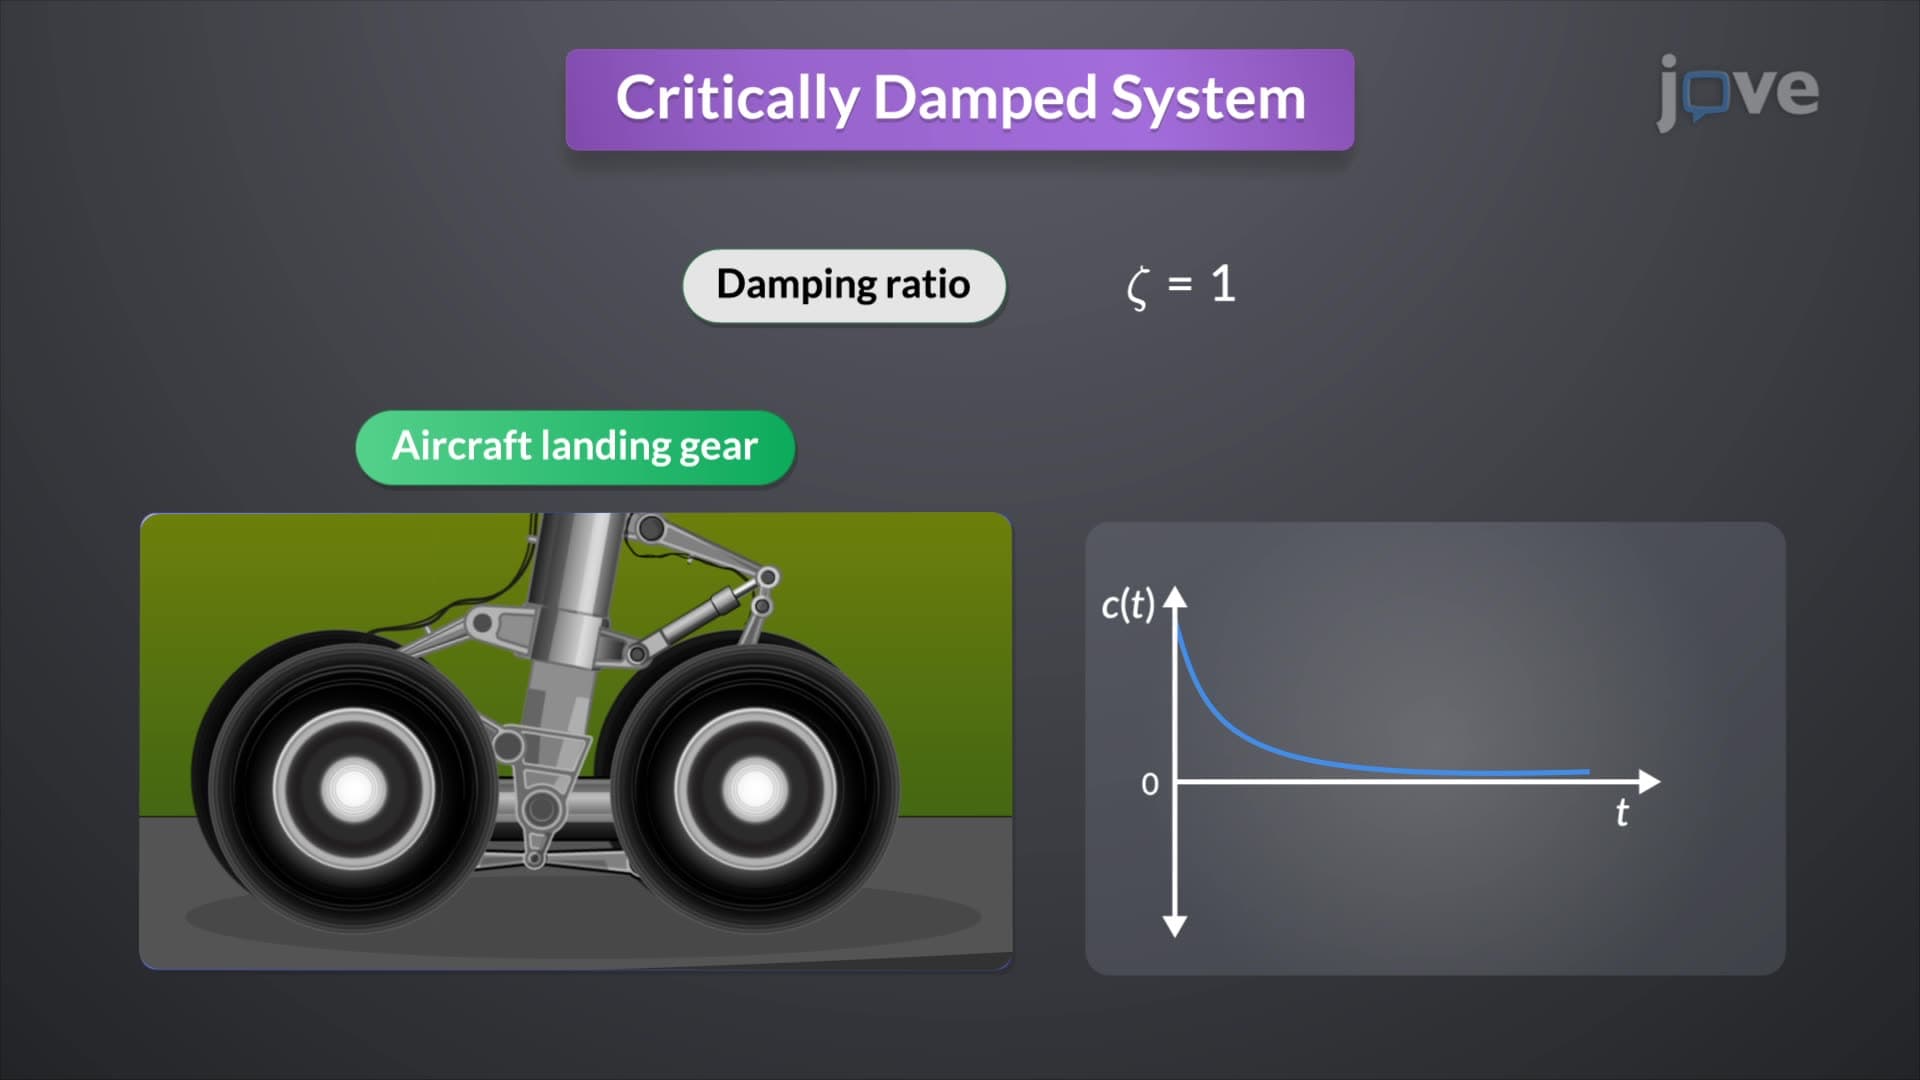
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...