Related Experiment Video
Updated: May 27, 2025


Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
Development of a battery free, solar powered, and energy aware fixed wing unmanned aerial vehicle
Jackson Liller1,2, Rishabh Goel3, Abdul Aziz2
1Department of Computer Science and Engineering, University of Texas at Arlington, Arlington, TX, USA.

Abstract:
Unmanned Aerial Vehicles (UAVs) hold immense potential across various fields, including precision agriculture, rescue missions, delivery services, weather monitoring, and many more. Despite this promise, the limited flight duration of the current UAVs stands as a significant obstacle to their broadscale deployment. Attempting to extend flight time by solar panel charging during midflight is not viable due to battery limitations and the eventual need for replacement. This paper details our investigation of a battery-free fixed-wing UAV, built from cost-effective off-the-shelf components, that takes off, remains airborne, and lands safely using only solar energy. In particular, we perform a comprehensive analysis and design space exploration in the contemporary solar harvesting context and provide a detailed accounting of the prototype's mechanical and electrical capabilities. We also derive the Greedy Energy-Aware Control (GEAC) and Predictive Energy-Aware Control (PEAC) solar control algorithm that overcomes power system brownouts and total-loss-of-thrust events, enabling the prototype to perform maneuvers without a battery. Next, we evaluate the developed prototype in a bench-top setting using artificial light to demonstrate the feasibility of batteryless flight, followed by testing in an outdoor setting using natural light. Finally, we analyze the potential for scaling up the evaluation of batteryless UAVs across multiple locations and report our findings.
Related Concept Videos
 03:12
Batteries and Fuel Cells
 01:24
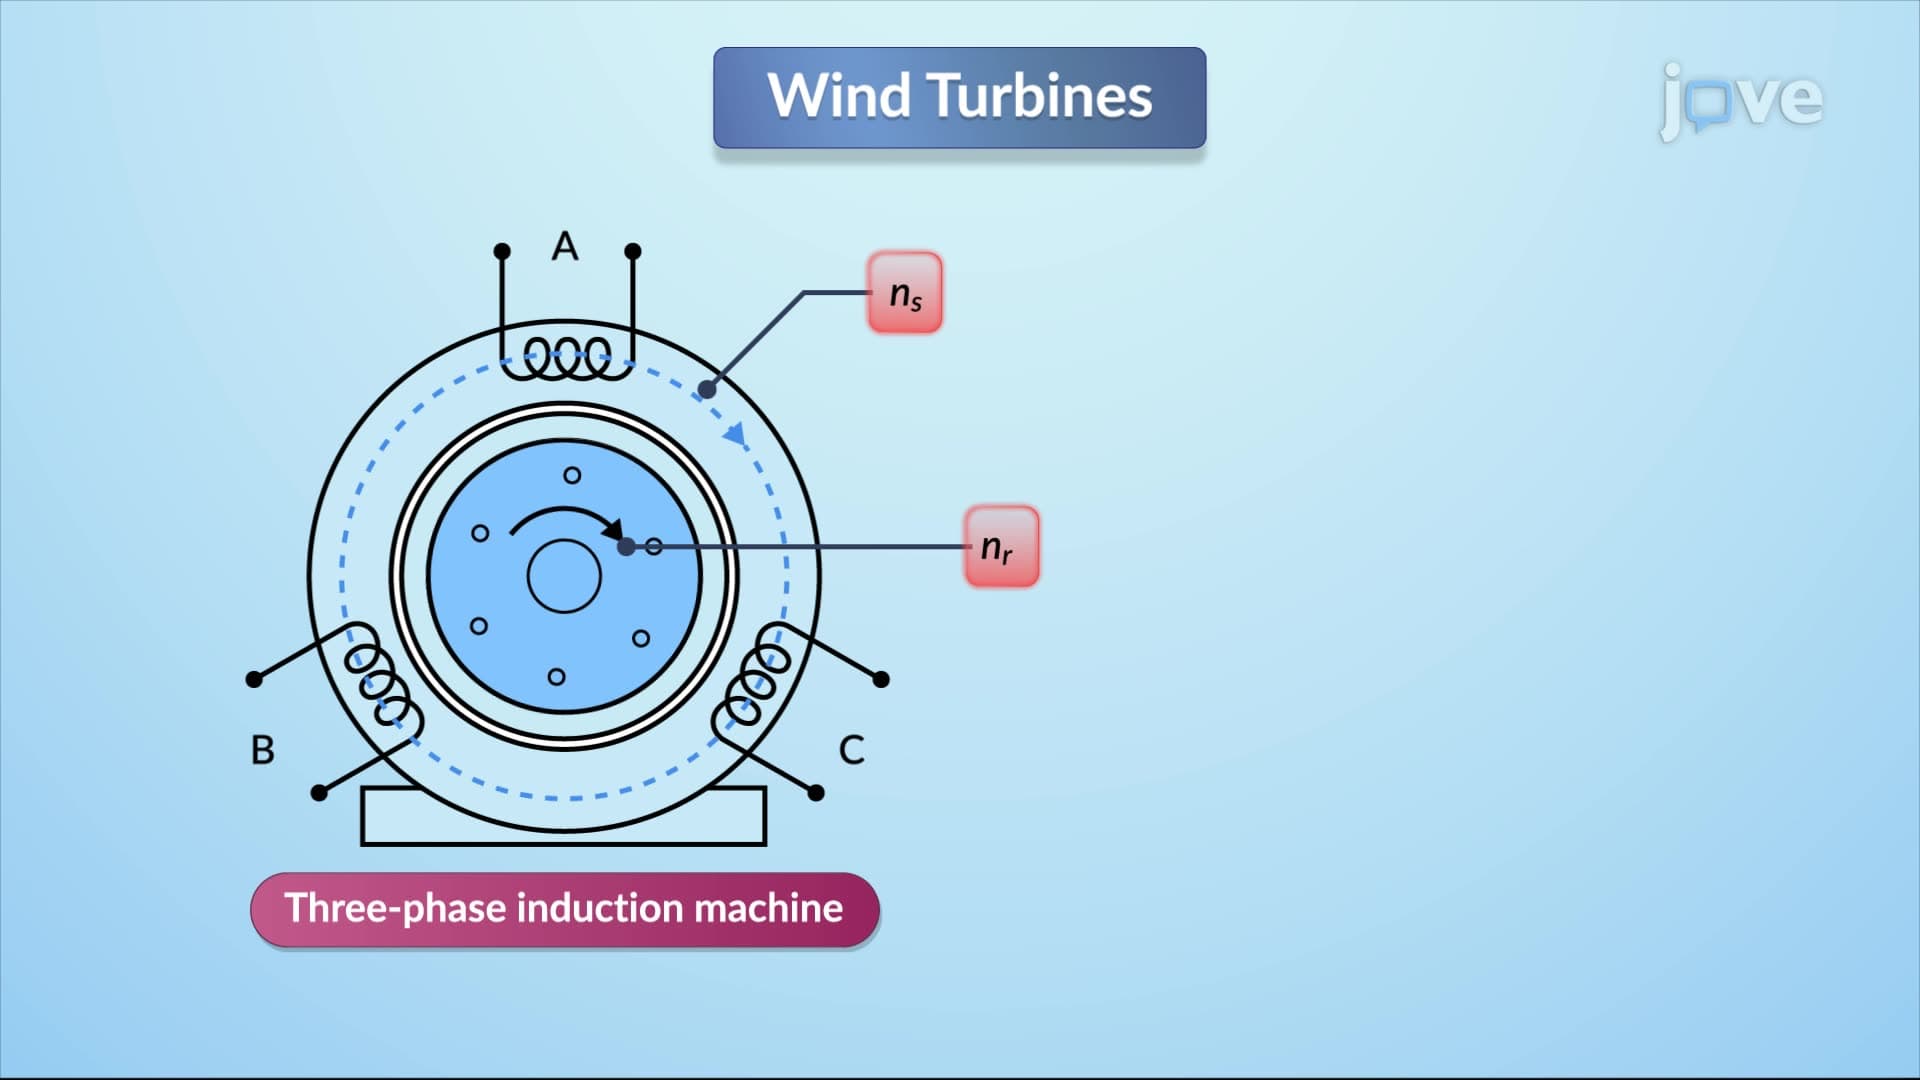
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:24
PI Controller: Design
 01:21
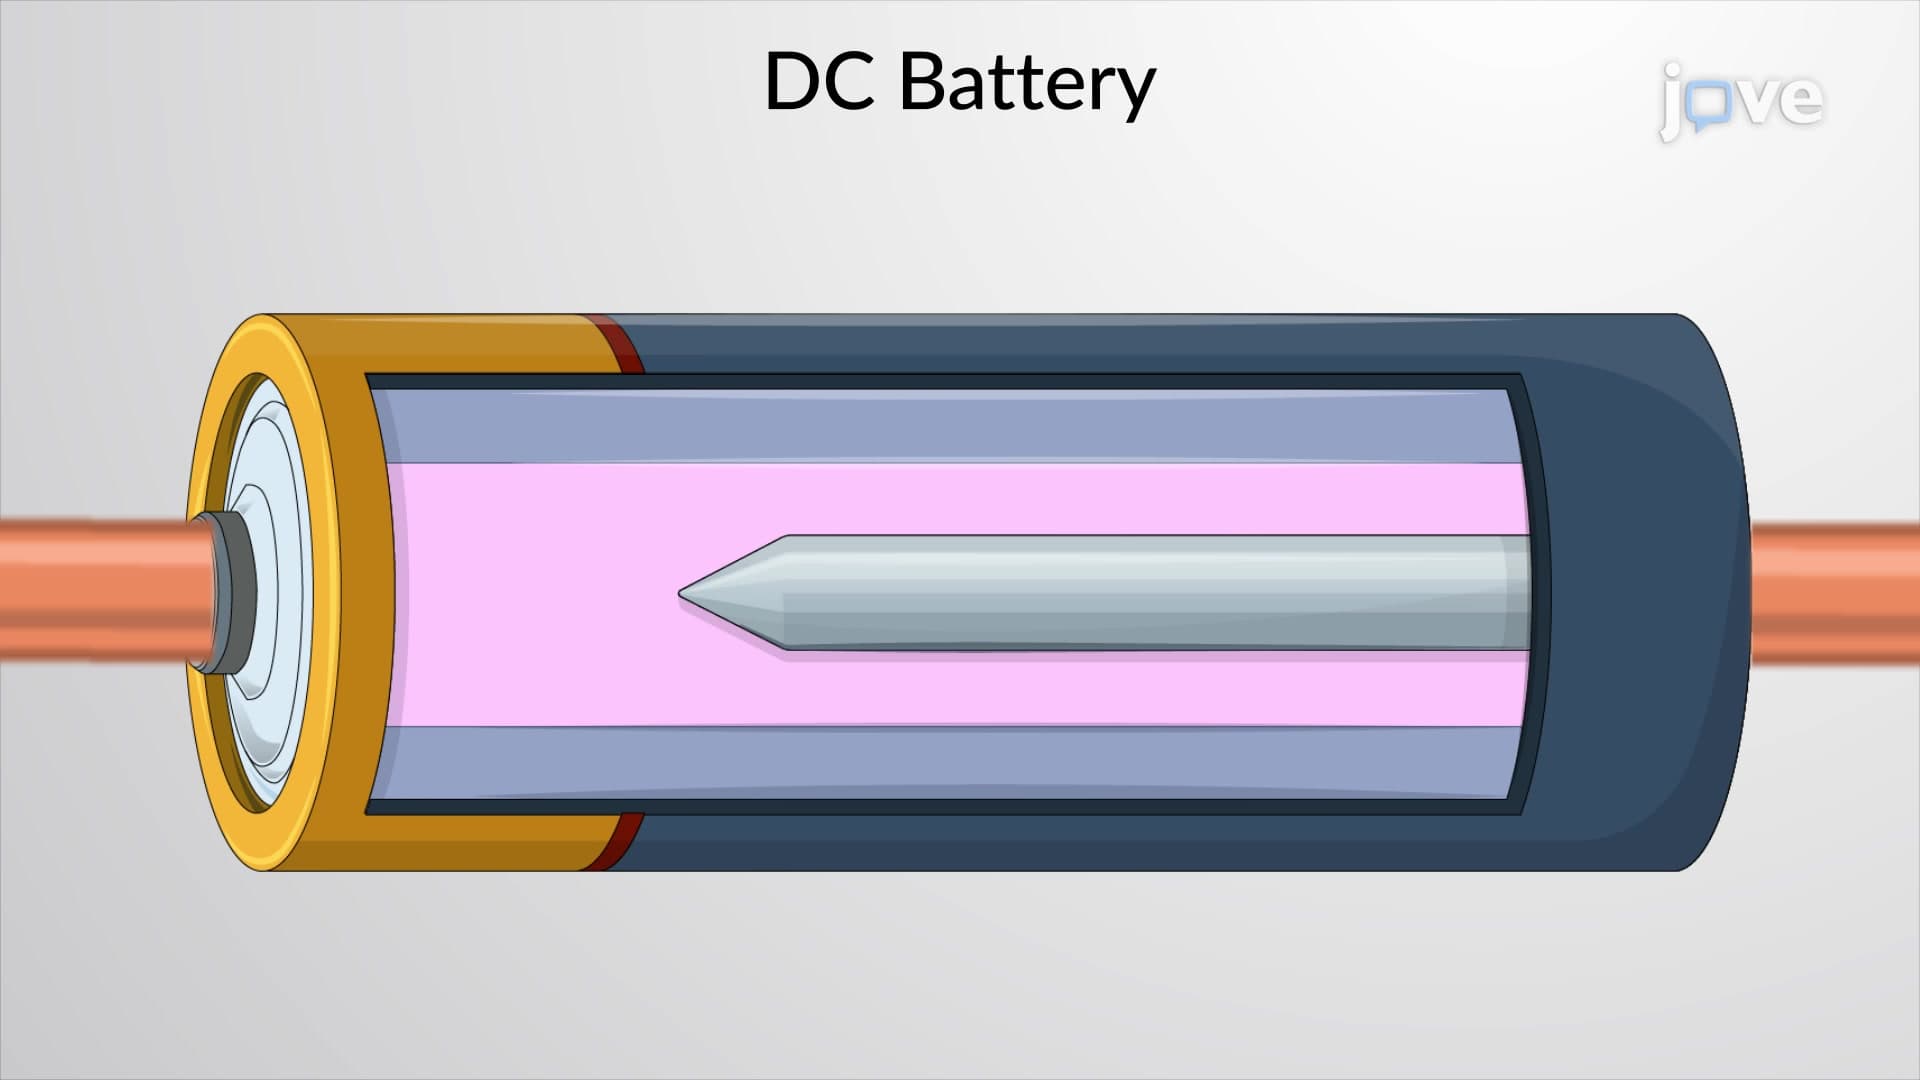
DC Battery